Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | ENGINEAI T800 Pro |
|---|---|
| Model profile | 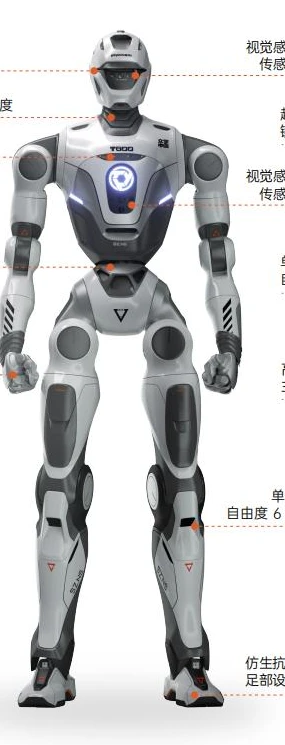 Explore T800 Pro ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | Unknown |
| Runtime | Unknown |
| SDK/API | Public native SDK, ROS2 community workspace and RL Lab provide C++/Python interfaces, MuJoCo and pinned Isaac Lab workflows. Native framework retains a precompiled scheduling core. BSD-3-Clause root licences do not establish that all firmware, motor drivers or AI weights are open. Exact targets: pm01_edu, t800 and t800pro; Basic retail T800 is excluded. Simulators must be isolated from physical robot discovery. |
| Programming | Native C++ plugins and ROS2 body/joint interfaces; edition entitlement required; ROS2 Humble / Cyclone DDS with Ubuntu 22.04 in public community workspace; historical ROS Noetic controller is a separate stack |
| Compliance | CE marking: Unknown |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | Mainland China: remote and return repair, Overseas: remote and warranty parts shipment per V2.0 policy |
| Last verified | Nov 2, 2026 |
| Factory fit | Edition-specific T800 evaluation: 29 body motors plus two seven-DOF hands = 43. October manual gives neck 2 and about 85.3 kg; retail Pro neck 3 and family 75–85 kg differ. |