Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | Kepler Exploration Robot K2 Bipedal Development |
|---|---|
| Model profile | 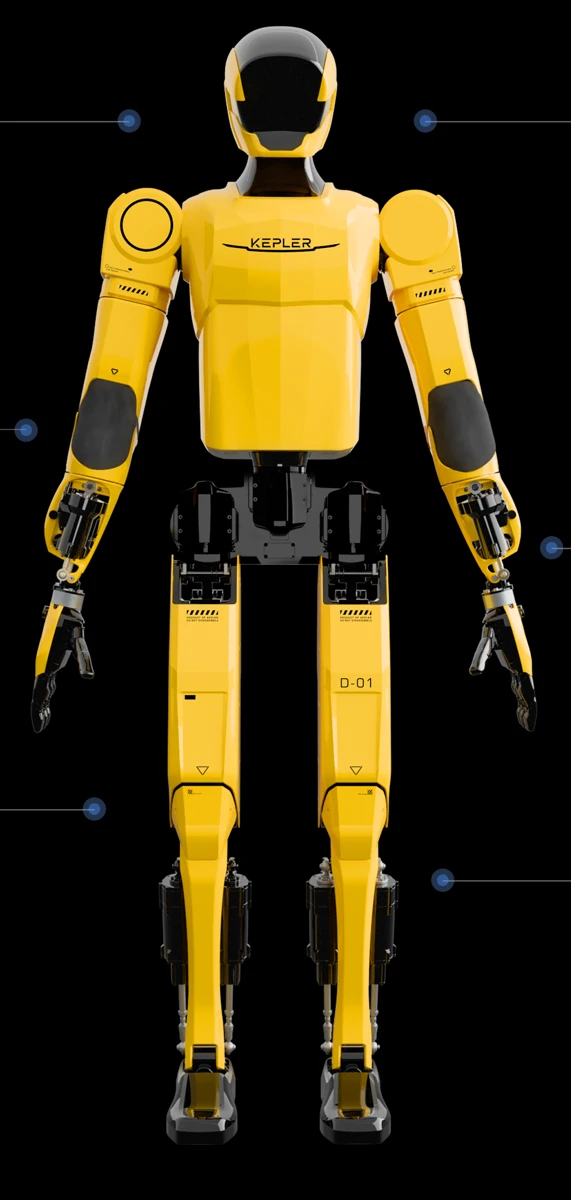 Explore K2 Bipedal Development ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | Unknown |
| Runtime | Unknown |
| SDK/API | K2 developer access is configuration-specific; Basic matrix omits secondary development. Public examples reference an SSH GitLab source repository; anonymous availability and full-stack redistribution licence not verified. |
| Programming | K2 MotorApi plus ROS2 perception, planning and application examples; Public tabletop example uses ROS2 Humble on Ubuntu 22.04; motor core API uses ROS2 JointState/Eigen. |
| Compliance | Needs verification |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China: manufacturer remote support, Europe: RBTX/igus inquiry, United Kingdom: EnduX K2/K2-W sales offer |
| Last verified | Nov 2, 2026 |
| Factory fit | K2 Bipedal Development adds dexterous hands, two force sensors and development access; 52 DOF includes passive hand articulation. |