Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | Leju Robotics KUAVO 4Pro Advanced |
|---|---|
| Model profile | 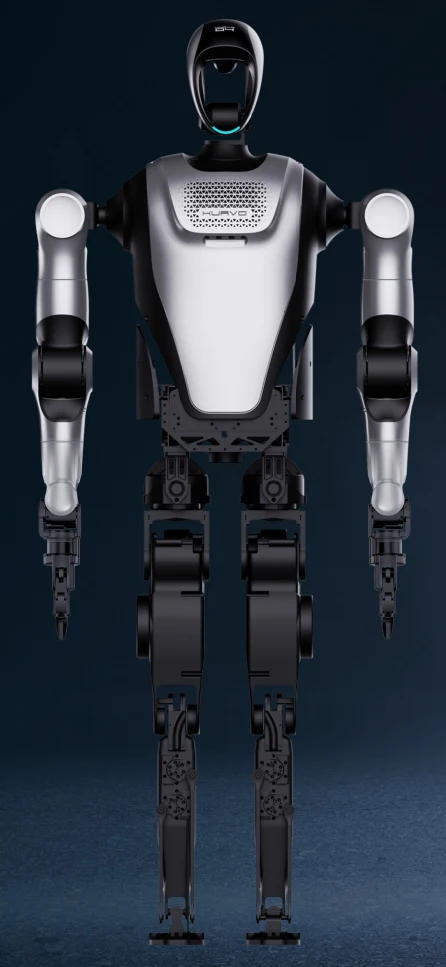 Explore KUAVO 4Pro Advanced ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | 5.00 kg |
| Runtime | 60 min |
| SDK/API | Match the manual configuration and ROBOT_VERSION to ROS controller and Python package. Edition does not imply interchangeable firmware. |
| Programming | ROS controller topics/services and Kuavo Python SDK; ROS1 package explicitly documented; this Python package excludes ROS2. Confirm delivered controller branch. |
| Compliance | CE marking: Unknown |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China, Europe through distributor-stated services, subject to contract |
| Last verified | Nov 2, 2026 |
| Factory fit | KUAVO 4Pro Advanced is a documented 4Pro configuration. Seven-joint arms and one-DOF two-finger gripper on each arm; Orin NX. The manual separates 28 body joints from end-effector joints; its one-hour walking endurance is distinct from the family two-hour marketing claim. |