Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | MagicLab MagicBot Gen1 |
|---|---|
| Model profile | 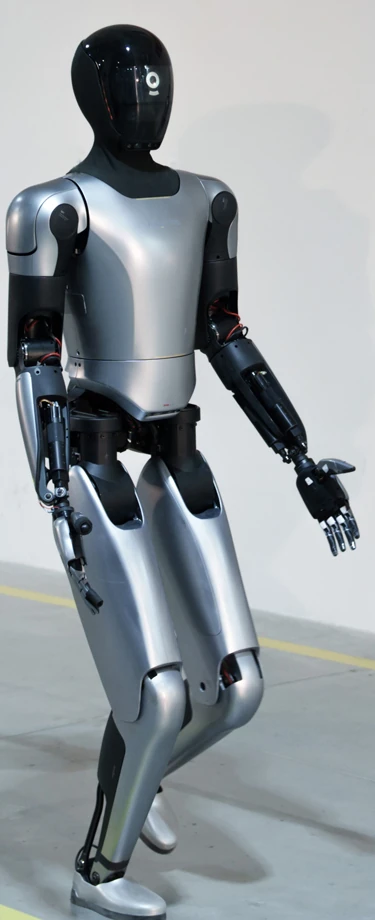 Explore MagicBot Gen1 ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | 5.00 kg |
| Runtime | Unknown |
| SDK/API | Public native C++20/Python3.10 BSD-3-Clause SDK with motion, sensor and service APIs. Ubuntu22.04 suggested; firmware/SDK tags and wired control must match. Official URDF/MJCF model describes30 body joints, excluding hand joints. Public visibility does not license all robot firmware or cloud services. |
| Programming | Native C++20 and Python3.10 joint, high-level motion, sensors, voice and SLAM APIs; Native SDK; internal ROS2 references do not prove supported external ROS2 control package |
| Compliance | CE marking: Unknown ISO 10218 review required: Requires buyer review |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China and international manufacturer inquiry, European seller support claimed; exact model/country contract scope unverified |
| Last verified | Nov 2, 2026 |
| Factory fit | Editorial: public rated versus maximum load, joint breakdown, developer manual and native control code support supervised manipulation/control evaluation. Museum guiding is a named company application. No accepted Gen1 production cycle, unattended uptime, independent repeatability test or validated unguarded collaboration established. |