Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | Noetix Robotics E1 EDU |
|---|---|
| Model profile | 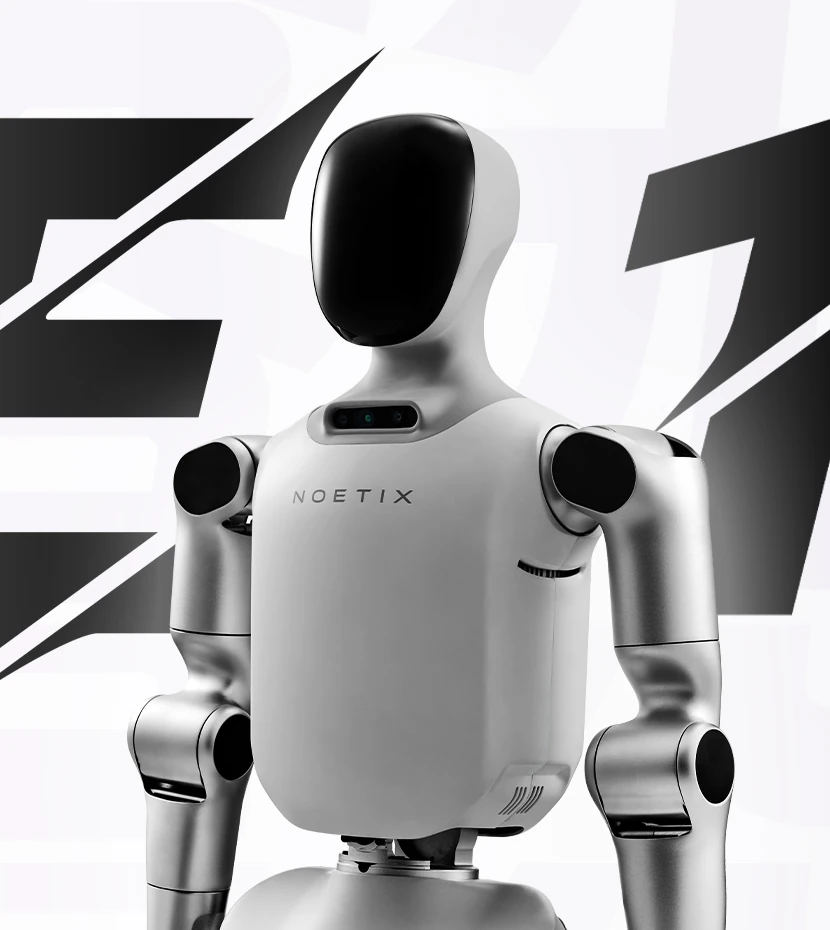 Explore E1 EDU ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | Unknown |
| Runtime | Unknown |
| SDK/API | EDU supports firmware-matched native C++/Python high/low-level DDS control; documented developer compute required. SDK does not require ROS. Delivery guide warns SSH to running motion unit may interrupt EtherCAT and cause immediate collapse; disable/support before service. No safety-controller certification inferred. |
| Programming | Native CycloneDDS C++/Python high-level control and entitled low-level control; Native Linux SDK does not require ROS; no blanket supported ROS2 control driver assumed |
| Compliance | CE marking: Unknown |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | Published domestic policy: mainland China with exclusions, Europe seller support advertised; separate written contract required |
| Last verified | Nov 2, 2026 |
| Factory fit | Editorial: developer configuration for supervised native control and RL research. Walking-load rating is separate from arm payload. E1 current body/battery differs from legacy brochure. No independently accepted manufacturing cycle, unguarded collaboration or continuous factory uptime verified. |