Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | RobotEra L7 |
|---|---|
| Model profile | 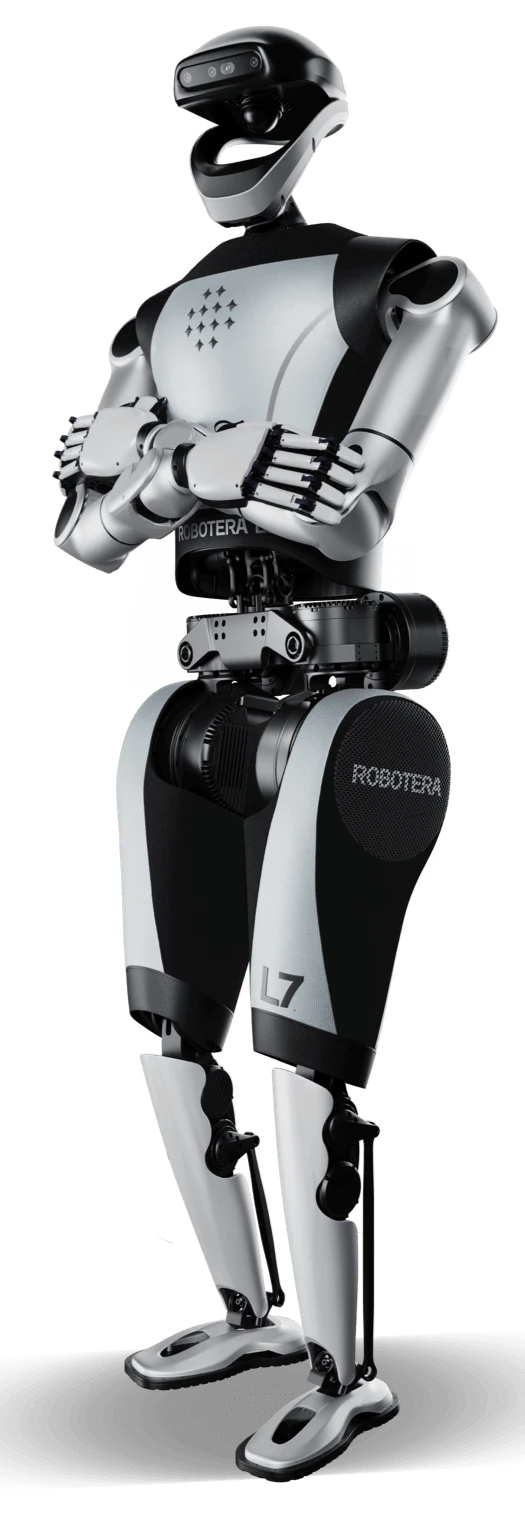 Explore L7 ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | 20.00 kg |
| Runtime | Unknown |
| SDK/API | Python joint/trajectory/ MPC / ServoPose and hand APIs in manufacturer developer environment. SDK explicitly ROS2 Humble/ CycloneDDS; exact host/firmware and teleop message versions must match. Official L7 Humanoid-Lab: Isaac Sim 5.1/ Isaac Lab 2.3.2, MuJoCo sim-to-sim and ROS2 real deployment. 29-DOF policy controls subset, not 55 full physical joints. Public repository rights are separate from firmware, model weights, commercial software and data. Match exact hardware, messages and supported firmware; not an independent safety controller. |
| Programming | Python joint/trajectory/ MPC / ServoPose and hand APIs in manufacturer developer environment; SDK explicitly ROS2 Humble/ CycloneDDS; exact host/firmware and teleop message versions must match |
| Compliance | CE marking: Unknown ISO 10218 review required: Requires buyer review |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China manufacturer support and public developer repositories, European seller service claimed; country/model contract scope unverified |
| Last verified | Nov 2, 2026 |
| Factory fit | Editorial: a full-size research platform with 31 body joints, configured XHAND1 hands, documented combined 20 kg bent-arm load and public ROS2 / Isaac Lab tools. Relevant to supervised manipulation/control pilots; CES demos and generic logistics claims do not establish an accepted L7 production line or safe unguarded collaboration. |