Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | UBTECH Robotics Walker S2 |
|---|---|
| Model profile | 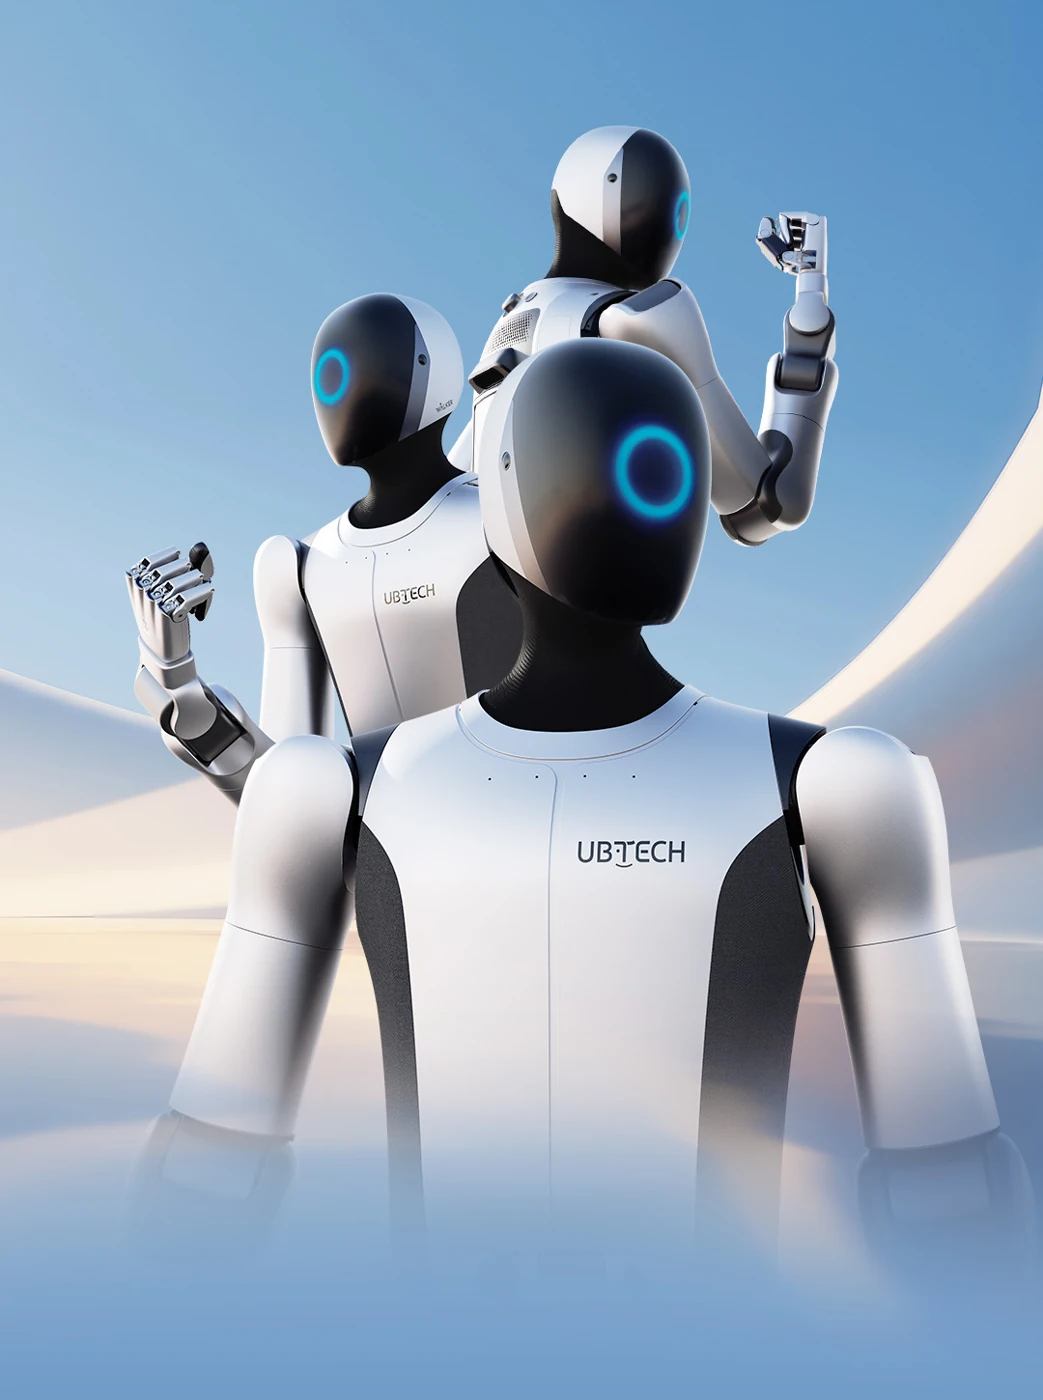 Explore Walker S2 ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | 15.00 kg |
| Runtime | 150 min |
| SDK/API | The model-specific public SDK documents ROS2 with Ubuntu 22.04 and ROSA 2.0. Legacy C/C++/Python/Matlab claims are not evidence of bindings for this version. |
| Programming | ROSA 2.0 SDK with ROS2 motor/sensor interfaces; Official Walker S2 SDK specifies ROS2 and ROSA 2.0; Ubuntu 22.04 recommended. Mac/Windows development currently unsupported. |
| Compliance | CE marking: Unknown ISO 10218-1:2025 / ISO 10218-2:2025: Unknown Machinery Directive 2006/42/EC: Unknown Machinery Regulation (EU) 2023/1230: Unknown |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China, Germany, Austria and Switzerland through Terra agreement; confirm model coverage |
| Last verified | Nov 1, 2026 |
| Factory fit | Walker S2 combines bipedal handling and autonomous battery swaps. ROSSMANN confirms one robot in a yearlong German logistics pilot; Airbus described early concept testing. Neither establishes general production uptime. |