Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | UBTECH Robotics Walker TienKung (TK2101) |
|---|---|
| Model profile | 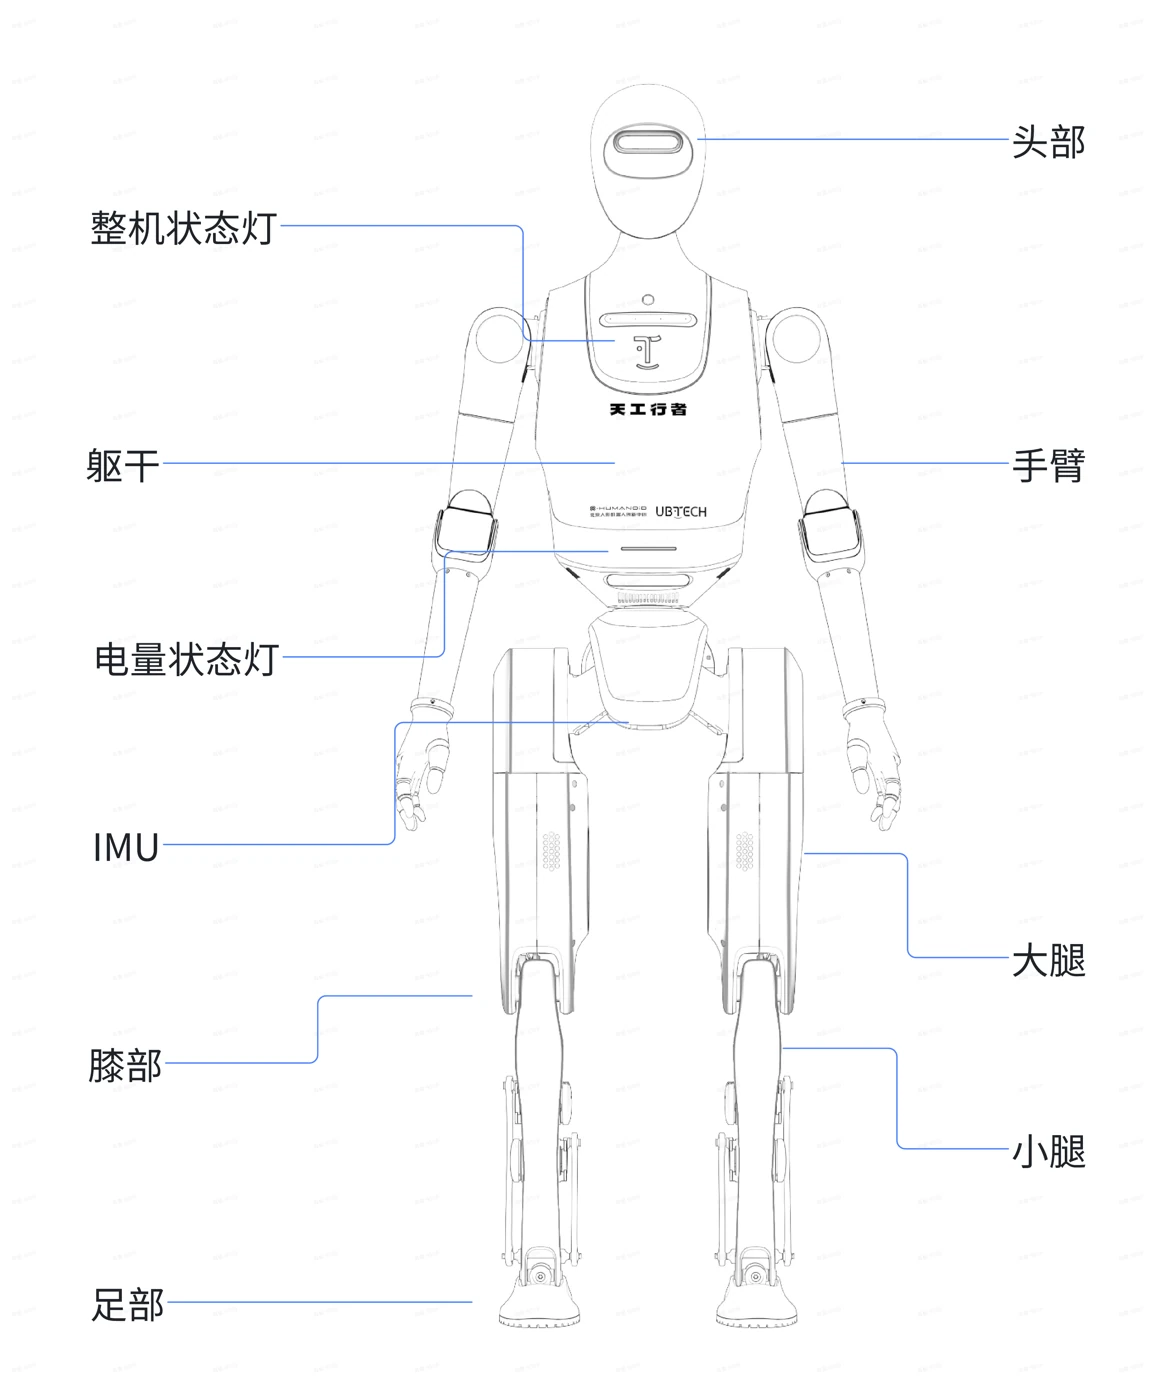 Explore Walker TienKung (TK2101) ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | Unknown |
| Runtime | Unknown |
| SDK/API | ROS2 control interfaces and official C++ deployment/Python training repositories exist. Current guide explicitly limits released gait-training support to Lite/base; Plus/Pro remains marked planned Q1 2026. The elapsed date is not release evidence. |
| Programming | ROS2 SDK with official training/deployment forks; Ubuntu 22.04.4 LTS in hardware table; ROS2 supported. Verify exact SDK/controller revision. |
| Compliance | CE marking: Unknown |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China, Germany, Austria and Switzerland through Terra agreement; confirm model coverage |
| Last verified | Nov 1, 2026 |
| Factory fit | Walker TienKung (TK2101) is a full-size research configuration. The current manual separates its joints, sensors and compute from the other TienKung editions. Research-use conditions and currently released gait-training support limit assumptions about factory deployment. |