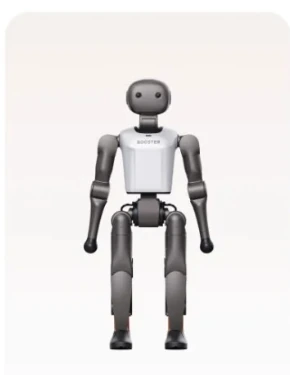
Industrial Applications
Editorial: Regionally announced 48 TOPS developer model. Exact equivalence to the current Geek edition is unresolved; do not infer its pack, board or endurance from the ordinary comparison. No independently accepted manufacturing process, continuous production uptime or safe unsupervised collaboration established.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Launch reports describe 22-axis K1 body with four-axis arms. No rated handling payload or hand specification verified for the delivered regional order.
September launch poster: 48 TOPS dense, binocular depth camera, nine-axis IMU, three-microphone array and speaker; Wi-Fi 6, Bluetooth 5.2 and gigabit Ethernet. Doubao bundled with six months free use at launch; ongoing fees, data terms and offline scope unverified. Exact processor and current SKU mapping unknown.
SDK and Integration
Native C++/legacy Python SDK uses Fast DDS and Apache 2.0; robot-description assets BSD 3-Clause. Booster Train/Deploy use Apache 2.0 with third-party terms; ROS 2 message package root licence not established. New boosteros Python package declares Proprietary. Firmware, agents, weights and cloud data rights are separate. Python SDK requires Python >=3.10 / firmware >=1.7 and executes on robots or Booster Studio; Deploy requires firmware >=1.7.2 and ROS 2 booster_interface. Pin the exact robot, task, SDK and firmware; public code is not a turnkey safety driver.
| API type | Native DDS C++/Python; BoosterOS application API; configuration-specific access |
|---|---|
| Languages | C++, Python |
| ROS support | ROS 2 message/service package; Deploy requires booster_interface; exact distro/BOM must match firmware |
| Simulation | URDF/MJCF; Isaac Gym legacy; Train tested Isaac Lab 2.3.2 / Isaac Sim 5.1.0; Deploy MuJoCo |
| Offline operation | Local control/examples documented; complete agents, speech, activation and cloud-free operation unverified |
| Teleoperation | Needs verification |
| Software updates | Vendor firmware/App updates; physically support body before torque-off upgrade |
| Documentation | Open documentation |
| Integration constraints | Native C++/legacy Python SDK uses Fast DDS and Apache 2.0; robot-description assets BSD 3-Clause. Booster Train/Deploy use Apache 2.0 with third-party terms; ROS 2 message package root licence not established. New boosteros Python package declares Proprietary. Firmware, agents, weights and cloud data rights are separate. Python SDK requires Python >=3.10 / firmware >=1.7 and executes on robots or Booster Studio; Deploy requires firmware >=1.7.2 and ROS 2 booster_interface. Pin the exact robot, task, SDK and firmware; public code is not a turnkey safety driver. Website policy permits China, Singapore and other server regions and defers to separate product policies. Operation data may be collected for fault detection/statistics. Complete robot/App/voice-agent data flows, retention, remote access, cloud training consent, patch lifetime and fully offline agent operation remain unverified. |
Safety Notes
Maker requires PREP and stable ground before WALK, clear motion area and no lifting a moving body. Upgrades stop control and remove joint torque: support the robot in DAMP. CUSTOM mode hands all joints to developer code; use a hoist and validate in simulation. Soft/hard stops, damping and alarms are manufacturer features, without inspected independent SIL/PL, fall envelope or unguarded collaborative approval.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No signed exact-configuration declaration, applicable test dossier or EU economic-operator details inspected. |
Commercial Readiness
| Pricing | September 18/21 reporting gives JD starting CNY 38,999. Dated regional reported offer, not a current November checkout or an international quote; scalar price unknown. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China manufacturer inquiry; overseas seller contract-dependent |
| Spare parts | German seller lists batteries/chargers and T2 LiDAR; French seller promises parts and repair. Exact joint/hand inventory, battery freight and response SLA unknown. |
| Warranty | September launch poster and September 21 reporting say Explorer three months, versus Education/Professional one year. Current regional contract and warranty start basis need confirmation. Warranty starts receipt under current manufacturer policy. Falls, water, unauthorised changes/parts, overload and developer-code collisions or vibration are excluded. Buyer prepays return; covered costs handled after diagnosis. Back up data before repair. Regional battery, hand, freight, labour and contract exceptions require written confirmation. |
| Configuration and pricing basis | Configuration and territory quote required |
| Distributors and service | Funduino in Nordhorn lists configurations on order; Bipedal lists T1-G currently unavailable; Robot Distribution in France advertises repair, parts and training. Sapienta in Italy quotes T2. These are seller claims, with no inspected manufacturer EU branch, authorised appointment, local inventory or service-response SLA. |
Specifications
| Height | 950 mm |
|---|---|
| Weight | 19.50 kg |
| Payload | Unknown |
| Runtime | 30 min |
| Battery and runtime conditions | September 18 launch comparison poster explicitly lists Explorer 2 Ah and 30 minutes walking at 0.4 m/s; voltage and battery inclusion in mass not stated. Dated regional configuration, not current Geek 20 minutes at 1.1 m/s. Exact Explorer-to-Geek mapping unresolved; no maximum speed inferred from the runtime test speed. |
| Degrees of freedom | 22 |
| Max speed | Unknown |
| Regional mapping | Explorer announced September 17; current matrix calls entry model Geek. Exact SKU/BOM equivalence unverified. Source ↗ |
| Dated regional runtime condition | 30 minutes with 2 Ah pack, walking at 0.4 m/s in September launch poster; not current Geek test condition. Source ↗ |

Sources and Further Reading
-
BoosterOS Python package metadata and proprietary licence ↗
Booster Robotics / Python Package Index · Accessed Nov 2, 2026
Inspected current PyPI 1.2.2 metadata declares license Proprietary. Separate legacy booster_robotics_sdk_python 1.6.3 metadata has no explicit licence field. Do not call all Booster software open source.
-
Current BoosterOS Python SDK runtime requirements ↗
Booster Robotics · Accessed Nov 2, 2026
Current supported list names K1/T1/T2 despite stale prose saying two models. Python >=3.10, firmware >=1.7; supported execution on physical robots or Booster Studio virtual environments, not arbitrary remote workstation guarantee. Sensors, mode/velocity/joint/trajectory/action/audio interfaces. API availability is not a licence for firmware, weights or all cloud services.
-
Current K1 edition comparison and product claims ↗
Booster Robotics · Accessed Nov 2, 2026
Current desktop comparison, not duplicated mobile panels: Geek / Education / Professional, approximately 950 mm and 19.5 kg, 22 body joints, 60 Nm peak, up to 2 m/s marketing. Geek 2 Ah / 20 minutes; Education and Professional 5 Ah / 70 minutes, walking at 1.1 m/s. Magnetic direct charging is optional in matrix. Three-month Geek versus one-year Education/Professional warranty. Current store link is an inquiry form; former USD 5,999 checkout not verified now.
-
Dated official product and ecosystem news index ↗
Booster Robotics · Accessed Nov 2, 2026
Official index dates T2 July 10, 2026, Booster Studio June 30 and K1 Explorer September 17. Explorer full WeChat article was inaccessible; exact Explorer-to-current-Geek mapping not established. August 22 T2 stage event involving 80 robots is a demonstration, not manufacturing acceptance.
-
K1 motion, upgrade and custom-control safety instructions ↗
Booster Robotics · Accessed Nov 2, 2026
PREP and stable ground before WALK; clear people/obstacles; no lifting a moving robot; do not touch moving parts except handle. Firmware upgrade stops controller and removes joint torque: support body and use DAMP. CUSTOM mode transfers all joints to developer code; hoist protection and simulation validation advised. Emergency stop/damping is not independently validated SIL/PL or collaborative-operation certification.
-
Official model-description DOF and simulation asset guide ↗
Booster Robotics · Accessed Nov 2, 2026
Manufacturer guide independently confirms K1 22, T1 23, T1_29dof seven-axis-arm URDF and T2 31 body axes. Head/arms/waist fixed in locomotion examples are controlled subsets, not new products. Internal b1_loco SDK naming does not establish a B1 retail robot.
-
Public booster_assets repository and licence scope ↗
Booster Robotics / GitHub · Accessed Nov 2, 2026
Actual root BSD 3-Clause licence. URDF/MJCF descriptions: K1 22, T1 23, T1 seven-axis arms 29 BODY, T2 31 BODY. Locomotion subsets/fixed joints are software assets, not new retail bodies. BSD model assets do not grant a website-picture licence.
-
Public booster_deploy repository and licence scope ↗
Booster Robotics / GitHub · Accessed Nov 2, 2026
Actual root Apache 2.0 notice. Python >=3.10, firmware >=1.7.2, ROS 2 booster_interface required for DDS-backed low_state/joint_ctrl/RPC; MuJoCo optional sim2sim. Not the same environment promise as generic native SDK.
-
Public booster_robotics_sdk repository and licence scope ↗
Booster Robotics / GitHub · Accessed Nov 2, 2026
Actual root licence states Apache 2.0. Native C++ and legacy Python bindings, Fast DDS; Ubuntu 22.04, GCC 11.4, aarch64/x86_64 examples. Public SDK licence does not cover all proprietary robot firmware or BoosterOS package.
-
Public booster_robotics_sdk_ros2 repository and licence scope ↗
Booster Robotics / GitHub · Accessed Nov 2, 2026
README inspected: ROS 2 message/service definitions including low-level state, command and agent RPC. Root LICENSE and guessed root package.xml returned 404; exact package licence/distro and whole-driver support not established. Public availability alone is not an open-source licence.
-
Public booster_train repository and licence scope ↗
Booster Robotics / GitHub · Accessed Nov 2, 2026
Actual root Apache 2.0 notice; embedded whole_body_tracking separately MIT. Isaac Lab motion tracking for T2/T1/K1; tested Isaac Lab 2.3.2 / Isaac Sim 5.1.0. Pin exact commit/assets/task rather than assuming all firmware or hand variants interchangeable.
-
Receipt-based warranty, exclusions and website privacy ↗
Booster Robotics · Accessed Nov 2, 2026
Warranty starts receipt; model-specific periods prevail. Excludes falls, water, unauthorised parts/repair, rough terrain, overload and developer code causing falls/collisions/joint-limit vibration. Buyer prepays return; covered fault costs reimbursed after diagnosis. Back up data; repairs may erase it. Robot operation data collected for fault detection/statistics. Website privacy is website-only; separate product policies prevail, servers China/Singapore/other regions. No complete robot/App/voice-cloud residency or offline guarantee established.
-
Explorer regional three-month warranty reporting ↗
Sina Finance · Published Sep 21, 2026 · Accessed Nov 2, 2026
Opened September 21 report: Explorer CNY 38,999 and three-month warranty; Education/Professional one year. Regional Explorer name is not assumed identical to current Geek edition. Not a November checkout quote.
-
Dated K1 Explorer launch price and hardware report ↗
IT Home · Published Sep 18, 2026 · Accessed Nov 2, 2026
September 18 report: K1 Explorer approximately 950 mm / 19.5 kg / 22 DOF, 48 TOPS dense, binocular camera, microphone/speaker, Doubao, development APIs and OTA. JD starting CNY 38,999 is a dated reported offer, not current checkout or ordinary Geek mapping. Exact battery/runtime/board identity not established. Original launch comparison image also opened and visually read: Explorer 2 Ah / 30 minutes walking at 0.4 m/s, 60 Nm peak, 48 TOPS dense, nine-axis IMU, three microphones, Wi-Fi 6, Bluetooth 5.2 and three-month warranty. Doubao six months free at launch; ongoing fees unknown. Different test condition from current ordinary matrix, not a resolved Geek equivalence.
-
Original regional Explorer launch configuration comparison ↗
Booster launch material reproduced by IT Home · Published Sep 18, 2026 · Accessed Nov 2, 2026
Exact poster opened and visually read, not OCR/snippet inference. Central Explorer 950 mm / 19.5 kg / 22 axes, 2 Ah / 30 minutes at 0.4 m/s, 48 TOPS dense and three-month warranty. Education/Pro columns show older 80-minute claims at 0.4 m/s; current ordinary matrix 70 minutes at 1.1 m/s has different conditions. Central model illustration used with explicit crop/provenance. Regional naming equivalence remains unresolved.