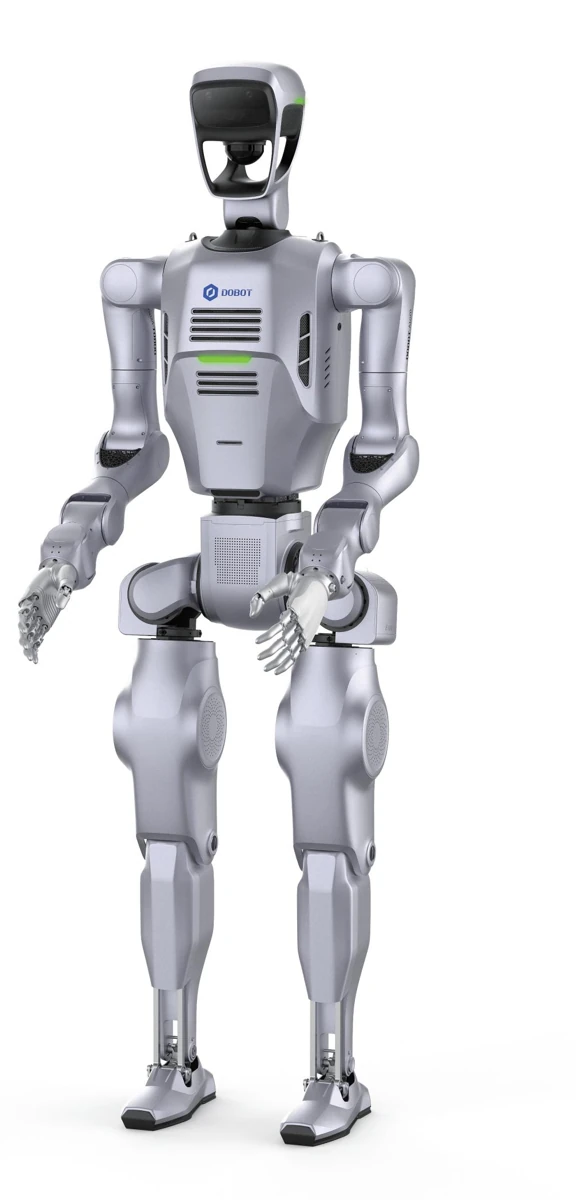
Industrial Applications
Editorial: a documented manipulation/development platform for supervised research and guarded assembly pilots. Rated arm load and public controls improve technical assessment; mass, charging configuration and exact safety/production-duty evidence still require resolution.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Two 7 DOF arms, 600 mm reach EX end effector, 3.5 kg RATED payload per arm, 5 kg maximum brochure value with unspecified full-reach duty.±0.05 mm is arm repeatability, not mobile task accuracy.29 body joints + two 6 DOF hands=41; brochure prose 12 DOF hands is combined.1.5 m/s endpoint and walking limit are separate claims.
Maker brochure: i5 base, i9(24 core/32 thread)+16 GB 256-bitGDDR 6 GPU option/module; 41.15 TFLOPS FP32 and 1500 TOPS marketing number use different precision/definitions. D455 depth +60 FPS FHD stereo, Robosense Airy 3 DLiDAR, 2 wrist+2 waistRGBD, 360° mic/two 5 W speakers. Delivered BOM and software options govern.
SDK and Integration
Native C++ RPC/CycloneDDS and public ROS2/Gazebo workspace now located; not simply an unspecified future SDK. Optional Embodied AI Set advertises URDF/training/data tools. Exact Max firmware/controller mapping and licences remain unverified.
| API type | C++ RPC and CycloneDDS joint/state interfaces; edition/firmware entitlement required |
|---|---|
| Languages | C++ native examples; Python ROS2 control examples |
| ROS support | Public ROS2 Foxy/Ubuntu 20.04 and Humble/22.04 workspace; exact sales-SKU mapping unverified |
| Simulation | Gazebo/ros 2_control, URDF, RViz; P2 legged and W-P3 wheeled examples; delivered-model fidelity unverified |
| Offline operation | Local Ethernet RPC/DDS documented; full autonomy, model licence and update egress require verification |
| Teleoperation | VR/MR full-body or segmented motion capture and data toolchain advertised as configuration-dependent options. |
| Software updates | Public source revisions; robot firmware signing, rollback and maintenance term unverified |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Public SDK includes libraries and samples. Root licence not recovered; public access is not unrestricted reuse permission. Internal P2/P3 and 22 DOF simulation labels do not identify every retail configuration. |
Native build Ubuntu 20.04/GCC 9.4; high-level FSM/velocity, low-level debug-state joint/hand/IMU/BMS data and recording. Examples can move hardware. No blanket licence or ATOM-to-LUMO compatibility asserted.
Safety Notes
September 4, 2025 ATOM quick-start requires protective hoisting for startup, debugging and shutdown. Remote LB+A soft stop enters damping and can let the robot fall; hard wireless stop cuts joint/control power and requires restart. This describes operating behaviour, not a certified safety integrity level. Independent fall zone, load stability, stop latency and application safeguards require assessment.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No exact model/configuration declaration or test dossier inspected. Generic standards and cobot certificates do not verify this humanoid. |
| ISO 10218 review required | Unknown | International | No exact model/configuration declaration or test dossier inspected. Generic standards and cobot certificates do not verify this humanoid. |
Commercial Readiness
| Pricing | No current manufacturer fixed price for this exact configuration verified; obtain dated itemised quote including tax, transport, software and commissioning. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China / international supplier inquiry; exact SKU by contract |
| Spare parts | No exact EU stock or repair SLA verified; request battery, drive, hand, sensor/controller spares and supported lifetime. |
| Warranty | One year in September manual and December Max brochure; exact battery/hand exclusions and transport/labour scope unverified. Max onsite training listed available; no universal EU service SLA. |
| Configuration and pricing basis | Dated configuration quote required |
| Distributors and service | German office is a commercial contact; exact humanoid dealer appointment and repair scope unverified. |
Public dealer stock labels and demonstration locations are not delivery guarantees.
Specifications
| Height | 1650 mm |
|---|---|
| Weight | Unknown |
| Payload | 3.50 kg |
| Runtime | 120 min |
| Battery and runtime conditions | December 2025 maker brochure: quick-replace 15 Ah pack, about 2 h runtime, about 1 h charge. September quick-start says about 2 h charging; charging hardware/version unresolved. DC 67.2 V manual charger voltage is not nominal battery voltage. No standardised loaded endurance, hot-swap continuity or duty cycle established. |
| Degrees of freedom | 41 |
| Max speed | 1.50 m/s |
| AI compute | Advertised 1500 TOPS; brochure also lists 41.15 TFLOPS FP32 GPU +i9. Precision and hardware options must match quote. Source ↗ |
| Height and mass conflict | ~1650 mm; September manual~62 kg and December brochure~58 kg, both EX hands/grippers. Exact assembled mass unknown. Source ↗ |
| Rated arm load | 3.5 kg per arm EX tools; brochure 5 kg maximum lacks full-reach duty conditions.±0.05 mm is arm repeatability. Source ↗ |
| Teleoperation | VR/MR markerless full-body or segmented modes; optional data toolchain and Embodied AI Set. Source ↗ |
Sources and Further Reading
-
ATOM Max and D official product descriptions ↗
DOBOT Robotics · Accessed Nov 2, 2026
Official Max and D descriptions. Max’s 41 joints include the hands; D has 16 body joints. ROM-1’s 24 Hz inference, NDS’s 200 Hz control and 28 upper-body joints describe different subsystems. The claimed 42% energy reduction has no complete comparison protocol and is not a runtime measurement.
-
ATOM public URDF repository ↗
Dobot-Arm GitHub account · Accessed Nov 2, 2026
Public model README displays atom-w-p3, atom-w-p2 and p3 identifiers. Model availability does not establish Max, D, Trainer or LUMO compatibility, a supplied motion controller, or unrestricted reuse rights.
-
Public ATOM native SDK repository ↗
Dobot-Arm GitHub account · Accessed Nov 2, 2026
Public C++ SDK describes Ubuntu 20.04, GCC 9.4, high-level RPC state and velocity commands, low-level CycloneDDS joint control, IMU and battery data, recording and wheeled-base interfaces. Examples can move the robot. Root licence not recovered; public availability does not establish unrestricted redistribution or compatibility with every ATOM edition.
-
ATOM ROS2 models, controllers and Gazebo examples ↗
Dobot-Arm GitHub account · Published Jul 3, 2026 · Accessed Nov 2, 2026
README updated July 3, 2026. Documents Foxy on Ubuntu 20.04, Humble on 22.04, CycloneDDS, ros2_control, Gazebo, RViz and C++/Python examples. The W-P3 simulator uses 22 body controls; a P2 legged model is separate. Internal model labels are not mapped to every sales edition. Root licence and delivered-controller equivalence remain unverified.
-
ATOM Max and ATOM-W at Robot Technology Japan ↗
DOBOT Robotics · Published Jun 22, 2026 · Accessed Nov 2, 2026
Maker report of the June 11–13 exhibition, posted June 22. It identifies Max with 41 joints and ATOM-W with 28 upper-body joints. The W brochure instead gives 20 joints excluding hands and 32 upper-limb joints. Exact revision mapping remains unclear; an exhibition date is not the initial release date.
-
ATOM Max and D manufacturer brochure D20251215 ↗
DOBOT Robotics; hosted by Funduino · Published Dec 15, 2025 · Accessed Nov 2, 2026
Manufacturer-authored brochure hosted by Funduino. Max is approximately 1,650 mm and 58 kg excluding tools; D is approximately 650 mm and 26 kg excluding tools. Both list 3.5 kg rated arm payload and 5 kg maximum. Max has 29 body plus 12 hand joints. Mass and charging figures differ from the September guide; obtain the exact bill of materials.
-
ATOM Quick Start V1.1 original instructions ↗
SHENZHEN DOBOT CORP LTD; hosted by Autodiscovery · Published Sep 4, 2025 · Accessed Nov 2, 2026
Manufacturer’s September guide hosted by Autodiscovery. The specification table distinguishes Max, Trainer and D; Standard is only named in the scope. It requires hoisting during startup, debugging and shutdown. The soft stop enters damping and can allow a fall; the hard stop removes power. Charging voltage is not nominal pack voltage.
-
First ATOM batch delivery at Nagoya launch ↗
DOBOT Robotics · Published Jun 30, 2025 · Accessed Nov 2, 2026
Manufacturer reports the first ATOM batch delivered at the June 27, 2025 Nagoya launch with Japanese integrator ASKA. The article was posted June 30. It does not identify the exact Max, Trainer or II configuration, disclose the batch size, or establish independently audited fleet reliability.