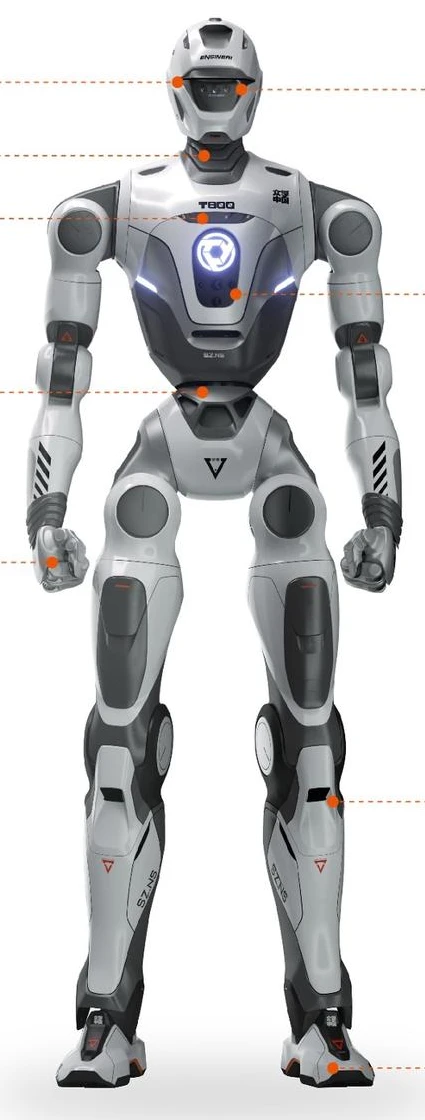
Industrial Applications
Edition-specific T800 evaluation: 25-body-motor, five-axis-arm developer tier, called Open Source/Eco in English launch and Developer in Chinese. Marketing/manual component differences remain unresolved.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Five-axis arms / 25 body DOF; no supported dexterous hands. Public October manual approximately 84.5 kg including battery, while retail gives unallocated 75–85 kg; scalar mass null pending exact BOM.
Exact retail and manual revisions differ: Basic NX 16 GB / no LiDAR; Developer English AGX + LiDAR versus Chinese Intel camera / no LiDAR and RK3588S base. October Developer/Pro manual instead Nezha four-core 8 GB + AGX 64 GB / 256 GB and Odin2 stereo + LiDAR / IMU, four microphones, two speakers. Freeze exact BOM.
SDK and Integration
Public native SDK, ROS2 community workspace and RL Lab provide C++/Python interfaces, MuJoCo and pinned Isaac Lab workflows. Native framework retains a precompiled scheduling core. BSD-3-Clause root licences do not establish that all firmware, motor drivers or AI weights are open. Exact targets: pm01_edu, t800 and t800pro; Basic retail T800 is excluded. Simulators must be isolated from physical robot discovery.
| API type | Native C++ plugins and ROS2 body/joint interfaces; edition entitlement required |
|---|---|
| Languages | C++, Python |
| ROS support | ROS2 Humble / Cyclone DDS with Ubuntu 22.04 in public community workspace; historical ROS Noetic controller is a separate stack |
| Simulation | MuJoCo joint-bridge / native Sim2Sim; Isaac Sim 5.1 and Isaac Lab 2.3.2 training in current RL repository |
| Offline operation | October 2026 privacy policy claims local robot data processing; all-feature offline execution and remote-service dependence require verification |
| Teleoperation | Needs verification |
| Software updates | Public support entry points exist; exact firmware compatibility, rollback and maintained lifetime unverified |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Use the exact hardware/controller/manual revision and contract. Family openness does not enable software-disabled retail editions. |
Safety Notes
Manufacturer warns of high-power drives and dangerous demonstrations. Establish a bounded test area, trained operator, suspension/support during development and validated stop/recovery procedures. No exact-model signed EU declaration, independent protective-stop performance or collaborative safety envelope inspected.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No exact-model signed EU Declaration of Conformity inspected. |
Commercial Readiness
| Pricing | Launch range starts CNY 180000, without verified current developer quotation. No exact-edition USD or export price assigned. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China supplier inquiry, Overseas availability subject to configuration and contract |
| Spare parts | Overseas policy provides replacement-parts delivery; customs exceptions and local repair arrangements apply. No verified European spares warehouse or contracted turnaround. |
| Warranty | V2.0 policy lists 12 months for main unit/electronics/charger/controller, excluding consumables and unauthorised modifications. Battery and purchased edition scope require contract confirmation. Historical January 2025 PM01 FAQ instead gave Business 8 months / Education 12; do not silently replace an existing contract. |
| Configuration and pricing basis | Exact edition quotation required |
| Distributors and service | No exact-model manufacturer authorisation or stocked European repair capability verified. |
Specifications
| Height | 1730 mm |
|---|---|
| Weight | Unknown |
| Payload | Unknown |
| Runtime | Unknown |
| Battery and runtime conditions | Product table says lithium / 3–5 h and hero says solid-state / 4 h. October developer manual specifies 61.2 V / 20 Ah / 1.22 kWh ternary lithium, ~7.2 kg, quick removal, separate 2.5 h charge. Overview 2 h standard versus battery chapter ≥3 h general walking unresolved; no universal runtime scalar or unverified optional 40 Ah pack. |
| Degrees of freedom | 25 |
| Max speed | Unknown |
| Edition mechanics | 25 motors: neck 2 + legs 12 + waist 1 + arms 10. Five-axis arms; development access, no dexterous-hand entitlement. Source ↗ |
| Walking versus hardware speed | Developer/Pro manual forward walking 0–1.5 m/s, running <3 m/s hardware-supported; retail ≥2 m/s hardware. No measured universal maximum assigned. Source ↗ |
Sources and Further Reading
-
Current PM01 and T800 reinforcement-learning source ↗
ENGINEAI · Accessed Nov 2, 2026
README and LICENSE.txt read: BSD-3-Clause, Isaac Sim 5.1 / Isaac Lab 2.3.2 pinned base; Python whole-body-tracking / AMP, MuJoCo Sim2Sim and native SDK deployment. Targets PM01 EDU and T800; not all retail editions automatically developer-enabled. Older linked engineai_rl_workspace returns 404.
-
ENGINEAI overseas and mainland service policy V2.0 ↗
ENGINEAI · Accessed Nov 2, 2026
Main unit/electronics/charger/controller listed 12 months, consumables excluded and actual product contract governs. Mainland 7×12 remote and return repair; overseas remote + warranty parts shipping, customs exceptions and locally assessed repair. Onsite/training USD 500 per person/day plus travel subject to resources. No named EU centre/SLA. Trial/demo authorisations excluded; confirm applicability to each sale.
-
EngineAI ROS2 community workspace ↗
ENGINEAI · Accessed Nov 2, 2026
Current community branch README and BSD-3-Clause licence read. Ubuntu 22.04, ROS2 Humble / Cyclone DDS, C++11+ and Python3.10+, body velocity and joint interfaces, MuJoCo joint-bridge simulation. Warns isolate simulator from physical network; compatibility and exact firmware must be confirmed.
-
Native SDK source, licence and exact targets ↗
ENGINEAI · Accessed Nov 2, 2026
Main README / BSD-3-Clause licence / recursive tree opened. C++ plugin framework wraps precompiled scheduling core; Docker, x86_64 and aarch64, MuJoCo. Exact targets pm01_edu, t800, t800pro. Root licence does not make all controller/firmware source available. Stop existing motion service and suspend initially per manual; no robot commands executed.
-
T800 Chinese retail edition table ↗
ENGINEAI · Accessed Nov 2, 2026
Chinese current table lists Basic, Developer and Max, whereas English retains four including Pro. Developer corresponds to five-arm-DOF / 25-body development tier, but sensor and base-board BOM differs from October developer manual. Chinese RK3588S / no Developer LiDAR versus English eight-core / LiDAR and manual Nezha / Odin2 must be confirmed by serial configuration.
-
T800 English four-edition specifications ↗
ENGINEAI · Accessed Nov 2, 2026
Basic 25 DOF / NX / no developer access; Open Source 25 / AGX / developer access; Pro 29+14=43; Max 32+14=46. All 1730 mm, unspecified edition weights 75–85 kg. Pro neck listed 3 conflicts with 29-body arithmetic and manual neck 2. 5 kg refers to HAND, not arm payload. Hardware speed ≥2 m/s, lithium 3–5 h table conflicts with solid-state hero and developer manual.
-
ENGINEAI October 2026 privacy policy ↗
ENGINEAI · Published Oct 29, 2026 · Accessed Nov 2, 2026
October 29 update. Intro legal name includes 市; contact section omits 市, joint-stock form in both. Shenzhen Bay Innovation Technology Center T1 floor 69. Robot imagery/voice/location/decision data currently processed locally, not proactively uploaded per policy; account/contact/log data separate, China-collected personal data stored in China with affiliate sharing provisions. Not independent packet or security audit.
-
T800 computers and network ↗
ENGINEAI · Published Oct 16, 2026 · Accessed Nov 2, 2026
Developer/Pro: Nezha four-core 8 GB / 64 GB plus AGX Orin 12-core 64 GB / 256 GB, Ubuntu and wired internal network. Public default SSH access is documented; credentials deliberately omitted from research content. Product-board differences remain explicit.
-
T800 developer and Pro hardware identity ↗
ENGINEAI · Published Oct 16, 2026 · Accessed Nov 2, 2026
Public October 16 guide distinguishes five-DOF-arm 25-body Developer and seven-DOF-arm 29-body + 14-hand Pro, both developer-enabled. Labelled component images visually inspected. This Developer is not software-disabled retail Basic.
-
T800 developer electrical and mechanical specifications ↗
ENGINEAI · Published Oct 16, 2026 · Accessed Nov 2, 2026
Developer 84.5 kg / Pro 85.3 kg including battery, both 1730 mm; Pro neck 2. Forward walking 0–1.5 m/s; running hardware <3 m/s, not certified maximum 3. AGX 64 GB, standard ternary lithium 1.22 kWh / 2 h / 2.5 h charge, 450 Nm peak, 20° slope / 200 mm step. No external supply or in-body charging.
-
T800 sensor and calibration guide ↗
ENGINEAI · Published Oct 16, 2026 · Accessed Nov 2, 2026
Developer/Pro Odin2 stereo RGB + head LiDAR + IMU, four microphones and two speakers. Pro hand has five tactile arrays per hand. Module Class 1 laser and IP66 are component claims, not whole-robot certification; hand actuator IP40 also not whole-body rating. Manual warns robot URDF installation transform requires checking and future update.
-
T800 standard battery and handling ↗
ENGINEAI · Published Oct 16, 2026 · Accessed Nov 2, 2026
61.2 V nominal / 20 Ah / 1.22 kWh ternary lithium, about 7.2 kg, quick removal and separate 2.5 h charging only. Battery chapter ≥3 h general walking conflicts with overview 2 h standard and product 3–5 h. Charge limit 71.2 V vs overview charger 71.4 V: use exact approved charger/manual revision, not inferred nominal voltage.
-
T800 launch announcement and four commercial tiers ↗
ENGINEAI · Published Dec 8, 2025 · Accessed Nov 2, 2026
December 8 posting; primary chronology names December 2, 2025 launch. Starting CNY 180000, with Basic / Eco (Open Source) / Pro / Max. No current USD edition checkout prices established; prior USD 40500–80800 removed as unsupported. Production rhetoric is manufacturer positioning, not independently measured delivery.