Industrial Applications
KUAVO 4.1 is a 155 cm/50 kg documented generation, distinct from the filing’s 152 cm/51 kg KUAVO 4 and 166 cm/55 kg 4Pro. Its manual has 28-body versus 30 table DOF ambiguity; no single total assigned.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
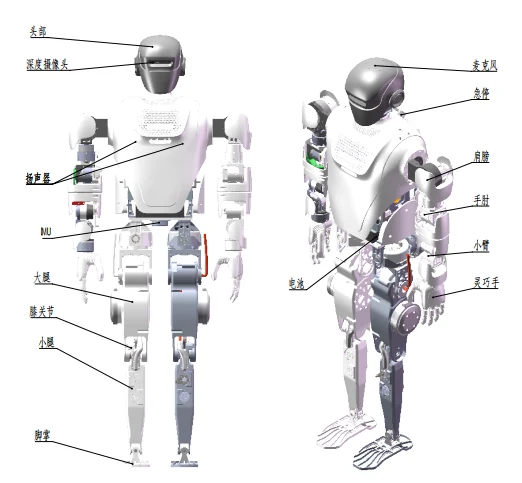
626 mm arms, 7 joints each; manual prose 28 body DOF conflicts with table 30 labelled excluding ends. Grippers 1 DOF or optional 6 DOF hands; payload unknown.
D435, six-mic array, IMU, joint temperature; i 9 controller plus upper IntelSWNUC or optionalAGXOrin.
SDK and Integration
Exact historical controller, SDK access and maintained simulation support not verified.
| API type | ROS controller topics/services and Kuavo Python SDK |
|---|---|
| Languages | C++ controller source, Python SDK |
| ROS support | ROS1 package explicitly documented; this Python package excludes ROS2. Confirm delivered controller branch. |
| Simulation | MuJoCo launch examples and Docker controller simulation; robot description and ROBOT_VERSION must match. |
| Offline operation | Local controller/simulation examples exist; optional cloud speech, VLA and model services need separate dependency review. |
| Teleoperation | VR/remote-controller and data-collection workflows documented in ecosystem; edition/hardware compatibility must be confirmed. |
| Software updates | Repository/package releases; version-match controller, SDK and calibration. Firmware support period unknown. |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Match exact robot version, mass calibration, end-effectors and controller package. Prebuilt hardware dependencies may remain. |
Safety Notes
No exact-model conformity dossier or certified collaborative operating envelope verified. Emergency-stop hardware and manufacturer demonstrations do not establish safe unrestricted shared work.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | Distributor promises a supplied DoC; exact-model declaration not inspected. |
Commercial Readiness
| Pricing | No current exact-edition price verified; request a configuration-specific quote. Historical family average selling prices are not a unit list price. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China; present quotation required, Europe: distributor-stated Leju range, exact edition subject to quote |
| Spare parts | Distributor claims European batteries/common spares; exact Leju model inventory and replenishment lead time not independently verified. |
| Warranty | No uniform manufacturer warranty duration, exclusions or cross-border repair cost established for these models. Obtain edition-specific written terms. |
| Configuration and pricing basis | Exact configuration quotation required |
| Distributors and service | Robot Distribution advertises Leju supply, European service and training; no per-edition authorisation or stock verification. |
No price, stock or lead time inferred from generic family offers.
Specifications
| Height | 1550 mm |
|---|---|
| Weight | 50.00 kg |
| Payload | Unknown |
| Runtime | 90 min |
| Battery and runtime conditions | 60 V/8 Ah, 1.5 h walking,≥500 cycles,≤1.5 h charging in exact manual. |
| Degrees of freedom | Unknown |
| Max speed | Unknown |
| Count ambiguity | 626 mm arms, 7 joints each; manual prose 28 body DOF conflicts with table 30 labelled excluding ends. Grippers 1 DOF or optional 6 DOF hands; payload unknown. Source ↗ |
| Walking battery | 60 V/8 Ah, 1.5 h walking,≥500 cycles,≤1.5 h charging in exact manual. Source ↗ |
Sources and Further Reading
-
KUAVO_4_1产品介绍 ↗
Leju Robotics · Accessed Nov 2, 2026
Official version-specific product chapter inspected, including mechanical, battery, sensor, compute, end-effector and emergency-stop tables. Upper-level prospectus and family marketing may use different counting, configuration or endurance conditions. Chapter diagrams are manufacturer illustrations.
-
Kuavo Humanoid Python SDK ↗
Leju Robotics · Accessed Nov 2, 2026
Manufacturer-maintained package documents Python ROS1 SDK; expressly excludes ROS2 in this package. State/motion, hands, head, torso and MuJoCo examples; branches and robot version must match. This package is not the current Roban 2.2 C++ DDS SDK.
-
KUAVO ROS open-source controller repository ↗
Leju Robotics · Accessed Nov 2, 2026
Manufacturer README inspected: hardware-specific ROBOT_VERSION, per-unit mass calibration, catkin and Docker simulation; model matching matters. MIT source repository includes external dependencies and prebuilt hardware components; no blanket hardware-source or firmware openness.
-
Leju current documentation centre ↗
Leju Robotics · Accessed Nov 2, 2026
Primary links to Kuavo, Roban, Aelos, VLA, LeMotion and LeTools/LejuLab. Tool availability does not establish every model licence or configured hardware.
-
Leju range, parts and service in Europe ↗
Robot Distribution · Published Oct 29, 2026 · Accessed Nov 2, 2026
Distributor states European sales/rental/RaaS, parts, repair, training and supplied DoC. Model listings say on order. These are distributor claims; exact manufacturer authorisation, physical stock, signed declarations and repair SLA not independently established.