Industrial Applications
Editorial: historical research configuration documented by original author paper. Distinct identity is preserved while current orderability, commercial software, arm load, battery, safety approval and production readiness remain unverified.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
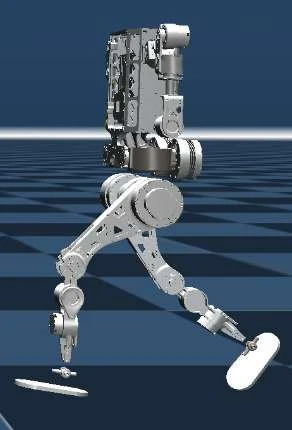
Author-labelled Dora simulation shows running, spinning and backward/sideways walking. No physical joint count, dimensions, mass, hand or arm payload transferred from N1 or secondary robot catalogues.
Exact installed compute, sensor and autonomy package unverified; no blanket autonomous task library inferred.
SDK and Integration
Paper describes imitation/RL locomotion transfer from IsaacGym to MuJoCo and real N1 hardware. Exact current API, firmware, code/weight rights and commercial entitlement unverified; current N2/E1 DDS compatibility not assumed.
| API type | Published locomotion research; current commercial API unverified |
|---|---|
| Languages | Needs verification |
| ROS support | Exact model-specific ROS control compatibility unverified |
| Simulation | Paper IsaacGym training/MuJoCo sim2sim; real N1 joystick control, Dora figure is simulation |
| Offline operation | Complete robot, App activation, voice/AI, telemetry and service offline scope unverified |
| Teleoperation | Exact delivered controller/App/voice and developer authority require confirmation |
| Software updates | Current-model OTA advertised; historical coverage, signing and patch lifetime unverified |
| Documentation | Open documentation |
| Integration constraints | Match exact model, firmware, developer entitlement and compute. Public SDK BSD-3-Clause rights are separate from firmware, weights, data and commercial services. Native motor control is not a certified safety function. |
Safety Notes
Manufacturer disclaimer requires adult operation and training, with restrictions near children, older/vulnerable people and crowds despite education/companion marketing. No independent stop/fall envelope or safety-integrity validation inspected. Motor disable can collapse the body; follow exact delivered instructions and protect the test area.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | Seller promises EU declaration; no actual exact-model/configuration signed declaration or complete safety dossier inspected. |
Commercial Readiness
| Pricing | Current exact-edition manufacturer price unverified; quote must identify body, compute, camera, software, tax, transport and commissioning. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | Historical research/development platform; current orderability unverified |
| Spare parts | Return-to-factory route in domestic policy; exact hand/joint/compute/battery coverage, local stock and turnaround outside China unverified. |
| Warranty | Exact historical body, battery, parts and software warranty/orderability unverified. Current Bumi/N2/E1 periods not transferred. |
| Configuration and pricing basis | Exact configuration quotation; European seller purchase/rental/RaaS advertised |
| Distributors and service | No exact current OEM-authorised regional stock or repair route verified for this historical platform. |
Orders, demonstrations, aggregate shipments and future targets are not an independently accepted exact-edition fleet.
Specifications
| Height | Unknown |
|---|---|
| Weight | Unknown |
| Payload | Unknown |
| Runtime | Unknown |
| Battery and runtime conditions | Exact configuration-specific battery, voltage, runtime and charge arrangement unverified; no values transferred from another body. |
| Degrees of freedom | Unknown |
| Max speed | Unknown |
Sources and Further Reading
-
Current Noetix legal identity and historical product timeline ↗
Noetix Robotics · Accessed Nov 2, 2026
Rendered current company history: Beijing 松延动力科技集团股份有限公司, founded September 2023; first N1 prototype October 2023, W0 August 2025, W1 October 2025. Head-only/half-body facial interaction products are distinguished from complete humanoid bodies. Timeline dates Pre-B to September 2025; detailed financing release instead says October 26. Exact closing-date conflict remains unresolved.
-
Domestic warranty and operating disclaimer ↗
Noetix Robotics · Accessed Nov 2, 2026
Actual disclaimer and after-sales tabs read. Mainland-China-only coverage with stated exclusions: Bumi 12 months, N2/E1 three months, from FIRST ACTIVATION; contract overrides. Claimed 7×12 h service excluding statutory holidays, initial response within 30 minutes, repair within seven working days after receipt excluding transit/special cases. Falls/water/unauthorised work/wrong packaging excluded. Replacement part retains remaining warranty or minimum three months. Outbound transit risk buyer, return risk vendor. Adult-only disclaimer and restrictions near vulnerable/crowded people differ from companion marketing.
-
Independent historical model inventory: N2 and Dora ↗
Fraunhofer Institute for Material Flow and Logistics IML · Accessed Nov 2, 2026
Original Fraunhofer IML report downloaded/read; appendix lists separate Noetix N2 and Dora with historical maker links. Old hosts now fail DNS. Inventory supports model identity, not current stock/specification or production installation. Unretrieved old brochure snippets were not copied as verified values.
-
European Noetix catalogue and attributed support promises ↗
Robot Distribution · Published Oct 22, 2026 · Accessed Nov 2, 2026
French seller catalogue updated October 22: Bumi/N2/E1/W1 and head products, on order/price on request; purchase/rental/RaaS, EU declaration, parts/repair/training promised. Exact OEM appointment, signed declaration, physical inventory and response SLA unverified. Seller E1 3.5 m/s is not independent validation of current 1400 mm body.
-
Original N1 hardware and Dora simulation research ↗
Huaxing Huang, Wenhao Cui, Tonghe Zhang and coauthors / arXiv · Published Feb 26, 2025 · Accessed Nov 2, 2026
Original author paper read: Figure 2 N1 hardware 950 mm/23 kg/18 DOF, arms eight and legs ten. Real N1 locomotion uses joystick velocity commands; not autonomous industrial task acceptance. Figure 8 explicitly shows Dora MuJoCo simulation, not a physical product photo. Article CC BY 4.0 link opened; reused images credited with figure, rotation/crop and licence.