Industrial Applications
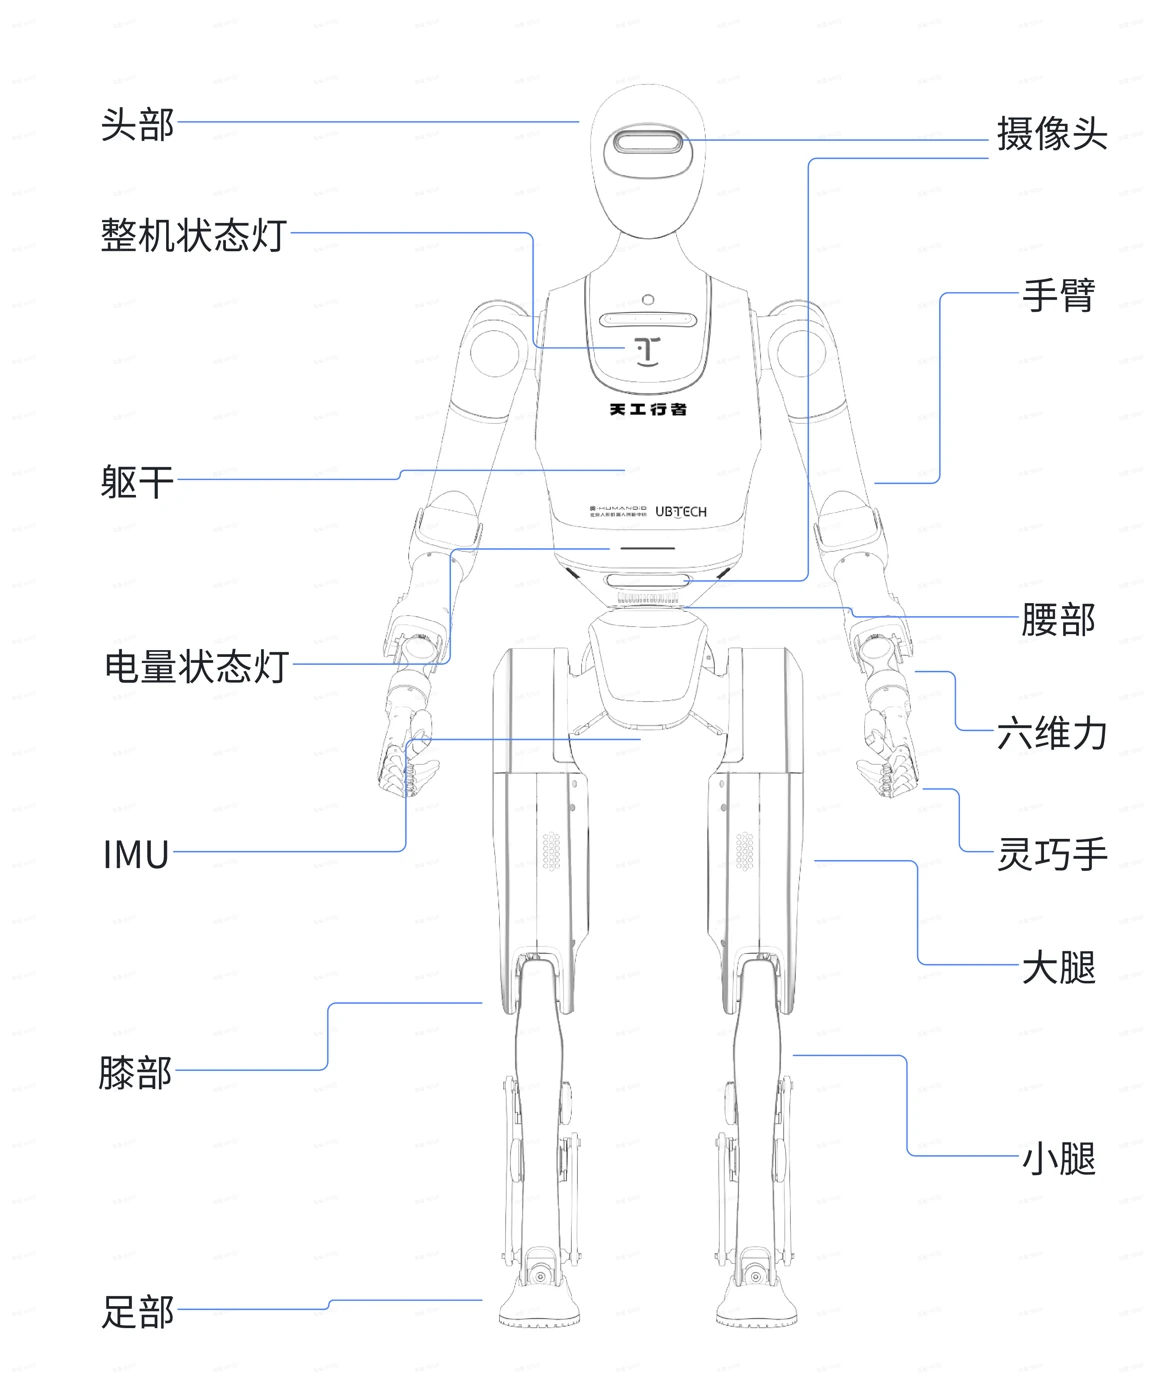
Walker TienKung Pro (TK2301) is a full-size research configuration. The current manual separates its joints, sensors and compute from the other TienKung editions. Research-use conditions and currently released gait-training support limit assumptions about factory deployment.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
No exact-configuration rated payload verified. Seven joints per arm, six per leg, six per hand, three head and one waist; six-axis force sensing.
All versions: IMU and Intel i7-1355U, 16 GB RAM/256 GB storage. Three RGB-D cameras and voice kit; two Orin AGX 64 GB module(s), each advertised 275 TOPS. Precision and workload matter.
SDK and Integration
ROS2 control interfaces and official C++ deployment/Python training repositories exist. Current guide explicitly limits released gait-training support to Lite/base; Plus/Pro remains marked planned Q1 2026. The elapsed date is not release evidence.
| API type | ROS2 SDK with official training/deployment forks |
|---|---|
| Languages | C++ control library, Python training |
| ROS support | Ubuntu 22.04.4 LTS in hardware table; ROS2 supported. Verify exact SDK/controller revision. |
| Simulation | Isaac Lab 2.1/Isaac Sim 4.5 training and MuJoCo sim-to-sim. Current gait guide supports Lite/base; Plus/Pro compatibility remains an unreleased plan in the inspected guide. |
| Offline operation | Exact local/cloud task boundaries not established. |
| Teleoperation | No exact-model public teleoperation package verified. |
| Software updates | Firmware availability and support period not established. |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Initial research use; commercial application requires compliant secondary development and manufacturer registration. Review research-data sharing/custody terms and the proprietary-data exception. |
Safety Notes
Research biped: learned gait transitions, loss of support and emergency states need a supported test area. Manufacturer acceptable-use terms and authorised firmware/repair conditions apply. No exact-model collaborative safety certification verified.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No exact-model EU Declaration of Conformity or certificate verified. |
Commercial Readiness
| Pricing | Marketing positions the family below CNY 300,000, but exact edition, tax, accessories and contract price were not established; numerical price remains unknown. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China; international fulfilment requires quotation |
| Spare parts | Battery, actuator and end-effector revision compatibility, stock and repair turnaround require confirmation. |
| Warranty | Current manual: one year from receipt for main unit, joints, battery/power accessories and shell. Unauthorised changes/firmware/repairs excluded; manufacturer restricts third-party repairs. |
| Configuration and pricing basis | Quotation required; no exact-configuration public price verified. |
| Distributors and service | Terra has an announced DACH distribution agreement; confirm that this model and configuration are included. |
Family under-CNY-300,000 marketing is not a verified quotation for this exact edition. Research-use and registration terms apply.
Specifications
| Height | 1730 mm |
|---|---|
| Weight | 75.00 kg |
| Payload | Unknown |
| Runtime | Unknown |
| Battery and runtime conditions | Current manual: 48 V 30 Ah main plus 3 Ah auxiliary battery; ternary lithium; charging under four hours, endurance more than 3.5 hours with unspecified task mix. Eight-hour marketing statement is thermal behaviour, not battery endurance. |
| Degrees of freedom | 42 |
| Max speed | Unknown |
| Configuration | TK2301: 75 kg, 42 DOF; nominal height 1730±10 mm. Marketing rounds the family to 170 cm. Source ↗ |
| Running claim | Family marketing advertises 10 km/h running; not verified as the maximum walking speed of each configuration. Source ↗ |
| Endurance lower bound | More than 3.5 hours in manual, workload unspecified; no exact runtime scalar retained. Source ↗ |
Sources and Further Reading
-
UBTECH-Robot/Deploy_Tienkung ↗
UBTECH Robotics / GitHub · Accessed Nov 1, 2026
Official manufacturer fork; ROS2 reinforcement-learning deployment and C++ control library. Check hardware support in current manufacturer guide.
-
UBTECH-Robot/TienKung-Lab ↗
UBTECH Robotics / GitHub · Accessed Nov 1, 2026
Official manufacturer fork of Open-X-Humanoid training project; Python, Isaac Lab and MuJoCo. Repository availability is not a guarantee of support for every hardware revision.
-
UBTECH Walker TienKung / 天工行者 official product page ↗
UBTECH Robotics · Accessed Nov 1, 2026
Marketing page: 170 cm/20 DOF baseline, 10 km/h running and 30+3 Ah. Eight-hour statement concerns thermal behaviour, not verified battery endurance. Current manual separates three configurations.
-
Walker TienKung acceptable-use agreement — V2.0.7.x ↗
UBTECH Robotics · Accessed Nov 1, 2026
Initial research-only use, commercial application through compliant secondary development and registration with manufacturer. Research data custody/sharing conditions and proprietary-data exception require project-specific review.
-
Walker TienKung after-sales warranty — V2.0.7.x ↗
UBTECH Robotics · Accessed Nov 1, 2026
Latest page downloaded and inspected: one-year cover from receipt for main unit, joints, battery/accessories and shell; unauthorised modifications excluded. Repair may involve logs and data loss; manufacturer says no third-party repair authorisation.
-
Walker TienKung gait training and deployment ↗
UBTECH Robotics · Accessed Nov 1, 2026
Current guide links Isaac Lab training, MuJoCo sim-to-sim and ROS2 deployment. It explicitly supports Lite/base; Plus/Pro support remains a planned Q1 2026 item, not verified released functionality.
-
Walker TienKung hardware table — V2.0.7.x ↗
UBTECH Robotics · Accessed Nov 1, 2026
Latest manual fetched directly after web-tool timeout; compared with V2.0.5.x. TK2101/TK2201/TK2301: 64/68/75 kg and 20/21/42 DOF. All nominal 1730±10 mm, 48 V 30+3 Ah, more than 3.5 hours; no exact walking-speed or payload rating.
-
UBTECH 2026 interim report ↗
UBTECH Robotics · Published Sep 24, 2026 · Accessed Nov 1, 2026
HKEX filing: legal identity, public company financing and new products. Pages 35–36 report net placing proceeds; pages 7 and 15 distinguish group revenue and product development. Revenue is not robot shipment count.