Industrial Applications
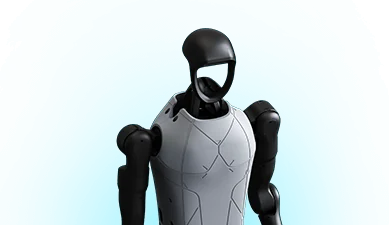
Editorial assessment: Full-size biped with seven-joint arms, approximately 7 kg rated arm load and public ROS 2 examples. It differs materially from H1 in mass, joints and walking speed. Evaluate guarded manipulation tasks against an exact hand and firmware configuration.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Seven-joint arms; optional dexterous hands. Rated arm load about 7 kg, peak about 21 kg; not a sustained two-arm payload.
3D LiDAR and depth camera.
SDK and Integration
Development access varies by edition. Public Unitree repositories do not grant development rights to base retail models.
| API type | SDK and open-source examples |
|---|---|
| Languages | C++, Python |
| ROS support | Official ROS 2 repository includes model examples; match firmware and joint configuration. |
| Simulation | MuJoCo via unitree_mujoco, Gazebo via unitree_ros, Reinforcement learning via unitree_rl_gym |
| Offline operation | Local DDS control examples exist; complete offline application behavior unverified. |
| Teleoperation | SDK-based developer workflows; exact supported hardware and access need confirmation. |
| Software updates | Manufacturer OTA updates; signing and rollback details not reviewed. |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Suitable only for serious engineering teams or integrators. Requires guarded pilot cell, robot-task risk assessment, safety-rated external controls and factory network isolation. |
Safety Notes
Supplier notes the humanoid industry is still in an early exploration stage and asks users to comply with local laws and avoid hazardous use. Use only in controlled environments until validated.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No public product-specific CE certificate was verified on the official product page. Request declaration of conformity and complete safety documentation for H1-2. |
| ISO 10218 | Requires buyer review | International | Full-size robot with meaningful payload and high joint torque. Factory deployment should be treated as industrial robot integration requiring risk assessment, safeguarding and validated stop behavior. |
| ISO/TS 15066 | Requires buyer review | International | Only applicable for collaborative applications. High payload/torque makes unguarded shared-workspace use especially sensitive. |
Video Evidence
Commercial Readiness
| Pricing | No verified firm H1-2 price; request a configuration-specific quote. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | Global direct/distributor availability reported |
| Spare parts | Confirm actuator, battery, depth camera, LiDAR, hand and compute replacement lead times before pilot deployment. |
| Warranty | No H1-2-specific duration verified; request written terms. |
| Configuration and pricing basis | Contact sales / configuration-dependent. Public H1-2 price not captured on product page. |
| Distributors and service | Local integrator and repair coverage not verified in this model review. |
Research snapshot: 1 November 2026. Confirm configuration, destination, taxes, transport and acceptance terms in a binding quotation.
Specifications
| Height | 1780 mm |
|---|---|
| Weight | 70.00 kg |
| Payload | 7.00 kg |
| Runtime | Unknown |
| Battery and runtime conditions | 15 Ah / 864 Wh; maximum voltage 67.2 V. Runtime not established. |
| Degrees of freedom | 27 |
| Max speed | Unknown |
| Locomotion | Full-size bipedal humanoid Source ↗ |
| Standard compute | Intel Core i5 for platform function and Intel Core i7 for user development; optional Intel Core i7 or Orin NX up to 3 devices Source ↗ |
| Model-specific interpretation | Manufacturer says <2 m/s, not exactly 2 m/s. Source ↗ |
| Arm normal load | Rated about 7 kg; peak about 21 kg Source ↗ |
| Maximum leg joint torque | 360 N·m Source ↗ |
| Maximum arm joint torque | 120 N·m Source ↗ |
| Sensor configuration | 3D LiDAR + depth camera Source ↗ |
Sources and Further Reading
-
About Unitree — corporate history ↗
Unitree Robotics · Accessed Nov 1, 2026
Manufacturer history: 2016 founding; G1, R1 and H2 announcement dates; demonstrations and internal manufacturing test claims. These are not independent deployment tests.
-
Unitree after-sales terms ↗
Unitree Robotics · Accessed Nov 1, 2026
Warranty starts on receipt; exclusions include falls, overloading, unauthorized changes and damage from developer programs. Return freight and service charges depend on diagnosis.
-
Unitree H1 / H1-2 product page ↗
Unitree Robotics · Accessed Nov 1, 2026
Official supplier product page. H1 and H1-2 differ materially in weight, DOF, arms and payload.
-
Unitree MuJoCo official simulator ↗
Unitree Robotics · Accessed Nov 1, 2026
C++ and Python low-level simulation with SDK2/DDS; configuration names include H1, G1 and H2. Check exact joint layout before sim-to-real use.
-
Unitree official open source page ↗
Unitree Robotics · Accessed Nov 1, 2026
Official page listing Unitree simulation, ROS, SDK, reinforcement learning, imitation learning and teleoperation repositories.
-
Unitree ROS 2 official repository ↗
Unitree Robotics · Accessed Nov 1, 2026
README lists G1 and H1-2 low-level examples and H1 communication; Ubuntu 20.04/Foxy and 22.04/Humble. Does not establish support for every newer model.