Industrial Applications
Editorial assessment: Compact learning and demonstration biped offered as AIR, standard and EDU. AIR reduces joints and sensors; EDU is the documented development edition. For engineering purchase, choose by API access and configuration as well as headline price.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
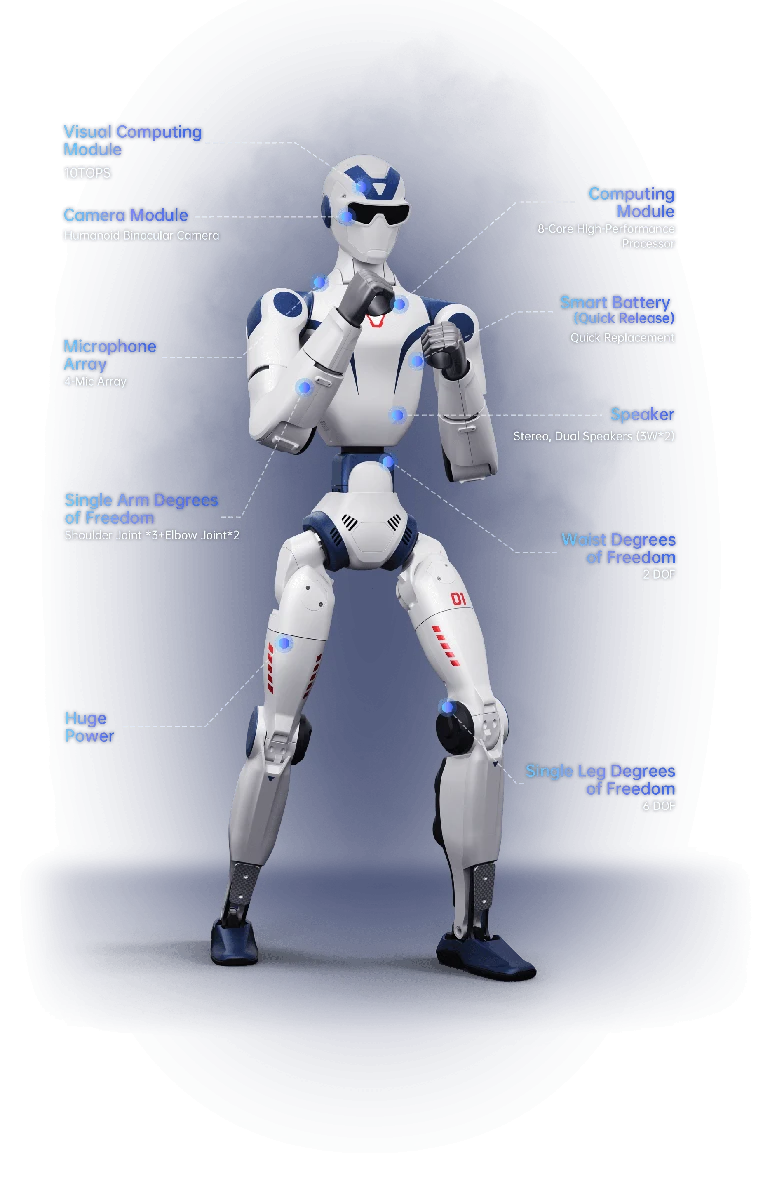
R1 AIR, R1 and EDU differ in arm and body joints. The page labels an arm-torque row in kg; its footnote concerns arm load. Do not interpret the displayed 2 kg as torque.
AIR has a monocular camera; R1/EDU binocular cameras.
SDK and Integration
Development access varies by edition. Public Unitree repositories do not grant development rights to base retail models.
| API type | Open control interfaces and EDU secondary development |
|---|---|
| Languages | C++, Python |
| ROS support | Exact R1 support not verified in the reviewed ROS 2 README; obtain model documentation. |
| Simulation | Supplier states support for mainstream simulation platforms; verify exact R1 SDK/simulation support before purchase. |
| Offline operation | Local DDS control examples exist; complete offline application behavior unverified. |
| Teleoperation | SDK-based developer workflows; exact supported hardware and access need confirmation. |
| Software updates | Manufacturer OTA updates; signing and rollback details not reviewed. |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Use for education, demonstrations and low-cost research. R1 AIR/R1 do not list secondary development; choose R1 EDU if programming access is required. |
Safety Notes
Supplier warns that the humanoid robot has complex structure and immense power output and that users must keep a sufficient safety distance. Some sample functions are still being developed and tested.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No public product-specific CE certificate was verified on the official product page. Request declaration of conformity before EU resale or factory deployment. |
| ISO 10218 | Requires buyer review | International | Likely not appropriate as an industrial robot for production tasks without significant validation. |
| ISO/TS 15066 | Requires buyer review | International | Do not assume collaborative safety merely because the robot is small. |
Video Evidence
Commercial Readiness
| Pricing | R1 standard USD 5,900; AIR USD 4,900; EDU by quotation. Observed 1 November 2026, excluding tax/freight. |
|---|---|
| Price range | 5900.00 USD |
| Lead time | Needs verification |
| Availability regions | Global direct/distributor availability reported |
| Spare parts | Confirm batteries, chargers, hands, sensors and actuator replacement availability before purchase. |
| Warranty | 6 months AIR / 8 months R1 / 12 months EDU; detailed exclusions apply. |
| Configuration and pricing basis | Standard 26-joint R1. AIR is a separate 20-joint USD 4,900 configuration; EDU by quotation. |
| Distributors and service | Local integrator and repair coverage not verified in this model review. |
Research snapshot: 1 November 2026. Confirm configuration, destination, taxes, transport and acceptance terms in a binding quotation.
Specifications
| Height | 1230 mm |
|---|---|
| Weight | 29.00 kg |
| Payload | Unknown |
| Runtime | 60 min |
| Battery and runtime conditions | Quick-release lithium battery; about one hour claimed, task conditions unspecified. |
| Degrees of freedom | 26 |
| Max speed | Unknown |
| Variants | R1 AIR, R1, R1 EDU Source ↗ |
| Locomotion | Small bipedal humanoid Source ↗ |
| Model-specific interpretation | AIR / R1 / EDU: 20 / 26 / 26–40 joints; 27 / 29 / 29 kg approximate with battery. Source ↗ |
| Standing width × depth | 357 × 190 mm Source ↗ |
| Arm maximum load | About 2 kg shown under a torque-labelled row; footnote refers to posture-dependent load. Unit/label conflict requires supplier clarification. Source ↗ |
| Battery life | About 1h Source ↗ |
| Secondary development | Available on R1 EDU; not listed for R1 AIR or R1 Source ↗ |
| Warranty period | 6 months R1 AIR / 8 months R1 / 12 months R1 EDU Source ↗ |
Sources and Further Reading
-
About Unitree — corporate history ↗
Unitree Robotics · Accessed Nov 1, 2026
Manufacturer history: 2016 founding; G1, R1 and H2 announcement dates; demonstrations and internal manufacturing test claims. These are not independent deployment tests.
-
Unitree after-sales terms ↗
Unitree Robotics · Accessed Nov 1, 2026
Warranty starts on receipt; exclusions include falls, overloading, unauthorized changes and damage from developer programs. Return freight and service charges depend on diagnosis.
-
Unitree MuJoCo official simulator ↗
Unitree Robotics · Accessed Nov 1, 2026
C++ and Python low-level simulation with SDK2/DDS; configuration names include H1, G1 and H2. Check exact joint layout before sim-to-real use.
-
Unitree official open source page ↗
Unitree Robotics · Accessed Nov 1, 2026
Official page listing Unitree simulation, ROS, SDK, reinforcement learning, imitation learning and teleoperation repositories.
-
Unitree R1 product page ↗
Unitree Robotics · Accessed Nov 1, 2026
Official supplier product page. R1 is positioned as an ultra-lightweight customizable humanoid, not a factory-ready production worker.
-
Unitree ROS 2 official repository ↗
Unitree Robotics · Accessed Nov 1, 2026
README lists G1 and H1-2 low-level examples and H1 communication; Ubuntu 20.04/Foxy and 22.04/Humble. Does not establish support for every newer model.