Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | DEEP Robotics DR02 Pro |
|---|---|
| Model profile | 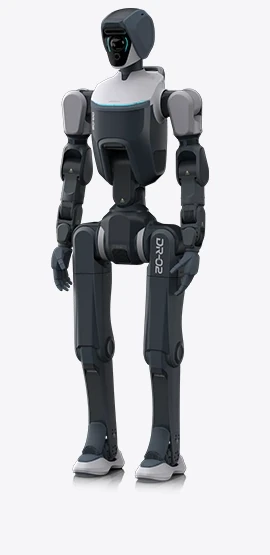 Explore DR02 Pro ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | Unknown |
| Runtime | 150 min |
| SDK/API | Public BSD-3-Clause C++ ROS2 SDK2 has a distinct dr 02_pro package, with low-level joint data/control, high-level gait/velocity, modes, battery/fault and audio examples. Real AOS uses Ubuntu 24.04/Jazzy; Pro NOS 22.04/Humble. Separate MuJoCo and Isaac Lab AMP workflows exist. Pro adds documented Mimic, retargeting and Pico waist/arm teleoperation. Match delivered firmware, model and message versions; open interface code does not license all onboard models or certify physical performance. Separate service docs also expose TCP/UDP heartbeat, mode, gait and velocity interfaces. The September Pro usage guide documents mapping, localisation and navigation; these capabilities must not be transferred to Standard or to an unconfirmed firmware build. |
| Programming | C++ ROS2 SDK2 low-level joint and high-level motion interfaces; AOS Ubuntu 24.04/Jazzy; Pro NOS 22.04/Humble; match delivered host and firmware |
| Compliance | CE marking: Unknown China radio equipment model approval: Supplier claimed IP66 ingress protection: Supplier claimed |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China service portal, International sales inquiry; model/country coverage by contract |
| Last verified | Nov 2, 2026 |
| Factory fit | Editorial: a seven-joint-arm development platform with richer perception and public Pro software for a bounded, supervised industrial pilot. Claimed IP66 and modular replacement are useful engineering features, while exact tool load, safety validation, production cycle/intervention data and local service remain unresolved. |