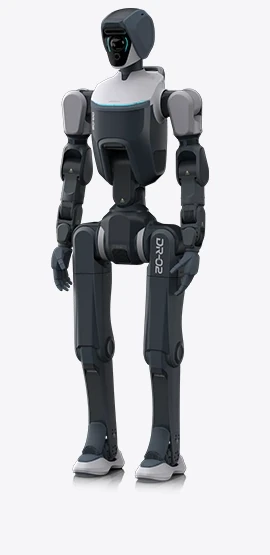
Industrial Applications
Editorial: a seven-joint-arm development platform with richer perception and public Pro software for a bounded, supervised industrial pilot. Claimed IP66 and modular replacement are useful engineering features, while exact tool load, safety validation, production cycle/intervention data and local service remain unresolved.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Pro: 31 body joints—legs 12, arms 14, waist 3, neck 2; grippers/dexterous hands are configurable and not added to this body count. Both 680 mm arm length EX end effector. Earlier brochure 10 kg maximum DUAL-ARM payload and current 10 kg continuous-operation load do not establish a per-arm rated load. Original 20 kg whole-body carrying claim is another scope. Per-arm payload scalar remains unknown; repeatability, duty curves and exact hand actuation unverified.
Current Pro matrix: octa-core 64-bit industrial processor plus NVIDIA AGX Orin 275 TOPS as standard, optional AGX Thor 2070 TOPS marketing figure; three depth cameras, one LiDAR, one wide-angle camera, mic/speaker. TOPS comparison precision not specified. SLAM, navigation, forward avoidance and autonomous charging listed in current table. February brochure marked SLAM/voice future OTA; current Pro page and field tests show later progress, without proving every delivered version includes all features.
SDK and Integration
Public BSD-3-Clause C++ ROS2 SDK2 has a distinct dr 02_pro package, with low-level joint data/control, high-level gait/velocity, modes, battery/fault and audio examples. Real AOS uses Ubuntu 24.04/Jazzy; Pro NOS 22.04/Humble. Separate MuJoCo and Isaac Lab AMP workflows exist. Pro adds documented Mimic, retargeting and Pico waist/arm teleoperation. Match delivered firmware, model and message versions; open interface code does not license all onboard models or certify physical performance. Separate service docs also expose TCP/UDP heartbeat, mode, gait and velocity interfaces. The September Pro usage guide documents mapping, localisation and navigation; these capabilities must not be transferred to Standard or to an unconfirmed firmware build.
| API type | C++ ROS2 SDK2 low-level joint and high-level motion interfaces |
|---|---|
| Languages | C++ SDK, Python simulation and training |
| ROS support | AOS Ubuntu 24.04/Jazzy; Pro NOS 22.04/Humble; match delivered host and firmware |
| Simulation | MuJoCo per-edition model; Isaac Sim 5.1/Isaac Lab 2.3.2 AMP. Pro-only Mimic/retarget/Pico tools. |
| Offline operation | SDK describes offline local AOS/NOS hosts and source transfer; full AI/navigation/telemetry offline scope unverified |
| Teleoperation | Pico/XRoboToolkit waist and dual-arm teleoperation with optional end effectors is documented for Pro only. |
| Software updates | Supported firmware lifetime, signing and rollback unverified |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Native BSD-3-Clause SDK licence inspected; robot firmware, proprietary policies and third-party assets have separate rights. Correct Developer Mode, one command publisher and physical stop access required. Simulator has 29 Pro actuators plus two virtual SDK slots; not every onboard service is simulated. |
Current GitHub root documents Jazzy/24.04 and Humble/22.04; an older developer build page mentions Foxy. Use product-specific current instructions. Pro simulation’s 29-actuator mapping does not establish the physical 31-joint body count as false.
Safety Notes
No signed exact-model EU declaration, complete functional-safety file, independent stopping/fall envelope or payload duty validation inspected. IP protection does not establish safe human collaboration or tool operation. Manufacturer restricts 4 m/s extreme-test speed from external use; core scalar uses current 1 m/s maximum WORKING speed. Initial SDK motion tests require safety suspension, correct Developer Mode and a single command publisher. Teleoperation Emergency is a software pose hold, not hardware emergency stop; HES telemetry is not a measured stop test. Hardware guide requires unused connector caps to remain sealed and supplied connectors fully locked; open or misassembled ports can invalidate weather protection.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No signed declaration for this exact configuration inspected; company/quadruped certificates not transferred. |
| China radio equipment model approval | Supplier claimed | China | Open evidence |
| IP66 ingress protection | Supplier claimed | International | Open evidence |
Commercial Readiness
| Pricing | Issuer August 7, 2026 comparison lists DR02 family from CNY 349000, with no exact Standard/Pro configuration, tax or current quote validity. This historical comparison is not a verified Pro landed price. Robots Europa uses quotation; UK seller requires OEM confirmation. No current per-edition price scalar assigned. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China / international supplier inquiry; exact regional SKU by contract |
| Spare parts | Modular service claims do not prove regional stock or a repair SLA. |
| Warranty | Generic receipt-based warranty policy lacks an inspected exact DR02 duration and regional scope. Water-damage exclusions and all-weather claims need explicit contract reconciliation; pack, hand, modification and repair-shipping terms unverified. |
| Configuration and pricing basis | Exact configuration quote required |
| Distributors and service | EU and UK inquiry routes exist; exact OEM appointment, configuration and local repair coverage require confirmation. |
No generic delivery policy or portfolio service guarantee assigned as an exact humanoid contract.
Specifications
| Height | 1800 mm |
|---|---|
| Weight | 78.00 kg |
| Payload | Unknown |
| Runtime | 150 min |
| Battery and runtime conditions | Current Chinese matrix: about 3 h unloaded/about 2.5 h loaded, about 2.5 h charging. Test-duty specifics unreported; 150-minute scalar is the loaded maker claim. February 2026 brochure described a removable 20 Ah/1440 Wh pack, but latest matrix does not establish the current pack capacity/voltage or hot-swap continuity. Do not equate accessible 72 V ports with nominal pack voltage. |
| Degrees of freedom | 31 |
| Max speed | 1.00 m/s |
| Peak joint torque definition | Hardware guide includes370 Nm peak on selected waist/hip/knee axes, 138 Nm on selected arm/waist/hip axes and50 Nm on neck/wrist/ankle axes. Peak values are not continuous loads. Source ↗ |
| Current versus February configuration | Current Chinese table: 1800×558×400 mm; 78 kg Pro WITH pack. February 2026: 1750 mm/75 kg. Use current maker matrix as viewed Nov 2; confirm exact BOM. Source ↗ |
| Ingress protection | IP66 full-body manufacturer claim; original test report and delivered configuration scope unverified. Source ↗ |
| Operating temperature | −20°C to 55°C manufacturer range; not a fire, chemical, explosive-atmosphere or safe-human-contact rating. Source ↗ |
| Public guide and port scope | Hardware guide: 72 V external power up to 360W; 24 V up to 250W. Connector availability differs by edition; sealed caps/locked cables required. Not nominal pack voltage. Source ↗ |
| Speed definitions | Current maximum WORKING 1 m/s; headline walking 1.5 m/s.4 m/s is restricted extreme laboratory test, not a customer operating limit. Source ↗ |
| Load definition | 10 kg continuous-operation load in current table; earlier 10 kg MAXIMUM DUAL-ARM. Original 20 kg carrying is distinct. Per-arm rated load unknown. Source ↗ |
| Edition and simulation scope | Pro 31 body joints; MuJoCo 29 actuators plus two virtual SDK slots. Pico/Mimic documented for Pro. Source ↗ |
| Quick-detach modules | Forearms, full arms and full legs advertised as removable/replaceable. Local inventory, replacement time and trained service scope unverified. Source ↗ |
Sources and Further Reading
-
Current Chinese DR02 and Pro configuration matrix ↗
DEEP Robotics · Accessed Nov 2, 2026
Current maker matrix distinguishes 21-joint Standard and 31-joint Pro. Both approximately 1800 × 558 × 400 mm, weights 68/78 kg including battery, about three hours unloaded or 2.5 hours loaded, 2.5-hour charging. Maximum working speed is 1 m/s; 4 m/s is a restricted laboratory test. Current Pro navigation/charging features differ from the dated February brochure. Contract and delivered hardware govern.
-
Current customer-service and public documentation portal ↗
DEEP Robotics · Accessed Nov 2, 2026
Portal lists DR02 for support tickets with model/serial/version details, telephone 19033924528 and document links. Training-plan panel says coming soon; no exact humanoid course, warranty duration or EU repair SLA established. No login, ticket, message or form submission performed.
-
DR02 hard emergency-stop status interface ↗
DEEP Robotics · Accessed Nov 2, 2026
Documentation exposes the HES hard-stop state via basic-status telemetry. A status bit is not a measured stopping distance, proof of independent safety integrity or confirmation that every software hold removes motor power.
-
DR02 Pro Pico teleoperation ↗
DEEPRoboticsLab GitHub account · Accessed Nov 2, 2026
C++17 ROS2 Pico/XRoboToolkit project controls waist and arms with optional supported end effectors and data recording. README identifies BSD-3-Clause; SDK root licence was separately inspected. Its Emergency mode is a SOFTWARE POSE HOLD, not a hardware emergency stop. Keep physical stop access; simulator build must not control hardware.
-
DR02 Pro reference-motion training ↗
DEEPRoboticsLab GitHub account · Accessed Nov 2, 2026
Current maker repository identifies Pro as the main robot and documents Isaac Lab motion tracking, retargeting and ONNX evaluation. A research pipeline and demonstration do not establish autonomous task reliability or support for every retail hardware revision.
-
DR02 Pro SDK product guide ↗
DEEPRoboticsLab GitHub account · Accessed Nov 2, 2026
Product guide describes real and simulated workflows, AMP/Mimic inference and RealSense camera access. Physical SDK processes may control hardware from either development or robot hosts. First motion tests require safety suspension, correct Developer Mode and a single joint-command publisher; simulation builds must not control the physical robot.
-
DR02 public developer resource and edition index ↗
DEEP Robotics · Accessed Nov 2, 2026
Primary documentation links separate Standard and Pro SDK, simulator and URDF entries. Pico teleoperation, motion retargeting and Mimic resources are explicitly Pro-specific. Model identity and package selection matter; this is not a universal DR01 SDK.
-
DR02 ROS2 SDK2 and inspected BSD licence ↗
DEEPRoboticsLab GitHub account · Accessed Nov 2, 2026
Current native C++ ROS2 repository has dr02_std and dr02_pro packages, motion/state/joint interfaces, battery/fault monitoring and audio examples. Inspected root LICENSE is BSD-3-Clause, copyright 2026 DEEPRoboticsLab. AOS runs Ubuntu 24.04/Jazzy; Pro NOS runs 22.04/Humble, both ARM64 and described as offline hosts. Underlying robot firmware and AI models are not thereby universally licensed BSD.
-
English delivery, warranty and privacy policy ↗
DEEP Robotics · Accessed Nov 2, 2026
Generic policy advertises 30 working-day delivery, buyer-paid shipping and repairs/replacement subject to exclusions, but gives no inspected exact DR02 warranty duration. Its robot-dog FAQs and water/unauthorised-repair exclusions must not be converted into a verified all-weather humanoid contract. Policy describes account, usage, location and device logs; no exact DR02 offline AI or EU-hosting guarantee.
-
English DR02 family introduction ↗
DEEP Robotics · Accessed Nov 2, 2026
Manufacturer family description supports IP66 and −20°C to 55°C claims, modular forearm/arm/leg replacement and industrial positioning. It does not provide an exact-model safety certificate, quantified repair time or independent factory uptime.
-
European DR02 quotation route and specification conflicts ↗
Robots Europa (seller) · Accessed Nov 2, 2026
Seller offers Germany/Austria/Switzerland/EU quotation, without a fixed DR02 price. Its combined 65 kg/31-joint/20 kg payload table mixes edition and payload scopes compared with maker matrices. Not used as core technical evidence. OEM appointment, stock, exact declaration and repair authorisation unverified.
-
February 2026 DR02 and Pro manufacturer datasheet ↗
DEEP Robotics; official download CDN · Accessed Nov 2, 2026
Two-page maker PDF linked from official support. Earlier configuration: 1750 mm; 65 kg Standard / 75 kg Pro with battery; 21/31 joints; 10 kg maximum DUAL-ARM payload; swappable 20 Ah / 1440 Wh pack. SLAM and voice are marked future OTA features. Its 4 m/s extreme test is not open to customers for safety reasons. Current Chinese matrix has revised dimensions, mass, working speed and feature list.
-
Isaac Lab AMP training repository ↗
DEEPRoboticsLab GitHub account · Accessed Nov 2, 2026
README identifies the DR02 AMP environment, Isaac Sim 5.1.0, Isaac Lab 2.3.2, Python 3.11 and RSL-RL 5.0.1. ONNX policy export is documented. Training assets and deployment packages are separate; a trained policy is not a validated factory behaviour.
-
Product-specific MuJoCo simulation ↗
DEEPRoboticsLab GitHub account · Accessed Nov 2, 2026
Repository supports Standard and Pro with ROS2 Humble/Ubuntu 22.04/Python 3.10 or Jazzy/24.04/Python 3.12. Matching drdds versions and ROS domain required. Simulator is separate from SDK and does not reproduce every onboard navigation, audio or peripheral service.
-
Pro simulation control limits and virtual joints ↗
DEEP Robotics · Accessed Nov 2, 2026
Primary developer page describes a Pro MuJoCo model with 29 actuators and a 31-slot SDK vector whose final two entries are virtual placeholders. Upper mode constrains base/legs in simulation; it is not equivalent to physical whole-body stability. High-level motion and audio/peripheral services are not simulated. This is a software mapping, not proof the physical 31-joint robot has only 29 joints.
-
UK DR02 assessment and conditional availability ↗
The Robot Group (seller) · Accessed Nov 2, 2026
The Robot Group lists DR02 evaluation and says supply depends on configuration, lead time and OEM confirmation. This supports an inquiry route, not verified UK stock, an EU office or a signed exact-model safety file.
-
Hangxing II at the 2026 Hangzhou Marathon ↗
DEEP Robotics; reprinted by Tonghuashun · Published Nov 1, 2026 · Accessed Nov 2, 2026
Maker-authored November 1 report reprinted by Tonghuashun names the jointly developed Hangxing II traffic configuration and four deployment POINTS around Huanglong Sports Centre. Reports 178 cm, 275 TOPS and multiple sensors; no exact Standard/Pro mapping or battery/joint rating. Prior trials included remote takeover. It is a task-specific application, not independently audited paid industrial fleet operation.
-
DR02 public development-guide index ↗
DEEP Robotics customer-service documentation · Published Oct 28, 2026 · Accessed Nov 2, 2026
Public service-document index opened without login through its documented read API. October 28 page links hardware, usage and software development guides. Usage guide explicitly applies to Pro mapping/navigation; other company manuals are not automatically DR02 documentation.
-
October holiday DR02 traffic field tests ↗
DEEP Robotics · Published Oct 16, 2026 · Accessed Nov 2, 2026
Maker explicitly calls the rainy Hangzhou deployment a real-scenario TEST: traffic direction, pedestrian/vehicle avoidance and multilingual guidance around Xixi Wetland, Lingyin and Wenyi West Road. No exact Standard/Pro configuration, paid acceptance or independently audited intervention/uptime data supplied.
-
Hangzhou reporter account of DR02 street tests ↗
Hangzhou.com.cn / Hangzhou Tong · Published Oct 7, 2026 · Accessed Nov 2, 2026
Reporter Lu Bingxu describes robots wearing TEST-labelled vests and quotes company staff on navigation, avoidance and multilingual guidance. Corroborates a bounded public street test; does not independently establish all-weather endurance, unassisted deployment or customer purchase.
-
DEEP updated STAR Market prospectus ↗
Yunshenchu Technology Co., Ltd. / Shanghai Stock Exchange · Published Sep 28, 2026 · Accessed Nov 2, 2026
Primary issuer filing: legal 云深处科技股份有限公司 / Yunshenchu Technology Co., Ltd.; incorporated November 29, 2017, joint-stock conversion October 31, 2025, controller Zhu Qiuguo. H1 2026 revenue CNY 259.2426m and net loss CNY 8.8063m; DR-series sales six units/CNY 2.7893m, versus one/CNY 0.823m in 2025 and three/CNY 1.1711m in 2024. Appendix discloses separate Chinese radio-model approvals for DR02 and Pro. Figures are issuer disclosures, not independent fleet uptime.
-
DR02 software development guide V1.1.0 ↗
DEEP Robotics customer-service documentation · Published Sep 9, 2026 · Accessed Nov 2, 2026
Guide dated September 9 describes TCP/UDP monitoring and commands, heartbeat, mode/gait/velocity control, state/fault messages and ROS2/DDS topics. Provides example interfaces rather than independent stop-latency, security-hardening or production-reliability evidence.
-
DR02 Pro software usage guide V1.0.1 ↗
DEEP Robotics customer-service documentation · Published Sep 8, 2026 · Accessed Nov 2, 2026
Guide dated September 8 explicitly requires DR02 Pro for mapping/navigation. Documents local map collection, management, relocation, navigation and camera-stream access. Remote login/VNC setup uses documented defaults; installations need credential changes and network controls. This is a released workflow beyond the February future-OTA note, not proof of every shipped firmware entitlement or safe operation in arbitrary public spaces.
-
Issuer reply on humanoid sales, pricing and deployments ↗
Yunshenchu Technology Co., Ltd. / Shanghai Stock Exchange · Published Aug 7, 2026 · Accessed Nov 2, 2026
Primary reply distinguishes exploratory industrial work, prospective power-sector deliveries, a firefighting R&D application and university research use. Historical comparison table lists DR01 at 145 cm/from CNY 600000 and DR02 at 175 cm/from CNY 349000, without complete current configuration/tax terms. Named universities are Zhejiang University and Nanyang Technological University; quantities and acceptance metrics not provided.
-
DR02 hardware guide V1.1.0, dated July 31 ↗
DEEP Robotics customer-service documentation · Published Jul 31, 2026 · Accessed Nov 2, 2026
Dated hardware guide documents kinematic ranges, peak joint torques, edition-dependent connectors and sensor frames. Selected hip/knee axes reach 370 Nm peak; this is not an arm payload or continuous torque guarantee. External 72 V supply is limited to 360 W and 24 V supply to 250 W; enabled ports differ by edition. Connector caps and locking are necessary for the stated weather sealing.
-
DR02 launch press release distributed by Newswire ↗
DEEP Robotics / Newswire Korea · Published Oct 10, 2025 · Accessed Nov 2, 2026
Release explicitly supplied by DEEP Robotics and posted October 10, 2025, says DR02 launched October 9. Original 175 cm height and 20 cm stair claim differ from later 25 cm brochure and revised current dimensions. Its 10 kg dual-arm working load and 20 kg carrying claim have different scopes; neither is a verified per-arm rating.