Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | MagicLab MagicBot Z1 Developer Edition |
|---|---|
| Model profile | 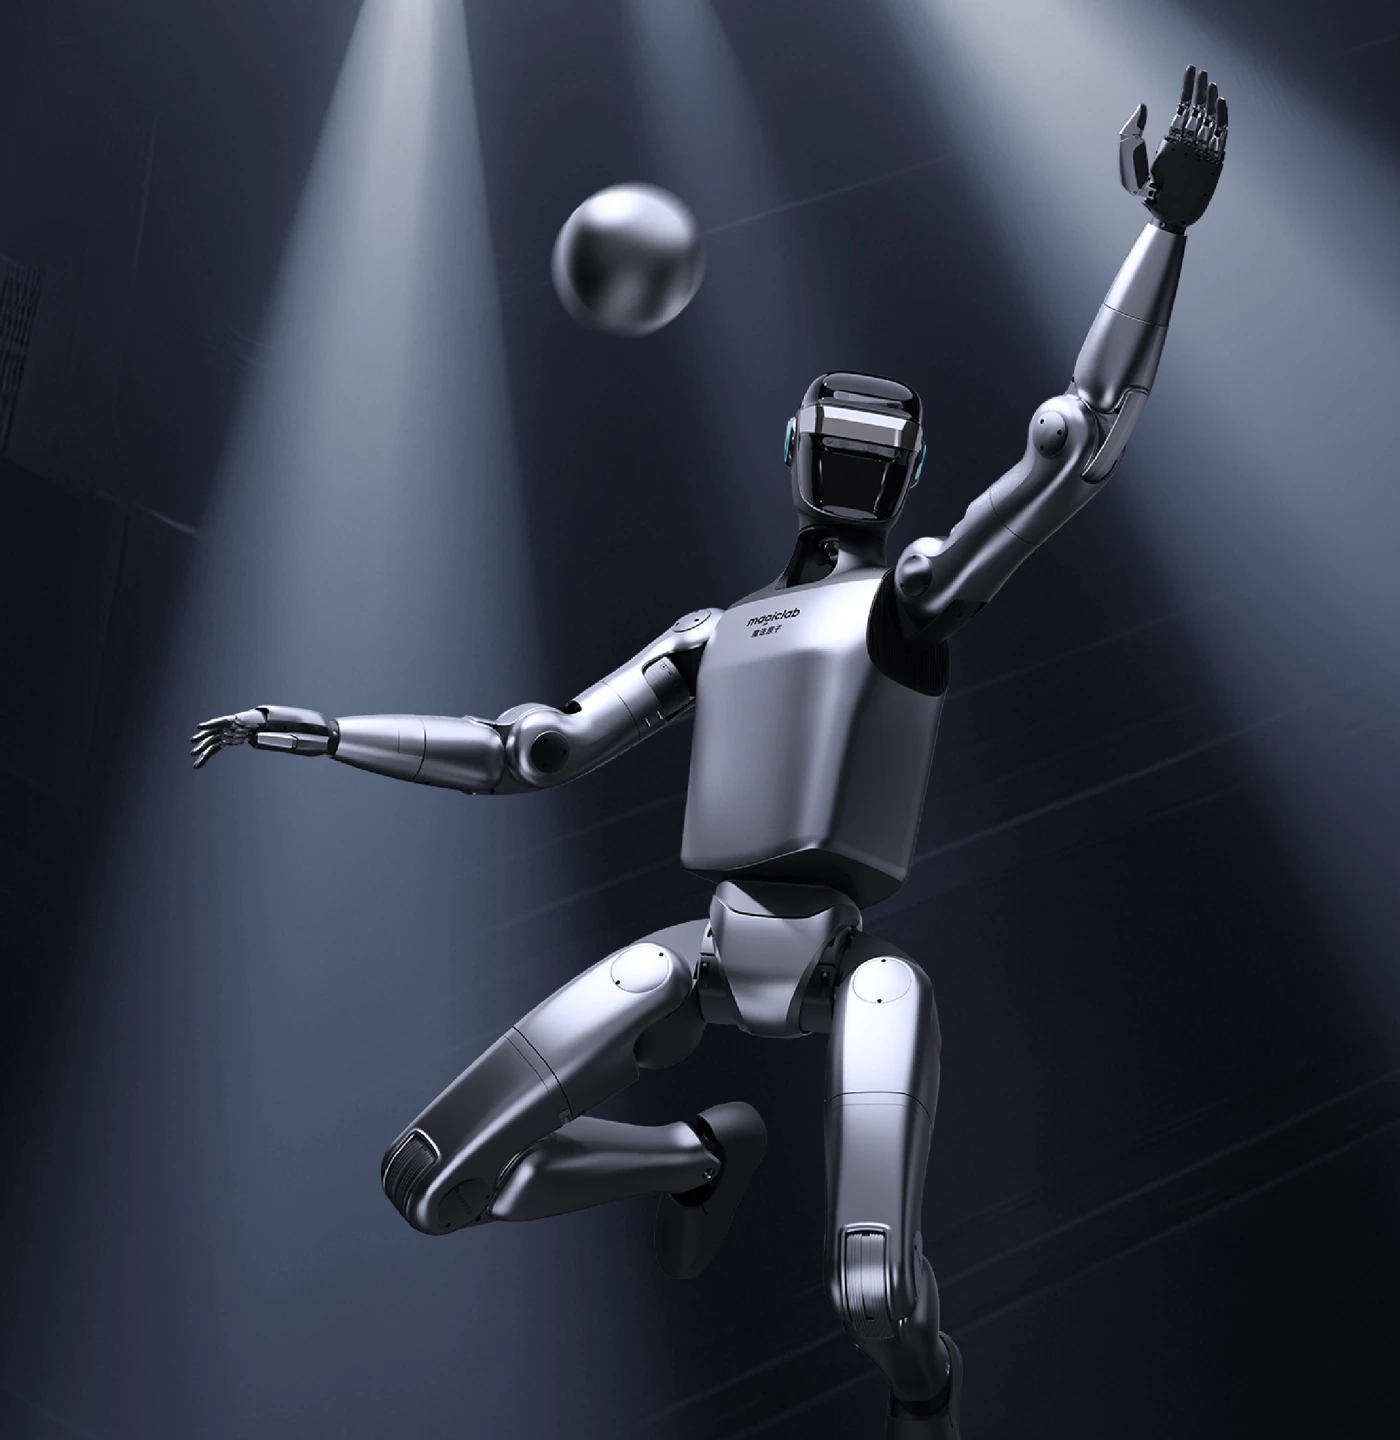 Explore MagicBot Z1 Developer Edition ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | Unknown |
| Runtime | 120 min |
| SDK/API | Official native BSD C++20/Python3.10 SDK supports developer configuration, not Standard entitlement. Ubuntu22.04/GCC11.4/CMake3.16/Eigen/OpenCV4.5 suggested. SLAM API limited to feature-rich static flat indoor spaces smaller than100×100 m, intended for research/education; industrial use requires separate scope. |
| Programming | Native C++20/Python3.10 development supported; Native control SDK; ROS description/RViz tooling is not an inspected full ROS2 control driver |
| Compliance | CE marking: Unknown ISO 10218 review required: Requires buyer review |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China and international manufacturer inquiry, European seller support claimed; exact model/country contract scope unverified |
| Last verified | Nov 2, 2026 |
| Factory fit | Editorial: Developer version supports control/locomotion experiments with public native APIs, descriptions and research simulations. Small-scene public SLAM examples, demonstrations and laboratory load ratings do not establish unattended industrial reliability or safe unguarded collaboration. |