Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | RobotEra XBot-L |
|---|---|
| Model profile | 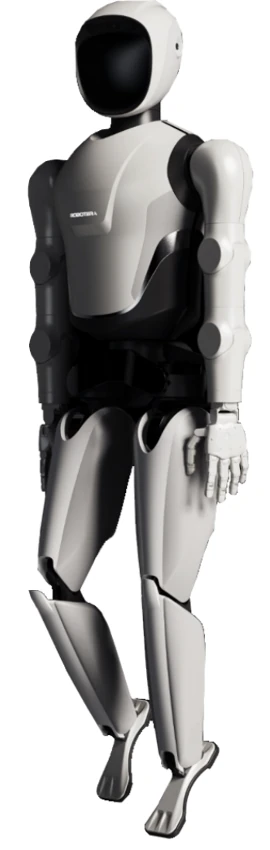 Explore XBot-L ↗ |
| Status | Announced |
| Readiness score | Unscored |
| Payload | Unknown |
| Runtime | Unknown |
| SDK/API | Research locomotion RL framework and sim-to-sim verification. Exact onboard ROS /control middleware unverified; research framework is not current Python ROS 2 SDK support proof. Official Humanoid-Gym Isaac Gym training, MuJoCo sim-to-sim and real-world zero-shot transfer reported for XBot-L. Public repository rights are separate from firmware, model weights, commercial software and data. Match exact hardware, messages and supported firmware; not an independent safety controller. |
| Programming | Research locomotion RL framework and sim-to-sim verification; Exact onboard ROS /control middleware unverified; research framework is not current Python ROS 2 SDK support proof |
| Compliance | CE marking: Unknown |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China manufacturer support and public developer repositories, European seller service claimed; country/model contract scope unverified |
| Last verified | Nov 2, 2026 |
| Factory fit | Editorial: an explicitly named historical research platform used for locomotion policy transfer. Original paper figures provide height, mass and distinguished total/actuator counts. No ta current turnkey factory worker; arm load, commercial software, warranty and orderability remain unknown. |