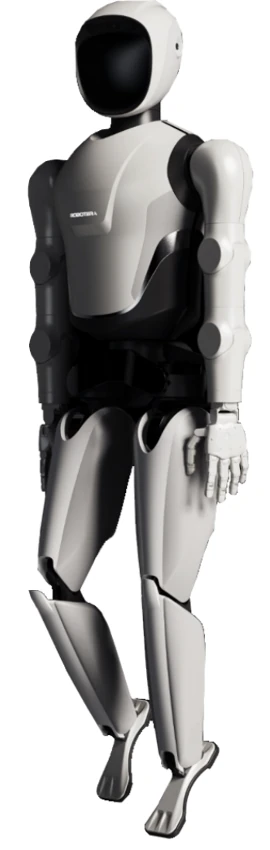
Industrial Applications
Editorial: an explicitly named historical research platform used for locomotion policy transfer. Original paper figures provide height, mass and distinguished total/actuator counts. No ta current turnkey factory worker; arm load, commercial software, warranty and orderability remain unknown.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Original paper Fig5 labels 60 TOTAL degrees of freedom versus 54 ACTUATED motors. These are different kinematic/actuation counts; not all independent command axes. Locomotion experiments do not establish arm payload, hand service capability or tool qualification.
Research paper describes body/ IMU, joint and locomotion observations for sim-to-real policy training. No exact commercial vision, compute, speech or autonomy product bundle confirmed; current L7 / STAR1 peripherals not transferred.
SDK and Integration
Research locomotion RL framework and sim-to-sim verification. Exact onboard ROS /control middleware unverified; research framework is not current Python ROS 2 SDK support proof. Official Humanoid-Gym Isaac Gym training, MuJoCo sim-to-sim and real-world zero-shot transfer reported for XBot-L. Public repository rights are separate from firmware, model weights, commercial software and data. Match exact hardware, messages and supported firmware; not an independent safety controller.
| API type | Research locomotion RL framework and sim-to-sim verification |
|---|---|
| Languages | Python training and MuJoCo scripts |
| ROS support | Exact onboard ROS /control middleware unverified; research framework is not current Python ROS 2 SDK support proof |
| Simulation | Official Humanoid-Gym Isaac Gym training, MuJoCo sim-to-sim and real-world zero-shot transfer reported for XBot-L |
| Offline operation | Complete motion, speech, AI, remote-support and telemetry offline scope unverified |
| Teleoperation | Exact delivered package, licence and supervision requirements must match order |
| Software updates | Firmware signing, patch support lifetime and rollback unverified |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Public repository rights are separate from firmware, model weights, commercial software and data. Match exact hardware, messages and supported firmware; not an independent safety controller. |
No complete current whole-body hardware safety/warranty manual inspected. Component documentation and public source presence do not establish all product rights.
Safety Notes
No exact signed EU conformity dossier, independent stopping/fall envelope, safety-integrity rating or validated human-collaboration mode inspected. High joint torque, speed or hand load are not safe collaboration evidence. Follow delivered manual, physical test protection and system-level integration assessment; public ROS services are not a certified stop system.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No exact-model signed declaration and complete delivered configuration dossier inspected. For L7 / M7 / Q5, European seller promises a declaration; promise is not independent verification. |
Commercial Readiness
| Pricing | Current exact-configuration manufacturer price not verified; quote must specify tax, shipping, hands, compute, software and commissioning. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China manufacturer/project inquiry; exact overseas scope by contract |
| Spare parts | No independently inspected local inventory or repair response SLA. |
| Warranty | Exact whole-robot, battery, hand and regional warranty period/exclusions unverified. Public software/component licences are not hardware warranties. |
| Configuration and pricing basis | Exact configuration quotation required |
| Distributors and service | Current exact-model OEM appointment and local repair scope require written confirmation. |
No public exhibition, company order book or aggregate component count treated as delivered robot fleet.
Specifications
| Height | 1650 mm |
|---|---|
| Weight | 57.00 kg |
| Payload | Unknown |
| Runtime | Unknown |
| Battery and runtime conditions | Exact battery capacity, voltage, single-pack runtime, charging and power-supply arrangement not verified for this configuration. |
| Degrees of freedom | 60 |
| Max speed | Unknown |
| Total joints versus actuators | 60 TOTAL DOF; 54 actuated motors in original author Fig5. Full kinematic count not identical to controllable actuator count. Source ↗ |
Sources and Further Reading
-
CC BY 4.0 licence linked by original research paper ↗
Creative Commons / ar Xiv licence link · Accessed Nov 2, 2026
Original ar Xiv paper licence link resolves to CC BY 4.0. Cropped Fig5 images credit authors, paper and licence and state the crop. No third-party figure credit identified. This article licence does not cover unrelated company product photos.
-
Current RobotEra company, legal name and portfolio ↗
ROBOTERA · Accessed Nov 2, 2026
Rendered current official application, not the empty static HTML. Founded August 2023 by Chen Jianyu; company claims Tsinghua university shareholding. Footer now says 北京星动纪元科技股份有限公司. Current contact address: 7 F, VIA Building, Tsinghua Science Park, Haidian, Beijing. Current complete cap table and formally registered English legal name unverified. Product routes include L7, Q5, M7 and XHAND end-effectors; /product/Lite and /product/PRO are HANDS, not new humanoid bodies.
-
Historical XBot-S/L research control framework ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
Official README explicitly verifies locomotion on XBot-S 1.2 m and XBot-L 1.65 m. Isaac Gym training, MuJoCo sim-to-sim and real transfer; uses XBot-L as example. Repository-wide licence absent at root; third-party base sub directory has separate licence. Does not establish current retail availability or full manipulation SDK.
-
Founder first-hand historical platform account ↗
Lenovo Capital; interview with Chen Jianyu · Published Sep 5, 2024 · Accessed Nov 2, 2026
Investor-hosted direct founder interview: university project began 2022, company incubated 2023; Xiaoxing family had six engineering generations by August 2024. Iteration descriptions are not six separately marketed SKUs. Exact Xiaoxing generation-to- XBot / STAR1 mapping is not established; avoid copying specifications across names.
-
Original Humanoid-Gym paper and labelled hardware figure ↗
Xinyang G u, Yen-Jen Wang and Jianyu Chen / ar Xiv · Published May 18, 2024 · Accessed Nov 2, 2026
Original author paper first submitted April 8, 2024, revised May 18. Fig u re 5 on PDF page 5 visually read: XBot-S 1200 mm/38 kg/32 TOTAL DOF /26 actuated motors; XBot-L 1650 mm/57 kg/60 TOTAL DOF /54 actuated motors. Total kinematic count differs from actuator count. Real locomotion experiments are research evidence, not commercial deployment. ar Xiv source explicitly licences article CC BY 4.0; cropped original hardware illustration credited.