Comparison workspace
The machines, side by side.
Select up to four models. Compare their specifications, integration options, and commercial context — and keep the unknowns in view.
| Model intelligence | Beijing Humanoid Robot Innovation Center Embodied TienKung 3.0 |
|---|---|
| Model profile | 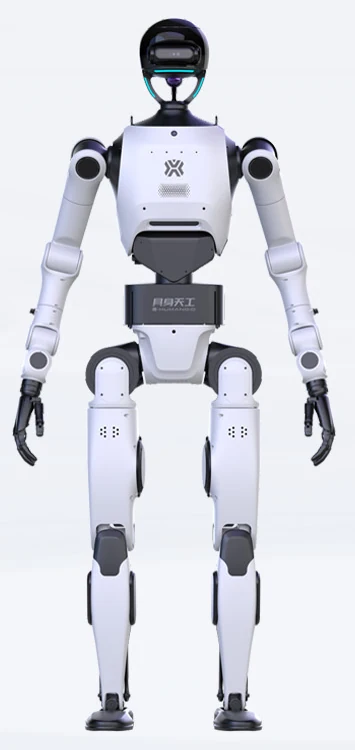 Explore Embodied TienKung 3.0 ↗ |
| Status | Commercially available |
| Readiness score | Unscored |
| Payload | Unknown |
| Runtime | Unknown |
| SDK/API | Native onboard joint, force-position, perception, voice and optional-hand SDK. Ubuntu 24.04 / ROS 2 Jazzy; vendor xos messages required. Separate xSIM_MUJOCO supports 3.0 with Humble/Jazzy bridge; integrated Gazebo/Isaac in SDK remains roadmap. Confirm exact model, compute, middleware, firmware and licence. WiseKaiWu Agent root licence requires prior written authorisation. Website privacy policy excludes robots and cloud products. |
| Programming | Native onboard joint, force-position, perception, voice and optional-hand SDK; Ubuntu 24.04 / ROS 2 Jazzy; vendor xos messages required |
| Compliance | CE marking: Unknown ISO 10218 review required: Requires buyer review |
| EU readiness | Unknown |
| Lead time | Needs verification |
| EU support | China manufacturer and project support; overseas scope by exact contract |
| Last verified | Nov 2, 2026 |
| Factory fit | Editorial: current full-size 31-body-joint research platform with seven-joint arms, optional hands and public onboardROS 2 Jazzy SDK. Dynamic launch demonstrations and mixed partner delivery support technical evaluation; earlier launch figures differ from current hardware, and independent production duty and European service remain unresolved. |