Industrial Applications
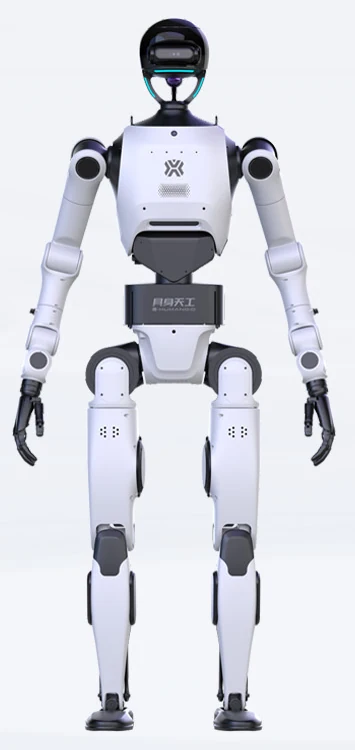
Editorial: current full-size 31-body-joint research platform with seven-joint arms, optional hands and public onboardROS 2 Jazzy SDK. Dynamic launch demonstrations and mixed partner delivery support technical evaluation; earlier launch figures differ from current hardware, and independent production duty and European service remain unresolved.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Current 31 BODY joints: head 2, waist 3, arms 14, legs 12; optional hands add configuration-dependent joints. Maximum 400 Nm joint torque is not an arm payload. Earlier launch coverage reports 43 full joints; its exact hand fitment is not the current default.
Current maker table lists depth camera, LiDAR and high-precision IMU, 4.8 GHz control and 2070 TOPS compute without precision basis. Future outdoor-navigation backpack/OCC surround perception remains prospective. Wi-Fi 6e, Bluetooth and 5 G availability need exact installed package.
SDK and Integration
Native onboard joint, force-position, perception, voice and optional-hand SDK. Ubuntu 24.04 / ROS 2 Jazzy; vendor xos messages required. Separate xSIM_MUJOCO supports 3.0 with Humble/Jazzy bridge; integrated Gazebo/Isaac in SDK remains roadmap. Confirm exact model, compute, middleware, firmware and licence. WiseKaiWu Agent root licence requires prior written authorisation. Website privacy policy excludes robots and cloud products.
| API type | Native onboard joint, force-position, perception, voice and optional-hand SDK |
|---|---|
| Languages | C++17, Python 3.12 |
| ROS support | Ubuntu 24.04 / ROS 2 Jazzy; vendor xos messages required |
| Simulation | Separate xSIM_MUJOCO supports 3.0 with Humble/Jazzy bridge; integrated Gazebo/Isaac in SDK remains roadmap |
| Offline operation | Complete autonomy, speech, model and remote-support offline scope unverified |
| Teleoperation | Exact supplied control and supervision package requires confirmation |
| Software updates | Firmware signing, patch lifetime and rollback unverified |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Confirm exact model, compute, middleware, firmware and licence. WiseKaiWu Agent root licence requires prior written authorisation. Website privacy policy excludes robots and cloud products. |
Public code or a model file does not certify safe real-world control. Native SDK and higher-level model services have separate rights and operating requirements.
Safety Notes
No exact signed EU declaration, independently tested stopping/fall envelope, safety integrity rating or validated human-collaboration mode inspected. Provide appropriate test supervision and physical fall/stop protection according to the delivered manual. Capability demonstrations are not a safety assessment.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No signed declaration and exact delivered-model conformity file inspected. Research use, government designation and competition participation do not establish EU conformity. |
| ISO 10218 review required | Requires buyer review | International | System-level engineering review category only; no certification or safe collaboration approval established. |
Commercial Readiness
| Pricing | No current dated exact-configuration public price verified. Quote must specify currency, tax, shipping, controller, hands, software entitlements and commissioning. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | Manufacturer / project inquiry; exact region and SKU unverified, United Kingdom: enquiry/evaluation planning; conditional delivery |
| Spare parts | No verified EU parts inventory or repair response commitment. |
| Warranty | Exact model, battery, hand and regional warranty unverified; 2.0 warranty policy is not automatically transferred. |
| Configuration and pricing basis | Exact configuration quotation required |
| Distributors and service | The Robot Group claims authorised UK assessment/supply. Product page conditions availability/delivery on conformity andmanufacturer confirmation; local stock, parts, repair authorisation and SLA unverified. |
Historical research and exhibition evidence does not establish current general orderability.
Specifications
| Height | 1700 mm |
|---|---|
| Weight | 64.50 kg |
| Payload | Unknown |
| Runtime | Unknown |
| Battery and runtime conditions | Current maker table: 15 Ah main plus 3 Ah auxiliary pack, hot-swappable. Voltage, current runtime and charging duration unverified; mixed partner delivery and demonstrations are not endurance measurements. UK seller lists at least 2 h without task conditions; lower-bound claim, not an exact runtime. |
| Degrees of freedom | 31 |
| Max speed | Unknown |
| Current versus launch | Current 1700 mm/64.5 kg/31 BODY joints; February 1690 mm/62 kg/43 FULL joints. Hand fitment, revision, posture and mass scope must match the delivered BOM. Source ↗ |
| Demonstrated obstacle traversal | Approximately 1m obstacle vault in February launch demonstration; controlled dynamic manoeuvre, not a 1m step specification or production safety validation. Source ↗ |
| Middleware and protocols | Current hardware: CANFD/EtherCAT. Inspected native SDK: ROS 2 Jazzy/xos. Generic MQTT/TCP-IP claim not confirmed as a complete 3.0 SDK contract. Source ↗ |
Sources and Further Reading
-
Current TienKung 3.0 manufacturer specification image ↗
Beijing Humanoid Robot Innovation Center / X-Humanoid · Accessed Nov 2, 2026
Current official table is an image at /oss/images/bg/bt/1.png, visually inspected: 170 cm/64.5 kg, 31 BODY joints, 15 Ah+3 Ah hot-swap battery, 2070 TOPS, 4.8 GHz control, IMU/depth/LiDAR, 400 Nm maximum joint torque. Optional hands and future navigation backpack are not standard. Earlier February launch figures 169 cm/62 kg/43 full joints describe a different reported configuration; delivered revision needs confirmation.
-
TienKung 3.0 MuJoCo environment and Apache licence ↗
Open-X-Humanoid GitHub account · Accessed Nov 2, 2026
Separate official MuJoCo 3.0 simulator includes joint torque/position control, IMU/sensor data and terrain assets; Python and ROS 2 Humble/Jazzy bridge. Root Apache-2.0 licence read. This supplies a separate simulator even while integrated simulation in xhumanoid_sdk remains on its roadmap.
-
TienKung 3.0 public SDK and inspected Apache-2.0 licence ↗
Open-X-Humanoid GitHub account · Accessed Nov 2, 2026
Current repository targets 3.0 onboard Ubuntu 24.04/ROS 2 Jazzy; Python 3.12 and C++17 bindings depend on vendor xos messages/services. Joint, force-position, perception, voice and optional hand interfaces. Multi-joint/full-body examples and integrated Gazebo/Isaac support remain roadmap items. Root Apache-2.0 licence read; not all robot software shares that licence.
-
UK distributor-claimed X-Humanoid assessment route ↗
The Robot Group · Accessed Nov 2, 2026
Seller describes itself as authorised UK distributor for TianGong 3.0 and Tianyi 2.0, with applications/evaluation planning open. Individual product pages explicitly condition availability/delivery on conformity and OEM confirmation. No OEM appointment contract, stock, parts inventory or repair SLA inspected.
-
UK TianGong 3.0 configuration and delivery conditions ↗
The Robot Group · Accessed Nov 2, 2026
Seller current 170 cm/64.5 kg/31 body-joint table agrees with current maker image. Lists at-least 2 h battery duration without operating conditions; not an exact scalar. UK enquiries open; actual delivery subject to conformity and manufacturer confirmation. Seller relationship is not signed EU conformity or general European repair coverage.
-
WiseKaiWu Agent guide and restrictive proprietary licence ↗
Open-X-Humanoid GitHub account · Accessed Nov 2, 2026
Guide uses Python 3.10 compiled binaries, Ubuntu 22.04/24.04, x 86_64/arm 64, HTTP/WebSocket/ROS channels and configurable model/tool services.3.0/Tianyi 2.5 speech path differs from legacy Tianyi 2.0 robot_voice. Root LICENSE explicitly requires prior written authorisation for commercial AND noncommercial use and restricts redistribution/modification; public visibility is not an unrestricted open-source licence. Full offline feature set and model-data processing remain configuration-specific.
-
X-Humanoid official portfolio and company introduction ↗
Beijing Humanoid Robot Innovation Center / X-Humanoid · Accessed Nov 2, 2026
Legal Chinese name 北京人形机器人创新中心有限公司. Founded November 2023 in Beijing; designated national-local embodied-intelligence innovation centre in October 2024. The designation does not establish a listed company, customer fleet size or a change in legal entity.
-
UK expressions of interest announcement ↗
Robotics and Automation News / The Robot Group · Published Oct 19, 2026 · Accessed Nov 2, 2026
October 19 report publishes UK enquiry/assessment route and distributor statements. Delivery dates vary by model/configuration and depend on applicable conformity. Treat as distribution announcement, not independent customer deployment or verified local stock.
-
Official website-only privacy policy ↗
Beijing Humanoid Robot Innovation Center / X-Humanoid · Published Aug 28, 2026 · Accessed Nov 2, 2026
PDF body says updated/effective August 28, 2026 despite filename 26. Explicitly covers the WEBSITE ONLY and excludes robot bodies/control systems, clients, apps, miniprograms and cloud services. Website forms, logs, Feishu and WeCom handling cannot establish robot telemetry residency or offline operation.
-
D-Robotics collaboration and planned second-half deliveries ↗
X-Humanoid / Beijing government · Published Jun 10, 2026 · Accessed Nov 2, 2026
June 8 collaboration update reprinted June 10 says Sunrise S 600 mass delivery is planned for H 2 2026. This is not proof of completed installation, current production BOM or a new marketed humanoid SKU. Current product compute is not replaced with the planned chip.
-
Mixed TienKung 3.0 and Ultra partner delivery ↗
Beijing Humanoid Robot Innovation Center / X-Humanoid · Published Mar 19, 2026 · Accessed Nov 2, 2026
Maker reports 15 TOTAL TienKung 3.0 and Ultra robots delivered March 19, 2026 to research/industry partners including Peking, BIT, Beihang, HKUST Guangzhou, Huazhong University, TUM, NIO and CSSC. Not 15 each; no per-recipient counts or independent acceptance. Ultra already existed in 2025, so this is not its initial release.
-
TienKung 3.0 February launch reporting ↗
Beijing Daily / Beijing government · Published Feb 11, 2026 · Accessed Nov 2, 2026
Beijing Daily reports February 10 debut with 169 cm/62 kg/43 full joints. One-metre barrier and kneeling demonstrations are controlled performance evidence. Current official matrix differs in mass/height and separates 31 body joints from optional hands.