Industrial Applications
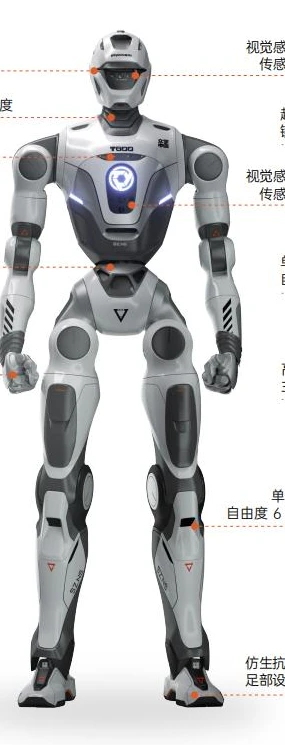
T800 is a 1730 mm family with Basic, Developer/Open Source, Pro and Max configurations. Public October manuals identify 25-body Developer and 29-body + 14-hand Pro, with different battery, mass and compute details from marketing. First batches and Luxshare applications are manufacturer reports without independently measured production duty.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Basic/Developer have 25 body motors and five-axis arms, no supported dexterous hand. Pro has 29 body + 14 hand = 43; Max 32 + 14 = 46. Seven-axis Pro hand is 740 g with five tactile sensors; marketing 5 kg is hand capacity, not rated arm/combined payload.
Exact retail and manual revisions differ: Basic NX 16 GB / no LiDAR; Developer English AGX + LiDAR versus Chinese Intel camera / no LiDAR and RK3588S base. October Developer/Pro manual instead Nezha four-core 8 GB + AGX 64 GB / 256 GB and Odin2 stereo + LiDAR / IMU, four microphones, two speakers. Freeze exact BOM.
SDK and Integration
Public native SDK, ROS2 community workspace and RL Lab provide C++/Python interfaces, MuJoCo and pinned Isaac Lab workflows. Native framework retains a precompiled scheduling core. BSD-3-Clause root licences do not establish that all firmware, motor drivers or AI weights are open. Exact targets: pm01_edu, t800 and t800pro; Basic retail T800 is excluded. Simulators must be isolated from physical robot discovery.
| API type | Native C++ plugins and ROS2 body/joint interfaces; edition entitlement required |
|---|---|
| Languages | C++, Python |
| ROS support | ROS2 Humble / Cyclone DDS with Ubuntu 22.04 in public community workspace; historical ROS Noetic controller is a separate stack |
| Simulation | MuJoCo joint-bridge / native Sim2Sim; Isaac Sim 5.1 and Isaac Lab 2.3.2 training in current RL repository |
| Offline operation | October 2026 privacy policy claims local robot data processing; all-feature offline execution and remote-service dependence require verification |
| Teleoperation | Needs verification |
| Software updates | Public support entry points exist; exact firmware compatibility, rollback and maintained lifetime unverified |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Use the exact hardware/controller/manual revision and contract. Family openness does not enable software-disabled retail editions. |
Safety Notes
Manufacturer warns of high-power drives and dangerous demonstrations. Establish a bounded test area, trained operator, suspension/support during development and validated stop/recovery procedures. No exact-model signed EU declaration, independent protective-stop performance or collaborative safety envelope inspected.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No exact-model signed declaration or independent certificate inspected. A listed integration standard is not product certification. |
| ISO 10218 review required | Unknown | International | No exact-model signed declaration or independent certificate inspected. A listed integration standard is not product certification. |
Commercial Readiness
| Pricing | December 2025 maker launch starts CNY 180000 for the range; exact current four-tier prices not verified. Previous USD 40500–80800 table unsupported by inspected current primary pages and removed. No current landed price or Thor-upgrade cost established. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China supplier inquiry, Overseas availability subject to configuration and contract |
| Spare parts | Overseas policy provides replacement-parts delivery; customs exceptions and local repair arrangements apply. No verified European spares warehouse or contracted turnaround. |
| Warranty | V2.0 policy lists 12 months for main unit/electronics/charger/controller, excluding consumables and unauthorised modifications. Battery and purchased edition scope require contract confirmation. Historical January 2025 PM01 FAQ instead gave Business 8 months / Education 12; do not silently replace an existing contract. |
| Configuration and pricing basis | Exact edition quotation required |
| Distributors and service | No exact-model manufacturer authorisation or stocked European repair capability verified. |
Specifications
| Height | 1730 mm |
|---|---|
| Weight | Unknown |
| Payload | Unknown |
| Runtime | Unknown |
| Battery and runtime conditions | Product table says lithium / 3–5 h and hero says solid-state / 4 h. October developer manual specifies 61.2 V / 20 Ah / 1.22 kWh ternary lithium, ~7.2 kg, quick removal, separate 2.5 h charge. Overview 2 h standard versus battery chapter ≥3 h general walking unresolved; no universal runtime scalar or unverified optional 40 Ah pack. |
| Degrees of freedom | Unknown |
| Max speed | Unknown |
| Configuration range | Basic/Developer 25 body, Pro 29+14=43, Max 32+14=46. Pro product neck 3 conflicts with manual neck 2 and body-total arithmetic. Source ↗ |
| Runtime and chemistry conflict | Solid-state / 4 h hero; lithium 3–5 h product table; October ternary 1.22 kWh manual 2 h overview versus ≥3 h walking. Exact revision unresolved. Source ↗ |
| Official edition price range | December 2025 launch from CNY 180000, exact current edition prices unknown. Prior USD 40500–80800 unsupported and removed. Source ↗ |
| Evidence level | May first batch and production capacity are maker claims. August Luxshare Suzhou loading/transport is maker-reported application; independent uptime unknown. Source ↗ |
| Maximum joint torque | 450 Nm peak leg-joint claim; not continuous arm torque, payload rating or safety limit. Source ↗ |
Sources and Further Reading
-
Current PM01 and T800 reinforcement-learning source ↗
ENGINEAI · Accessed Nov 2, 2026
README and LICENSE.txt read: BSD-3-Clause, Isaac Sim 5.1 / Isaac Lab 2.3.2 pinned base; Python whole-body-tracking / AMP, MuJoCo Sim2Sim and native SDK deployment. Targets PM01 EDU and T800; not all retail editions automatically developer-enabled. Older linked engineai_rl_workspace returns 404.
-
ENGINEAI overseas and mainland service policy V2.0 ↗
ENGINEAI · Accessed Nov 2, 2026
Main unit/electronics/charger/controller listed 12 months, consumables excluded and actual product contract governs. Mainland 7×12 remote and return repair; overseas remote + warranty parts shipping, customs exceptions and locally assessed repair. Onsite/training USD 500 per person/day plus travel subject to resources. No named EU centre/SLA. Trial/demo authorisations excluded; confirm applicability to each sale.
-
EngineAI ROS2 community workspace ↗
ENGINEAI · Accessed Nov 2, 2026
Current community branch README and BSD-3-Clause licence read. Ubuntu 22.04, ROS2 Humble / Cyclone DDS, C++11+ and Python3.10+, body velocity and joint interfaces, MuJoCo joint-bridge simulation. Warns isolate simulator from physical network; compatibility and exact firmware must be confirmed.
-
Native SDK source, licence and exact targets ↗
ENGINEAI · Accessed Nov 2, 2026
Main README / BSD-3-Clause licence / recursive tree opened. C++ plugin framework wraps precompiled scheduling core; Docker, x86_64 and aarch64, MuJoCo. Exact targets pm01_edu, t800, t800pro. Root licence does not make all controller/firmware source available. Stop existing motion service and suspend initially per manual; no robot commands executed.
-
T800 Chinese retail edition table ↗
ENGINEAI · Accessed Nov 2, 2026
Chinese current table lists Basic, Developer and Max, whereas English retains four including Pro. Developer corresponds to five-arm-DOF / 25-body development tier, but sensor and base-board BOM differs from October developer manual. Chinese RK3588S / no Developer LiDAR versus English eight-core / LiDAR and manual Nezha / Odin2 must be confirmed by serial configuration.
-
T800 English four-edition specifications ↗
ENGINEAI · Accessed Nov 2, 2026
Basic 25 DOF / NX / no developer access; Open Source 25 / AGX / developer access; Pro 29+14=43; Max 32+14=46. All 1730 mm, unspecified edition weights 75–85 kg. Pro neck listed 3 conflicts with 29-body arithmetic and manual neck 2. 5 kg refers to HAND, not arm payload. Hardware speed ≥2 m/s, lithium 3–5 h table conflicts with solid-state hero and developer manual.
-
ENGINEAI October 2026 privacy policy ↗
ENGINEAI · Published Oct 29, 2026 · Accessed Nov 2, 2026
October 29 update. Intro legal name includes 市; contact section omits 市, joint-stock form in both. Shenzhen Bay Innovation Technology Center T1 floor 69. Robot imagery/voice/location/decision data currently processed locally, not proactively uploaded per policy; account/contact/log data separate, China-collected personal data stored in China with affiliate sharing provisions. Not independent packet or security audit.
-
T800 developer and Pro hardware identity ↗
ENGINEAI · Published Oct 16, 2026 · Accessed Nov 2, 2026
Public October 16 guide distinguishes five-DOF-arm 25-body Developer and seven-DOF-arm 29-body + 14-hand Pro, both developer-enabled. Labelled component images visually inspected. This Developer is not software-disabled retail Basic.
-
T800 developer electrical and mechanical specifications ↗
ENGINEAI · Published Oct 16, 2026 · Accessed Nov 2, 2026
Developer 84.5 kg / Pro 85.3 kg including battery, both 1730 mm; Pro neck 2. Forward walking 0–1.5 m/s; running hardware <3 m/s, not certified maximum 3. AGX 64 GB, standard ternary lithium 1.22 kWh / 2 h / 2.5 h charge, 450 Nm peak, 20° slope / 200 mm step. No external supply or in-body charging.
-
T800 standard battery and handling ↗
ENGINEAI · Published Oct 16, 2026 · Accessed Nov 2, 2026
61.2 V nominal / 20 Ah / 1.22 kWh ternary lithium, about 7.2 kg, quick removal and separate 2.5 h charging only. Battery chapter ≥3 h general walking conflicts with overview 2 h standard and product 3–5 h. Charge limit 71.2 V vs overview charger 71.4 V: use exact approved charger/manual revision, not inferred nominal voltage.
-
Awaken architecture and Luxshare factory application ↗
ENGINEAI · Published Aug 21, 2026 · Accessed Nov 2, 2026
August 21 primary reports August WRC demos, edge whole-body VLA, five-layer Awaken architecture and first T800 loading / transport application at Luxshare Suzhou. Claimed >98% long-task success after 2 h tuning has no independent denominator or factory uptime; not general task guarantee. No customer-side Luxshare confirmation recovered.
-
T800 initial batch and Shenzhen manufacturing capacity ↗
ENGINEAI · Published May 22, 2026 · Accessed Nov 2, 2026
May 22 maker says first batch T800 rolled out; 12000 m² line, every 15 minutes and 10000-scale CAPACITY claims, not 10000 robots delivered. 2025 PM01 production described as hundreds. Exact event day and shipped count not independently established.
-
T800 launch announcement and four commercial tiers ↗
ENGINEAI · Published Dec 8, 2025 · Accessed Nov 2, 2026
December 8 posting; primary chronology names December 2, 2025 launch. Starting CNY 180000, with Basic / Eco (Open Source) / Pro / Max. No current USD edition checkout prices established; prior USD 40500–80800 removed as unsupported. Production rhetoric is manufacturer positioning, not independently measured delivery.