Industrial Applications
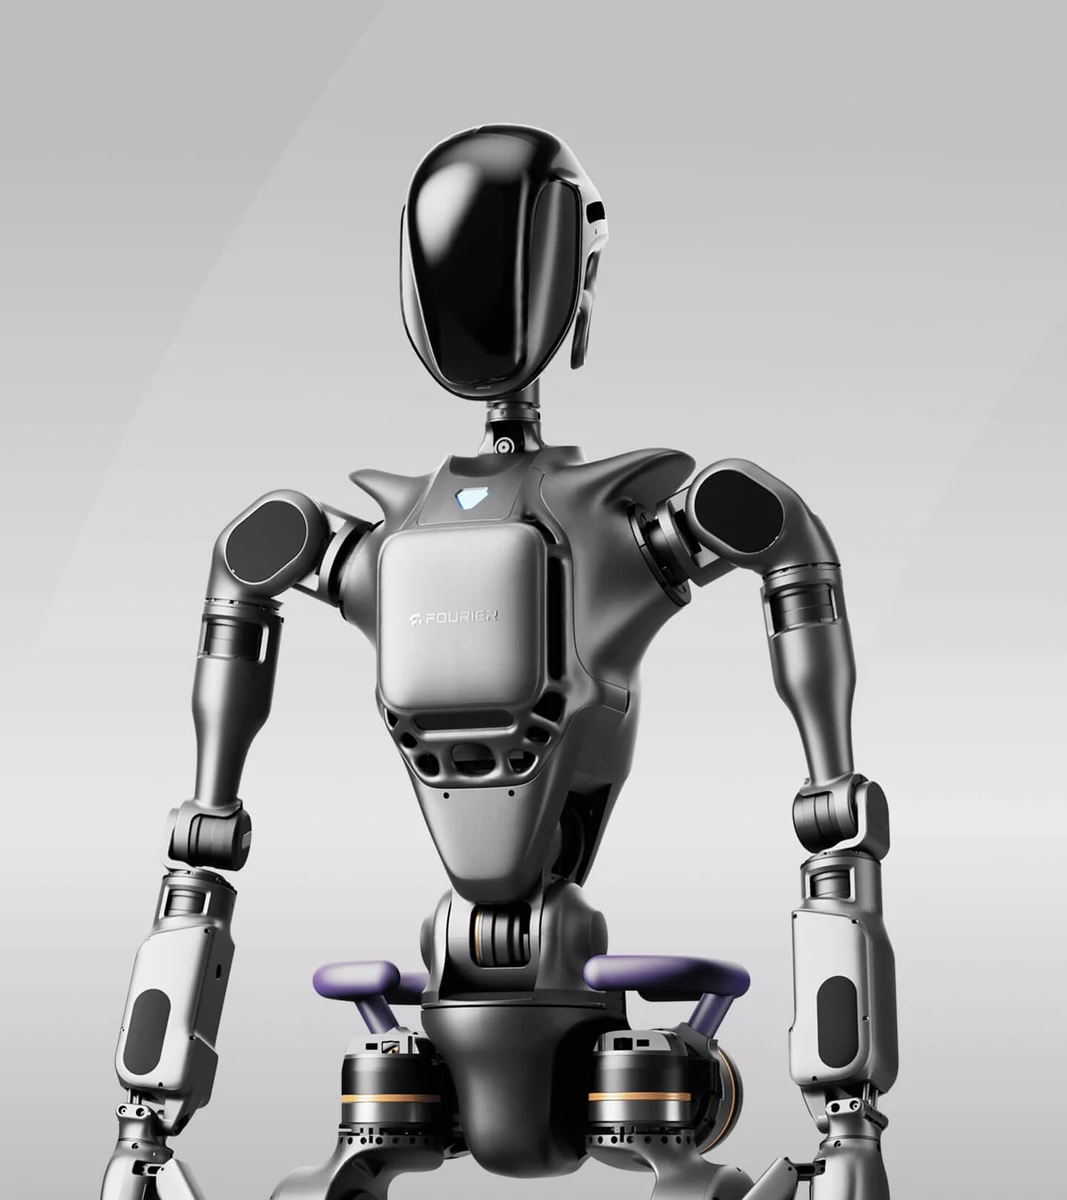
Editorial assessment: GR-1 is a full-size manipulation and locomotion research platform. NVIDIA’s GR00T N1 paper reports real-robot bimanual experiments on GR-1; this supports research use, not a commercially validated production task. Gripper, hand and Pro editions have different configuration details.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Seven-joint arms; about 3 kg single-hand payload. GR-1L gripper and GR-1 dexterous-hand configurations differ, including Pro editions.
Legacy manual lists RealSense depth camera and IMU. Camera counts vary within documentation; verify configured sensors.
SDK and Integration
Official Aurora SDK publishes Python examples and MuJoCo tools. Match robot edition and actuator firmware to the supported release.
| API type | needs_verification |
|---|---|
| Languages | Python |
| ROS support | Legacy GR-1 manual lists Ubuntu 20.04 + ROS 2; exact distribution and firmware unverified. |
| Simulation | needs_verification |
| Offline operation | Local control interfaces exist; complete application cloud dependence unverified. |
| Teleoperation | Model-specific controller and teleoperation procedures documented; verify supplied edition. |
| Software updates | Aurora requires compatible actuator communication/driver firmware; obtain supported release and rollback procedure. |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Compared with GR-2, GR-1 appears less compelling for new factory pilots because GR-2 publicly lists stronger dexterity, upgraded SDK access, and explicit support for Isaac Lab, ROS, and MuJoCo. |
Aurora v1.3.0 explicitly supports GR-1P, GR-2, GR-3 and N1. Do not generalize compatibility to every historical GR-1 edition.
Safety Notes
No public collaborative safety certification was verified in this record. Use guarded pilots and integrator-led risk assessment.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No verified public CE certificate or EU Declaration of Conformity was captured for GR-1 in this record. |
| EU Machinery Regulation / Machinery Directive review | Requires buyer review | European Union | Factory deployment requires application-specific risk assessment and integration validation. |
| ISO 10218 review required | Requires buyer review | International / European Union | GR-1 should be treated as a humanoid research/developer platform until robot-cell safety is proven by supplier and integrator documentation. |
Commercial Readiness
| Pricing | No verified public exact-configuration price. Contact supplier for a dated quotation. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | International enquiry; exact destination and delivery unverified |
| Spare parts | Confirm whether GR-1 remains a priority support platform compared with GR-2, and verify spare-parts availability before buying. |
| Warranty | Exact-model warranty period, exclusions and local repair obligations unverified. |
| Configuration and pricing basis | Contact sales / request quote |
| Distributors and service | No exact-model EU distributor or installation SLA verified. |
Current stock, final configured quote and binding delivery date must be obtained from the supplier.
Specifications
| Height | 1650 mm |
|---|---|
| Weight | Unknown |
| Payload | 3.00 kg |
| Runtime | Unknown |
| Battery and runtime conditions | Legacy manual: 483 Wh, approximately 60 min general operation / 45 min walking. Historical brochure: 460 Wh. Manual also contains an inconsistent 112.3 Wh row; confirm pack label and revision. |
| Degrees of freedom | Unknown |
| Max speed | Unknown |
| Max peak torque | 230 N.m Source ↗ |
| Locomotion | Bipedal humanoid Source ↗ |
| Height | 1650 mm Source ↗ |
| Weight | Unknown: legacy manual ≈52 kg; historical brochure ≈55 kg, Pro ≈60 kg. Source ↗ |
| Revision differences | Manual: 1650 × 524 × 325 mm; historical brochure: 1650 × 515 × 320 mm. Do not combine dimensions across revisions. Source ↗ |
| Joints / degrees of freedom | 34 / 44 by gripper or dexterous-hand configuration; verify revision. Source ↗ |
| Walking speed | 5 km/h Source ↗ |
| Vision sensor | 1 RealSense camera Source ↗ |
| Pure vision perception | Fourier describes a BEV, Transformer, and Occupancy Network approach using six RGB cameras for real-time 3D occupancy-grid perception Source ↗ |
Sources and Further Reading
-
European Commission machinery legislation overview (context only) ↗
European Commission · Accessed Nov 2, 2026
Current Commission overview opened November 2, 2026: Machinery Directive and Regulation 2023/1230 transition; overview gives January 20, 2027 mandatory application of the Regulation. General context, not a model declaration or legal determination for a specific installation. EUR-Lex pages returned a verification challenge, so this readable primary Commission overview is cited instead.
-
Fourier Aurora SDK official repository ↗
Fourier Robotics · Accessed Nov 1, 2026
v1.3.0 lists GR-1P, GR-2, GR-3 and N1; Python examples, Chinese/English docs and MuJoCo tools. Firmware minimums apply; do not infer all historical GR-1 configurations are supported.
-
Historical GR-1 / GR-1L / Pro variant brochure ↗
Fourier Robotics · Accessed Nov 1, 2026
Cached primary PDF inspected: GR-1L and GR-1L Pro gripper variants 34 actuators; GR-1 and GR-1 Pro dexterous-hand variants 44. All list 3 kg single-hand load; mass differs 55/60 kg. Live URL now returns site HTML; use legacy manual for accessible documentation.
-
ISO 10218-2:2025 integration scope (context only) ↗
ISO · Accessed Nov 2, 2026
Current publisher abstract/catalogue opened November 2, 2026. Part 2 covers industrial robot applications and cells, with application exclusions. Full paid standard not acquired. Context only; does not certify this robot or prove that industrial-cell provisions alone cover public-service use and mobile hazards.
-
关于GR-1 — official legacy developer manual ↗
Fourier Robotics · Accessed Nov 1, 2026
Manufacturer manual: 1650 × 524 × 325 mm, about 52 kg, 34/44 actuators, 3 kg single-hand load. Historical brochure differs in dimensions, mass and pack capacity; exact revision must be confirmed.
-
GR00T N1: An Open Foundation Model for Generalist Humanoid Robots ↗
NVIDIA and collaborating research authors · Published Mar 18, 2025 · Accessed Nov 1, 2026
Primary research reports language-conditioned bimanual manipulation experiments using Fourier GR-1. Research result, not commercial factory deployment or a general task guarantee.