Industrial Applications
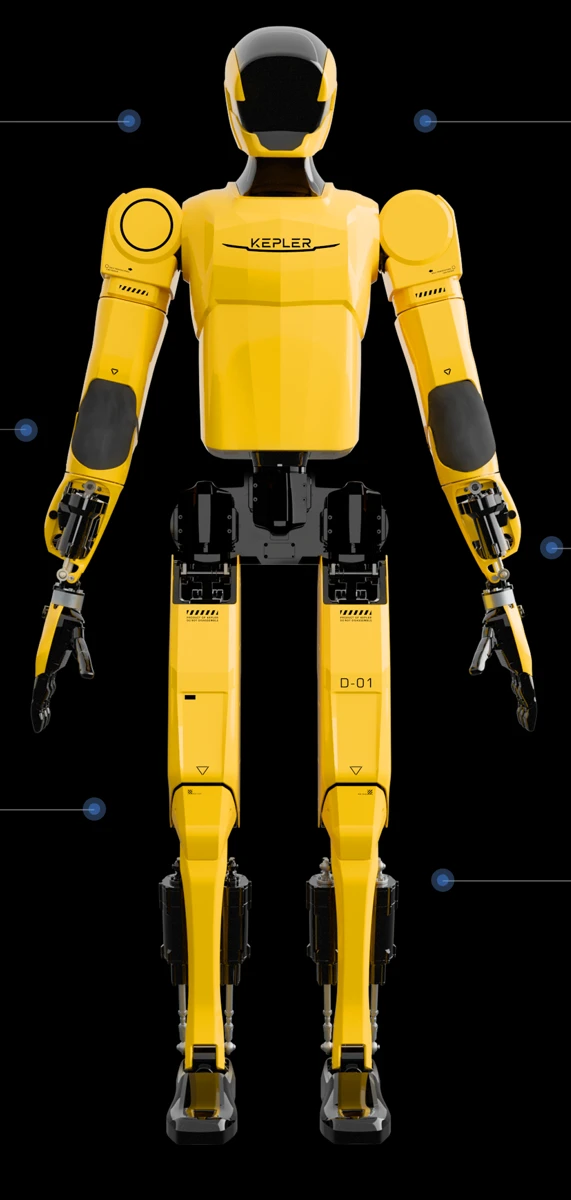
K2 Bumblebee / Forerunner K2 is the established industrial family preceding K3. Basic and developer versions differ in hands, DOF and API access. Manufacturer-reported small-series production and customer trials do not establish independently measured fleet throughput. Height, battery and speed sources describe conflicting revisions.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
Current family advertises 25–30 kg combined handling; June 2025 release specifies 15 kg per arm/30 kg combined. V2.1 distinguishes 30 kg held-object versus 20 kg grasp weight with unclear scope; do not treat 20 kg as per-arm rating. Developer 52 total DOF=30 body + 22 hand, with 6 active motors and 11 active/passive joints per hand. Basic 30 DOF omits dexterous hands. Actuator 8200 N/220 Nm and cable 1200 N are component figures, not arm payload.
V2.1: Intel i5/256 GB plus Orin NX 16 GB/128 GB 100 TOPS, Xsens MTi-320, RGB-D camera, four microphones and stereo speakers; laserSLAM optional. Gemini335 appears in actual tabletop example. Older brochure 4 force sensors vs developer matrix 2; older fingertip 96 contacts vs current API 25 per finger. Basic carousel 100 TOPS vs matrixGPU absent; delivered equipment and revision require confirmation.
SDK and Integration
K2 developer configurations have public C++ motor and Python/C++ ROS2 examples; Basic table omits development access. See programming section for permissions and version limits.
| API type | K2 MotorApi plus ROS2 perception, planning and application examples |
|---|---|
| Languages | C++, Python |
| ROS support | Public tabletop example uses ROS2 Humble on Ubuntu 22.04; motor core API uses ROS2 JointState/Eigen. |
| Simulation | Manufacturer demonstrated Isaac Gym and MuJoCo at IROS2 025; exact downloadable robot/controller package and licence not established. |
| Offline operation | Local ROS2 and motor execution documented; cloud model/speech dependencies and full offline feature entitlement unverified. |
| Teleoperation | Specification names VR/motion-capture; remote controller optional. Exact delivered hardware requires quotation. |
| Software updates | OTA claimed; exact update signing, approval, rollback and maintained firmware compatibility matrix unverified. |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | K2 developer access is configuration-specific; Basic matrix omits secondary development. Public examples reference an SSH GitLab source repository; anonymous availability and full-stack redistribution licence not verified. |
Safety Notes
K2 startup guide requires lifting frame at least 180 cm high for startup/shutdown/reset, arm support before poweroff and suspended recovery after emergency stop. Charger use requires powered-off robot and original charger. V2.1 references GB/T41527 and an internal IP40 test; not a signed certification or water protection guarantee.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No signed exact-model declaration or independent certificate inspected; listed framework is not evidence of certification. |
| EU AI Act | Unknown | European Union | No signed exact-model declaration or independent certificate inspected; listed framework is not evidence of certification. |
| EU Machinery review | Unknown | European Union | No signed exact-model declaration or independent certificate inspected; listed framework is not evidence of certification. |
| IEC 62443 | Unknown | International | No signed exact-model declaration or independent certificate inspected; listed framework is not evidence of certification. |
| ISO 10218 | Unknown | International / Europe | No signed exact-model declaration or independent certificate inspected; listed framework is not evidence of certification. |
| ISO/TS 15066 | Unknown | International / Europe | No signed exact-model declaration or independent certificate inspected; listed framework is not evidence of certification. |
Video Evidence
Commercial Readiness
| Pricing | June 3, 2025 maker release givesUSD 30000 base-model headline, without a matching current Basic/developer bundle. EnduX opened UK regional table on Nov 2, 2026 showsGBP 71760 K2/GBP 79560 K2-W; indexed USD values vary by locale. Shipping, tax, equipment and current export price need written quotation. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China by manufacturer inquiry, International configuration/export acceptance must be confirmed |
| Spare parts | No exact parts-stock location, inventory or repair turnaround verified. Public developer Repair Manual section returned no content. |
| Warranty | Current K2 table: Basic 8 months, biped/wheeled developer 12 months; developer onsite service and training optional. Exact region, industrial duty, battery exclusions, return freight and post-acquisition warrantor require contract. Historical and K3/K3W terms unverified. |
| Configuration and pricing basis | Exact configuration and regional quotation required |
| Distributors and service | RBTX and UK EnduX list K2; no automatic K3 or historical variant supply entitlement. |
Indicative listing and event appearance are not proof of exact stock or contract delivery.
Specifications
| Height | Unknown |
|---|---|
| Weight | 75.00 kg |
| Payload | 30.00 kg |
| Runtime | 480 min |
| Battery and runtime conditions | V2.1 engineering specification: 51.8 V/30 Ah (nominal 1.554 kWh calculated), charger 220–240 V, max 1200 W/20 A.2024 launch/RBTX give 2.33 kWh. Family advertises 1 h charge/8 h; EnduX lists 2 h charge. Eight hours is a specific-scenario manufacturer test, without published duty/load details. Revision and state-of-charge window unresolved; no single battery/charge scalar adopted. |
| Degrees of freedom | Unknown |
| Max speed | Unknown |
| Actuator architecture | Hybrid roller-screw and rotary actuation; component 8000/8200 N and 200/220 Nm differ by document/actuator, not robot load. Source ↗ |
| Locomotion | Biped family; wheeled developer configuration has its own stable record. Source ↗ |
| Whole-body degrees of freedom | Basic 30; developer 52 including 22 hand joints.52 does not mean 52 independently driven motors. Source ↗ |
| Onboard compute | Developer matrix 100 TOPS; comparison panel 275 TOPS andBasic carousel/matrix conflict. V2.1 Intel i5+Orin NX; EnduX i7+NX. Source ↗ |
| Connectivity | V2.1 EtherCAT internal bus and rear Ethernet; WiFi debugging. EnduX listsWiFi6/Bluetooth5.2/5G; exact revision options need quotation. Source ↗ |
| Height | Marketing 1750 mm; V2.1 engineering 1720 mm. Exact hardware revision unresolved; scalar unknown. Source ↗ |
| Weight | 75 kg for biped family and both named biped configurations; wheeled developer 135 kg with chassis. Source ↗ |
| Dexterous hand | Developer 11 active/passive DOF per hand, 6 driven motors each; Basic table omits dexterous hands. Source ↗ |
| Fingertip contact points | 2024 release 96 contacts/fingertip; current MotorApi array 2×5×25 and 2025 brochure 25/finger. Current configuration must be identified. Source ↗ |
| Movement speed | V2.1 walking 3.5 km/h (~0.97 m/s); EnduX 1 m/s, RBTX 1.1 m/s. No common maximum test established. Source ↗ |
| Maximum dual-arm payload | 30 kg combined in V2.1/2025 release; marketing 25–30 kg. Reach, pose and duty-cycle limits not published. Source ↗ |
| Single-hand load capacity | 2024 single-hand 15 kg; 2025 per-arm 15 kg; V2.1 grasp 20 kg scope unclear. Do not equate hand static load with arm rating. Source ↗ |
| Battery capacity | V2.1: 51.8 V/30 Ah=1.554 kWh nominal calculated; 2024/RBTX: 2.33 kWh. Revision unresolved. Source ↗ |
| Claimed operating time | 8 hours manufacturer-specific-scenario test; June 2025 wording up to 8 h. Load, walking fraction and intervention rate unknown. Source ↗ |
| Claimed charge time | Maker 1 h versusEnduX 2 h; state-of-charge window and exact pack revision unverified. Source ↗ |
| Sensor stack | RGB-D, four microphones, stereo speakers, IMU and force/tactile sensing. LaserSLAM optional; brochure 4 versus matrix 2 force sensors. Source ↗ |
Sources and Further Reading
-
EnduX K2 and K2-W European-market listing ↗
EnduX · Accessed Nov 2, 2026
UK seller offers K2/K2-W; GBP 71760/79560 in opened regional page, while indexed USD 92000/102000 varies locale. In-stock/four-week claims are seller statements. Table 1720 mm, 75/135 kg, 30 kg total, 1 m/s, 51.8 V 30 Ah, 2 h charge, ROS2, Orin NX 100 TOPS. Height/charge/speed differ from marketing. Exact tax/shipping and EU service/stock not verified.
-
European Commission AI Act overview (context only) ↗
European Commission · Accessed Nov 2, 2026
Current Commission overview opened November 2, 2026. General risk-based AI policy context only; no exact robot classification, current implementation obligation, approved model or certified safety function inferred from this page.
-
European Commission machinery legislation overview (context only) ↗
European Commission · Accessed Nov 2, 2026
Current Commission overview opened November 2, 2026: Machinery Directive and Regulation 2023/1230 transition; overview gives January 20, 2027 mandatory application of the Regulation. General context, not a model declaration or legal determination for a specific installation. EUR-Lex pages returned a verification challenge, so this readable primary Commission overview is cited instead.
-
ISO 10218-2:2025 integration scope (context only) ↗
ISO · Accessed Nov 2, 2026
Current publisher abstract/catalogue opened November 2, 2026. Part 2 covers industrial robot applications and cells, with application exclusions. Full paid standard not acquired. Context only; does not certify this robot or prove that industrial-cell provisions alone cover public-service use and mobile hazards.
-
K2 configuration matrix: Basic, Bipedal Development, Wheeled Development ↗
Kepler Robotics · Accessed Nov 2, 2026
Rendered English matrix: Basic 30 DOF/75 kg; biped developer 52/75 kg; wheeled developer 52/135 kg; all 1750 mm. Basic lacks dexterous hands, six-axis force and development access; developer versions have hands, two force sensors and 100 TOPS. Basic carousel nevertheless says 100 TOPS: conflict retained. Warranty 8/12/12 months; indicative delivery 90 days; onsite service/training optional for developer versions. Larger wheeled carousel render matches correct chassis; tiny thumbnail avoided.
-
Kepler developer platform ↗
Kepler Robotics · Accessed Nov 2, 2026
Public developer landing page rendered without login. Nebula microkernel, visual Kepler Studio workflows, digital twin and sim-to-real are manufacturer claims; public source licence for complete robot stack not established.
-
Kepler K2 brochure ↗
EnduX / Hannover Messe exhibitor material · Accessed Nov 2, 2026
Both image-only pages visually inspected. EnduX distributor brochure gives 1750 mm/75 kg/52 DOF/100 TOPS, 25–30 kg combined, 1 h/8 h, 25 tactile points/finger. Distributor-authored, not a safety certificate or generic SKU entitlement.
-
KEPLER K2 | Humanoid Robot | 52 DOF ↗
RBTX / igus · Accessed Nov 2, 2026
European marketplace lists K2, 1750 mm/75 kg/52 DOF, 30 kg combined, 1.1 m/s, 2.33 kWh/8 h and usual 3-week lead. Stock/contract/certification not independently verified; configuration differs from current V2.1 manual.
-
Kepler K2 manufacturer exhibitor brochure ↗
Kepler / World Robot Conference · Accessed Nov 2, 2026
Complete brochure read, including image/table pages: 1750 mm/75 kg/52 DOF/100 TOPS; 25–30 kg combined and 15 kg single-hand; 1 h charge/8 h claim. Names IND, SPE, EDU series with no exact SKU mapping; EDU promises API/Sim2Real. 25 tactile points/finger and 4 force sensors differ from other sources. Component 8000/8200 N and 200/220 Nm are separate ratings, not robot payload.
-
K2 motor and force/tactile APIs ↗
Kepler Robotics · Published Apr 13, 2026 · Accessed Nov 2, 2026
Open Interfaces > Motor API updated April 13. C++ MotorApi supports degree/radian commands, position/torque modes, 14 arm joints, 12 finger motors, 2×5×25 tactile samples and 12 wrist force/torque channels. Core interface uses ROS2 JointState and Eigen. Not a safety-rated control interface or proof all passive DOF are independently actuated.
-
K2 tabletop grasping development example ↗
Kepler Robotics · Published Mar 30, 2026 · Accessed Nov 2, 2026
Development Cases > Tabletop Grasping updated March 30. Ubuntu 22.04/ROS2 Humble, Python/C++, RGB-D Orbbec Gemini335, hand-eye calibration, TensorRT and LangGraph/ROS2 example. Installation references SSH GitLab repository; anonymous source access and redistribution licence not established. Some embedded figures unavailable outside Feishu.
-
K2 debugging and network connection guide ↗
Kepler Robotics · Published Mar 22, 2026 · Accessed Nov 2, 2026
Quick Start > Debugging, updated March 22. Ubuntu PC via rear Ethernet or supplied WiFi; published default WiFi credentials require replacement and network isolation. Credentials not copied into catalog. No signed-update/rollback or robot-wide data residency guarantee established.
-
K2 product specification V2.1 ↗
Kepler Robotics · Published Mar 18, 2026 · Accessed Nov 2, 2026
Product Introduction > About K2, updated March 18. Gives 1720×568×335 mm, 75 kg, 52 DOF including 22 hand joints, 51.8 V/30 Ah, 8 h specific-scenario test, walking 3.5 km/h, 30 kg held-object load and 20 kg grasp weight with unclear per-hand scope. Contradicts 1750 mm/2.33 kWh marketing. Lists IP40 internal test and GB/T41527 references, without an inspected certificate. CPU Intel i5 differs from EnduX i7 listing.
-
Kepler K2 developer ecosystem at IROS2025 ↗
Kepler / PR Newswire · Published Oct 27, 2025 · Accessed Nov 2, 2026
Manufacturer describes Motor API, vision/navigation/voice modules, Nebula microkernel, Kepler Studio and Isaac Gym/MuJoCo demonstrations. Future skill marketplace is not currently delivered entitlement. Full stack openness is a claim without a public complete source licence inspected.
-
Keli Sensing investee profile ↗
Keli Sensing · Published Jun 9, 2025 · Accessed Nov 2, 2026
Investor primary page confirms incorporation Aug 15, 2023, former legal name, Pre-A Apr 23, 2025 and separate K1/K2/S1/D1 names. K2 first publicly shown Oct 14, 2024 at GITEX. Actuator 8000 N is not robot payload.
-
Kepler K2 Bumblebee Debuts at ICRA 2025 ↗
Shanghai Kepler Robot Co., Ltd. via PR Newswire · Published Jun 3, 2025 · Accessed Nov 2, 2026
Maker June 3 release reports 1750 mm/75 kg/52 DOF/100 TOPS, 15 kg per arm/30 combined, up to 8 h after 1 h charge, 25 tactile points/finger. USD 30000 base-model headline and 1.5-worker equivalence are manufacturer claims; exact Basic/developer bundle and export price not established. Limited-series production and real-world trials are claimed.
-
Kepler Debuts Forerunner K2 Humanoid Robot, Accelerating Commercial Deployment ↗
Shanghai Kepler Robot Co., Ltd. via PR Newswire · Published Oct 21, 2024 · Accessed Nov 2, 2026
Maker launch: 52 total DOF, 11 active/passive per hand, 15 kg single-HAND load, 96 fingertip contact points and 2.33 kWh/8 h. Customer-environment testing and small-batch plans; not independent production verification. Later tactile/battery configurations differ. Retrospective K1 statement also names November 2023 release,25 kg unspecified payload and 8 h claimed battery life;not a per-arm definition or current support commitment.