Industrial Applications
Editorial: wheeled, lifting dual-arm platform for supervised service, teleoperation and navigation research. Current 44-joint table and Python ROS 2 SDK support technical integration; combined 10 kg maximum load, unknown exact endurance and unverified scene acceptance limit production claims. CES/mall demos are not unattended factory fleet evidence.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
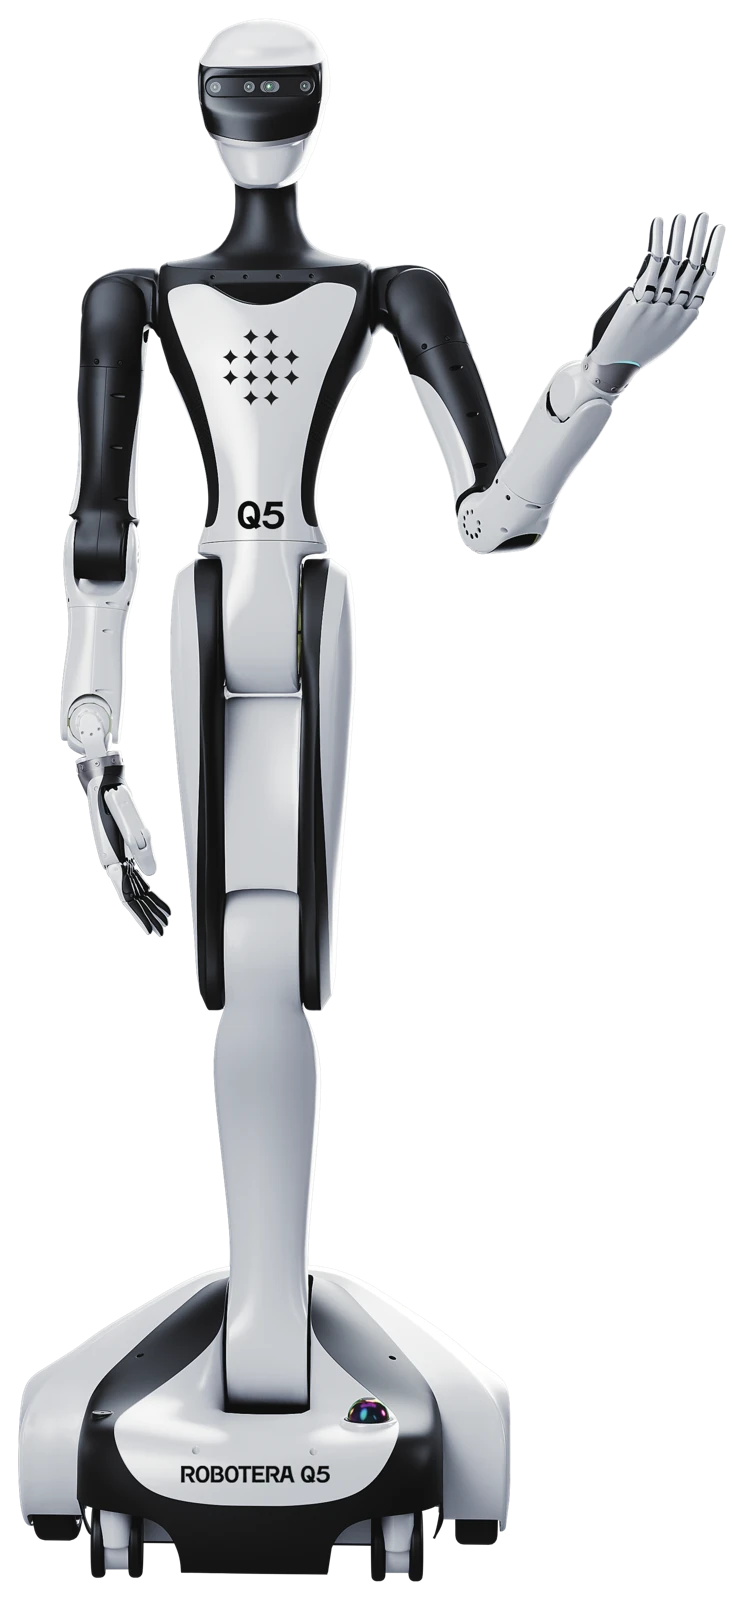
Core 10 kg is MAXIMUM COMBINED DUAL-ARM load, not 10 kg each arm. Separate 10 kg XHAND1 Lite hand component claim is not an arm load rating. 44 full joints=head 2, arms 14, hands 22, waist 1, lifting leg 3, chassis 2.1380 mm armspan; 0–2 m reach envelope includes lift, not 2 m arm reach.
Maker 3 D LiDAR fused with depth/stereo vision, screen, microphones and speech/navigation applications. Small chassis 582×519×225 mm; standing overall 582×519×1650 mm. Seven-joint arms and 11-joint hands per side support service interaction and teleoperation; exact compute board, mapping build and speech/cloud providers unverified.
SDK and Integration
Python joint/trajectory, MPC, hand and mobile-base control; VR /glove teleoperation. Manufacturer SDK explicitly supports Q5, ROS2 Humble/ CycloneDDS and supplied developer environment. Maker promotes data/teleop-to-training-to-simulation workflow; no exact public Q5 physics simulator or validated sim-to-real package inspected. Public repository rights are separate from firmware, model weights, commercial software and data. Match exact hardware, messages and supported firmware; not an independent safety controller.
| API type | Python joint/trajectory, MPC, hand and mobile-base control; VR /glove teleoperation |
|---|---|
| Languages | Python ROS2 SDK |
| ROS support | Manufacturer SDK explicitly supports Q5, ROS2 Humble/ CycloneDDS and supplied developer environment |
| Simulation | Maker promotes data/teleop-to-training-to-simulation workflow; no exact public Q5 physics simulator or validated sim-to-real package inspected |
| Offline operation | Complete motion, speech, AI, remote-support and telemetry offline scope unverified |
| Teleoperation | Exact delivered package, licence and supervision requirements must match order |
| Software updates | Firmware signing, patch support lifetime and rollback unverified |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Public repository rights are separate from firmware, model weights, commercial software and data. Match exact hardware, messages and supported firmware; not an independent safety controller. |
No complete current whole-body hardware safety/warranty manual inspected. Component documentation and public source presence do not establish all product rights.
Safety Notes
No exact signed EU conformity dossier, independent stopping/fall envelope, safety-integrity rating or validated human-collaboration mode inspected. High joint torque, speed or hand load are not safe collaboration evidence. Follow delivered manual, physical test protection and system-level integration assessment; public ROS services are not a certified stop system.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No exact-model signed declaration and complete delivered configuration dossier inspected. For L7 / M7 / Q5, European seller promises a declaration; promise is not independent verification. |
Commercial Readiness
| Pricing | November 2, 2026 access: seller Robot Distribution advertises from EUR 66,690 ex VAT, or from EUR 2,269/month RaaS. Manufacturer list price not verified; exact hand/compute/software, freight, installation, contract term and availability by written quote. Starting price and monthly service fee are different acquisition modes. |
|---|---|
| Price range | 66690.00 EUR |
| Lead time | Needs verification |
| Availability regions | China manufacturer inquiry, Europe: Robot Distribution lists on order, purchase/rental/ RaaS |
| Spare parts | No independently inspected local inventory or repair response SLA. |
| Warranty | Exact whole-robot, battery, hand and regional warranty period/exclusions unverified. Public software/component licences are not hardware warranties. |
| Configuration and pricing basis | Seller advertised starting purchase price; ex VAT; exact quote required |
| Distributors and service | Robot Distribution seller claims European stock, parts/repair/training and supplied EU declaration. Actual OEM appointment, signed declaration, stock and service SLA not inspected. |
No public exhibition, company order book or aggregate component count treated as delivered robot fleet.
Specifications
| Height | 1650 mm |
|---|---|
| Weight | 70.00 kg |
| Payload | 10.00 kg |
| Runtime | Unknown |
| Battery and runtime conditions | Official 60 V electrical system; OVER 4 h full-load endurance is a lower-bound claim, not exact 240 minutes. Amp-hour capacity, charging speed, swap continuity and mass inclusion not verified. |
| Degrees of freedom | 44 |
| Max speed | Unknown |
| Loaded endurance | OVER 4 h manufacturer claim; load/cycle/temperature protocol not provided. Exact runtime scalar unknown. Source ↗ |
| Catalog status | Current maker product; official June 19, 2025 launch entry. Public current table and brochure distinguish dual-arm max load from hand component load. Source ↗ |
| Payload definition | 10 kg MAXIMUM COMBINED DUAL-ARM load. Not 10 kg per arm; hand component capacity is a different rating. Source ↗ |
Sources and Further Reading
-
Current Q5 wheeled/lifting service platform matrix ↗
ROBOTERA · Accessed Nov 2, 2026
Maker: standing 582×519×1650 mm, 70 kg, 44 full joints; 7-joint arms and 11-joint XHAND1 Lite hands. Maximum 10 kg is COMBINED DUAL-ARM load; separate 10 kg hand-component load is not per-arm payload. 1380 mm armspan, 0–2 m reachable envelope, 3 D LiDAR /depth vision, 60 V, OVER 4 h full-load endurance. Runtime lower bound is not an exact scalar. VR /glove full-body teleoperation and navigation are maker capabilities.
-
Current RobotEra company, legal name and portfolio ↗
ROBOTERA · Accessed Nov 2, 2026
Rendered current official application, not the empty static HTML. Founded August 2023 by Chen Jianyu; company claims Tsinghua university shareholding. Footer now says 北京星动纪元科技股份有限公司. Current contact address: 7 F, VIA Building, Tsinghua Science Park, Haidian, Beijing. Current complete cap table and formally registered English legal name unverified. Product routes include L7, Q5, M7 and XHAND end-effectors; /product/Lite and /product/PRO are HANDS, not new humanoid bodies.
-
European seller catalogue, conditional procurement and service claims ↗
Robot Distribution / Lammar Innovative, Tourcoing France · Accessed Nov 2, 2026
Seller current page updated October 22 lists L7 / M7 / Q5 on order, from EUR 105990/105990/66690 ex VAT; RaaS from 3599/3599/2269 per month. Claims EU declaration, European stock, parts/repair/training and rental. No signed exact-model declaration, warehouse inventory, OEM appointment or SLA independently inspected. Written quote and exact configuration govern; ap rice/claim is not validation of compliance.
-
Official dated product and funding announcement catalogue ↗
ROBOTERA · Accessed Nov 2, 2026
Public GET catalogue read after browser initially showed placeholders. Original dated entries: L7 launch July 22, 2025; Q5 debut June 19, 2025; A-round announcement July 7, 2025; A+ near CNY 1 billion announcement November 20, 2025; SF-led above USD 200 million announcement April 27, 2026. Entries link maker We Chat articles; catalogue dates are source publication evidence, not guaranteed first customer delivery. November 2, 2026 DHL / CIIE entry is event cooperation/preview, not independent installed-fleet evidence.
-
Official Q5 Chinese/English brochure ↗
ROBOTERA · Accessed Nov 2, 2026
Both Chinese and English manufacturer PDFs were opened; numerals with broken font extraction were read visually. Q5 confirms 44 joints, 70 kg, standing 582×519×1650 mm, 10 kg MAXIMUM dual-arm load, 0–2 m reach and OVER 4 h full-load runtime. This does not mean 10 kg per arm or exact 240 min. Download-centre timestamp May 1, 2025 is earlier than documented L7 launch and is not treated as the model release or independently verified PDF revision date.
-
Public ROS2 Python control API and exact model list ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
Root README and full file index inspected. Python ROS2 Humble/ CycloneDDS inside supplied developer environment, using teleop_client message definitions. Explicit Q5, L3, L7 model selector; initial is at ion, trajectory, MPC / ServoPose, hand and base interfaces. No root licence file exists in inspected tree; public visibility does not grant unrestricted reuse. Internal L3 identifier has no inspected retail hardware mapping; not invented as a new SKU.
-
Public teleoperation message dependencies ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
README identifies custom xbot_msgs ROS2 messages and service package used by Python SDK. Installed message/firmware match matters. No root licence retrieved; not a verified full commercial teleoperation entitlement or standalone safety controller.
-
L7 / Q5 demonstrations and scoped CES claims ↗
ROBOTERA / PRNewswire · Published Jan 8, 2026 · Accessed Nov 2, 2026
Maker CES release: L7 171 cm/70 kg without mass scope/55 full joints/20 kg dual-arm load, full-body teleoperation; Q5 44 joints, visitor interaction and squat object pickup. Current L7 brochure instead 65 kg EX hands; do not assume exactly 5 kg hand mass. Hexa-Core refers to six qualities, not six robot bodies. More-than 600 aggregate products delivered is not 600 L7s.