Commercial Context
Robot Distribution in Tourcoing advertises European stock, EU declarations, repair/parts/training and purchase/rental/ RaaS for L7 / M7 / Q5. These are seller statements; no exact signed declaration, OEM appointment, warehouse evidence or service SLA inspected. RBTX/igus provides another listed sales route but its corporate German address is not a verified RobotEra repair centre. Maker exhibition activity and overseas hand sales do not establish a European humanoid installed fleet.
Product Focus
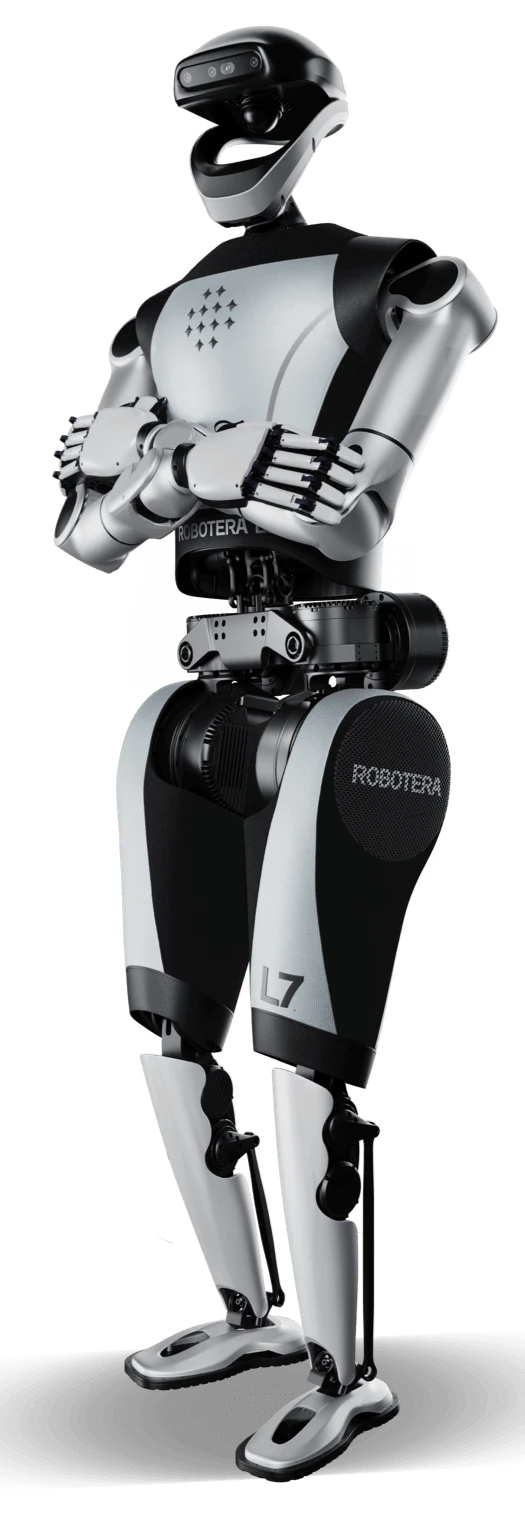
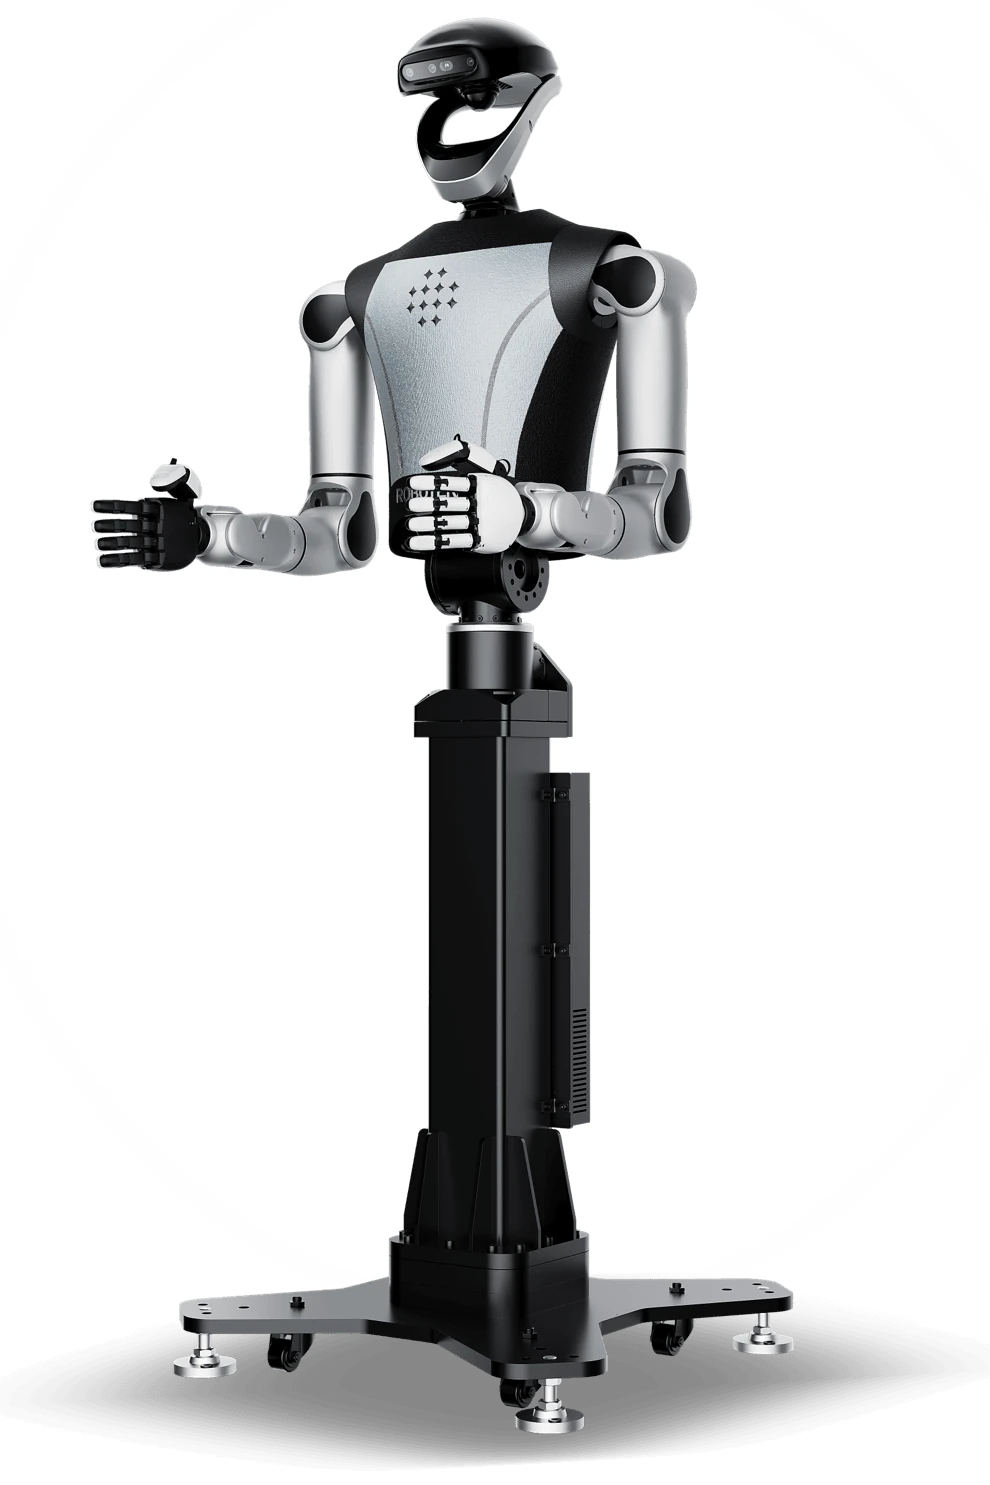
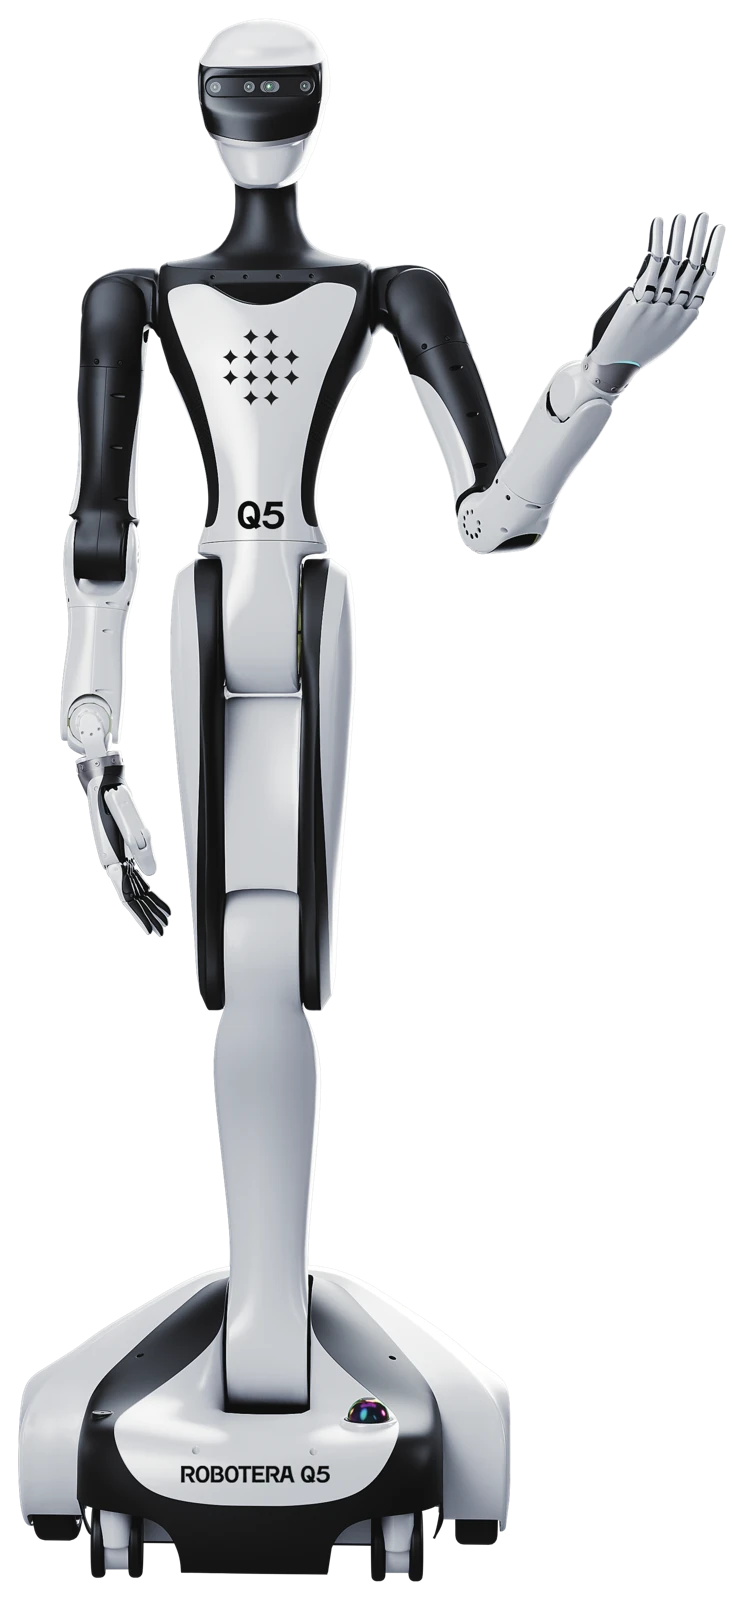
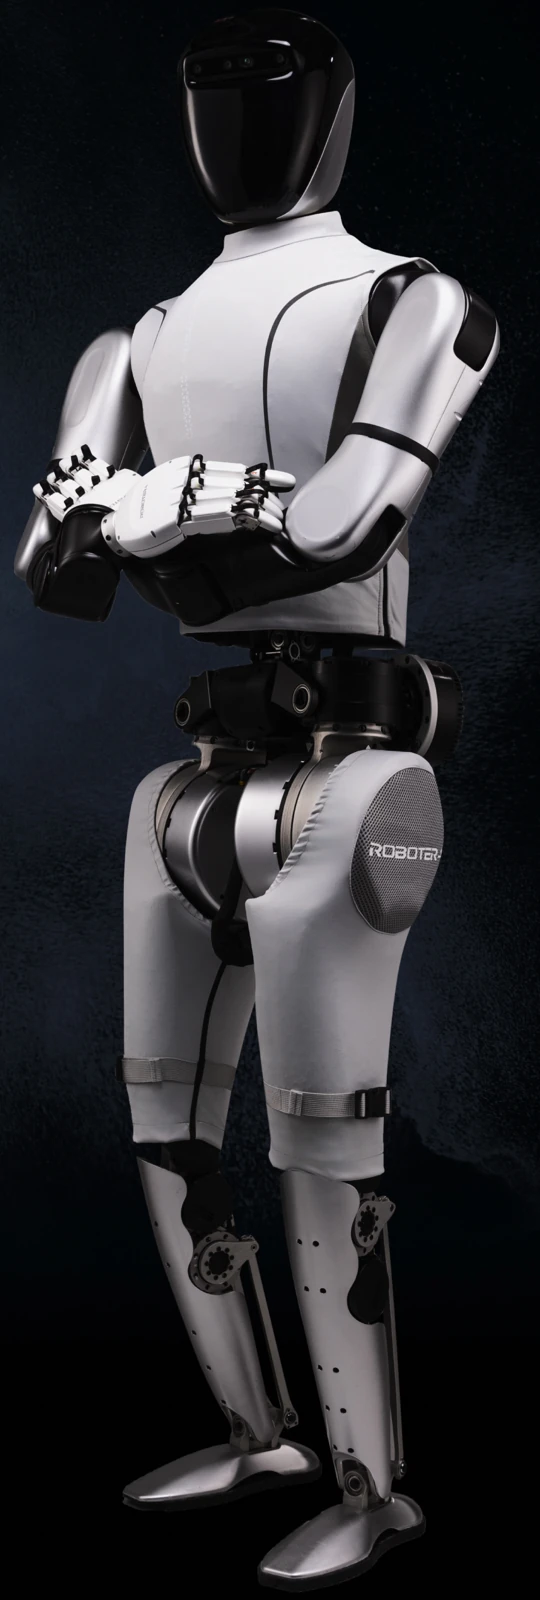
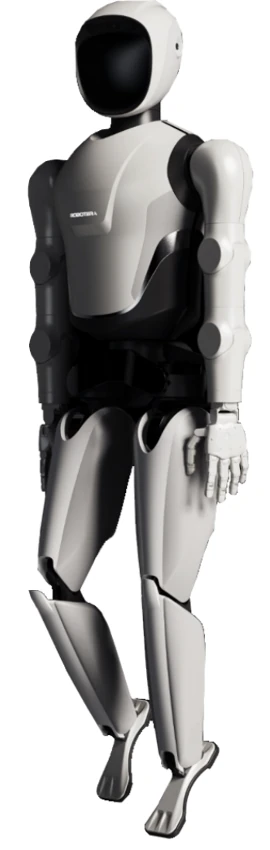
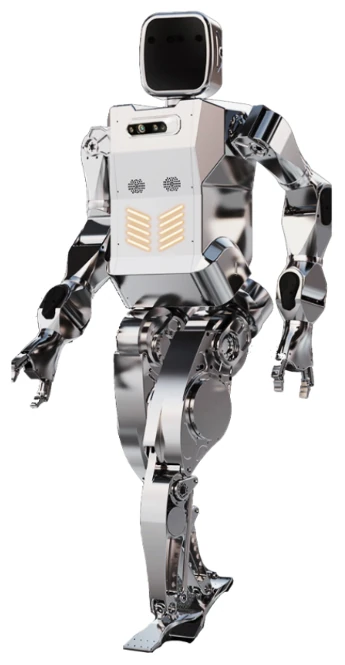
Current L7 biped and Q5 wheeled/lifting humanoid, M7 upper-body/stand manipulation platform, Historical STAR1 and XBot-S/L research platforms, XHAND1, Lite and PRO end effectors; not separate humanoid bodies, ERA42, VLA/world-model and teleoperation research
Export Markets
China: company and named China Post Guangzhou logistics applications, International research and component sales: maker claims 50% of 2025 XHAND1 hand shipments overseas, Europe: Robot Distribution seller listings; exact model deliveries unverified, RBTX by Cologne-based igus lists L7 / Q5 in international marketplace; regional supply by quote
EU Support and Service
| EU offices | No manufacturer-owned EU humanoid repair office verified; European seller is not manufacturer branch |
|---|---|
| Service regions | China manufacturer support and public developer repositories, European seller service claimed; country/model contract scope unverified |
| Distributors | Robot Distribution / Lammar Innovative, 130 rue Racine, 59200 Tourcoing France: seller-claimed L7 / M7 / Q5 purchase/rental/ RaaS and support, RBTX by igus SE&Co.KG Cologne: L7 / Q5 partner catalogue; exact regional price, stock and support must match quote |
| Integrators | Robot Distribution advertises site integration and training; no inspected independent acceptance or named RobotEra service SLA |
| Support languages | Chinese product pages and public manuals, English manufacturer brochures and GitHub READ MEs, Seller English/French pages; contracted technician languages unverified |
| Spare parts | European stock/battery/parts advertised by Robot Distribution; no independently verified inventory, fulfilment time or OEM authorisation |
| Warranty | Exact RobotEra whole-robot, battery, hand, labour and regional warranty duration/exclusions not verified. Seller promises warranty/after-sales handling but requires written quote; component/simulator licences are not hardware warranties. Current whole-body manual downloads display placeholders. |
| Training | Available |
Public ROS2 code, simulators and component documentation provide technical review material. Robot Distribution advertises on-site/remote training; exact courses, staff availability and commissioning commitments unverified. Manufacturer after-sales contact CC@robotera.com and 4009008798; GitHub support support@robotera.com. No message, lead form or order submitted.
Risk and Due Diligence
| Risk level | Unknown |
|---|---|
| Cybersecurity | Public Python SDK can actuate joints, base and hands over ROS2 Humble/ CycloneDDS within supplied developer environment. Restrict control access and match firmware/messages. Actual SDK-root reuse licence absent; STAR1 ROS README claims BSD but linked root file missing. Models BSD3, L7 lab MIT and V PP 2 MIT are separate repository rights, not blanket rights to firmware, weights or data. Exact patch lifetime, signing, SBOM and supported hardening unverified. |
| Data hosting | Public unnamed-app privacy statement says local motion/controller processing, not a policy for all robot/cloud/ ERA42 products. Maker says real work data feeds model improvement; exact customer data retention, training consent, remote access and EU residency require product contract. No blanket offline guarantee inferred. |
| Export controls | No exact customs/dual-use classification, export permission or country import approval inspected. Seller EU declaration promises do not supply the actual signed configuration dossier. |
| Supply chain | L7 current 65 kg excludes hands versus CES 70 kg unspecified; M7 mount/st and mass scope unresolved. Q5 combined arm load differs from hand component load. Require dated BOM, hardware/software revision, spares and battery plan. |
Company first- PMF /world record/efficiency claims are attributed. M7 has named Guangzhou application; full audited uptime, intervention, accepted unit counts and exact financial statements unverified. Hand/component customers and shipment counts are not automatically humanoid fleets; no numeric buyer readiness score assigned.
Funding and IPO Status
Maker/current timeline: near CNY 300 million Pre-A in 2024, near CNY 500 million A-round announced July 7, 2025, and near CNY 1 billion A+ announced November 20, 2025 led by Geely Capital with BAIC-related backing. In 2026: closed CNY 1 billion strategic round reported March 23 with valuation above CNY 10 billion; SF-led above USD 200 million announced April 27/confirmed government April 28 and English release May 8 (same round); a further CNY 1 billion Chengtong-led round reported July 7. No currency-converted totals added as exact proceeds. Exact cap table, closing instruments, valuation updates and audited revenue/profit not inspected. CNY 500 million cumulative orders, component shipments and planned/initiated thousand-unit delivery are not audited revenue or per-model accepted deliveries.
Sources and Further Reading
-
Current L7 full-body product matrix ↗
ROBOTERA · Accessed Nov 2, 2026
Rendered maker table: 1710 mm, 65 kg EXCLUDING hands, 55 full joints INCLUDING two 12-joint hands; 31 body joints. Dual-arm 20 kg, 4 m/s running, 400 Nm knee peak, 25 rad/s, 60 V 15 Ah. x86 80 TOPS plus Orin 275 TOPS are separate processor claims, precision unspecified. 2.1 m is workspace DIAMETER, not per-arm reach. Current website differs from January 2026 CES press release 70 kg without scope.
-
Current M7 upper-body and stand configuration ↗
ROBOTERA · Accessed Nov 2, 2026
Manufacturer explicitly calls M7 an upper-body humanoid, not an autonomous mobile chassis. Upper-body height 792 mm; published mass 65 kg with unresolved fixture/column inclusion. 43 full joints including 24 hand joints; 19 body joints. 717 mm arm length, 1660 mm armspan, 2.1 m workspace DIAMETER, Meta Quest teleoperation. Shared L7 upper-body architecture does not establish equal payload or standing-system dimensions.
-
Current public documentation catalogue ↗
ROBOTERA · Accessed Nov 2, 2026
Public catalogue opened through rendered page and its unauthenticated documents/simple-grouped endpoint. Nine visible entries are XHAND1 and XHAND1 PRO component guides; component instructions, firmware, licences and safety cannot automatically transfer to complete humanoids.
-
Current Q5 wheeled/lifting service platform matrix ↗
ROBOTERA · Accessed Nov 2, 2026
Maker: standing 582×519×1650 mm, 70 kg, 44 full joints; 7-joint arms and 11-joint XHAND1 Lite hands. Maximum 10 kg is COMBINED DUAL-ARM load; separate 10 kg hand-component load is not per-arm payload. 1380 mm armspan, 0–2 m reachable envelope, 3 D LiDAR /depth vision, 60 V, OVER 4 h full-load endurance. Runtime lower bound is not an exact scalar. VR /glove full-body teleoperation and navigation are maker capabilities.
-
Current RobotEra company, legal name and portfolio ↗
ROBOTERA · Accessed Nov 2, 2026
Rendered current official application, not the empty static HTML. Founded August 2023 by Chen Jianyu; company claims Tsinghua university shareholding. Footer now says 北京星动纪元科技股份有限公司. Current contact address: 7 F, VIA Building, Tsinghua Science Park, Haidian, Beijing. Current complete cap table and formally registered English legal name unverified. Product routes include L7, Q5, M7 and XHAND end-effectors; /product/Lite and /product/PRO are HANDS, not new humanoid bodies.
-
Current VPP2 world-action-model repository and MIT licence ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
README and actual root MIT licence read; third-party files retain original notices. Source-code grant does not establish all model-weight/data rights, cloud residency or autonomous capability for every customer robot. VPP2 benchmark performance is not a robot safety or production acceptance test.
-
European seller catalogue, conditional procurement and service claims ↗
Robot Distribution / Lammar Innovative, Tourcoing France · Accessed Nov 2, 2026
Seller current page updated October 22 lists L7 / M7 / Q5 on order, from EUR 105990/105990/66690 ex VAT; RaaS from 3599/3599/2269 per month. Claims EU declaration, European stock, parts/repair/training and rental. No signed exact-model declaration, warehouse inventory, OEM appointment or SLA independently inspected. Written quote and exact configuration govern; ap rice/claim is not validation of compliance.
-
Historical XBot-S/L research control framework ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
Official README explicitly verifies locomotion on XBot-S 1.2 m and XBot-L 1.65 m. Isaac Gym training, MuJoCo sim-to-sim and real transfer; uses XBot-L as example. Repository-wide licence absent at root; third-party base sub directory has separate licence. Does not establish current retail availability or full manipulation SDK.
-
L7 Isaac Lab workflow and actual licence file ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
Current README: Isaac Sim 5.1/ Isaac Lab 2.3.2 locomotion and single-motion tracking for L7, MuJoCo sim-to-sim and ROS2 sim-to-real deployment. Tracking-Flat- L7 _29 Dof is a policy-controlled subset, not contradiction of 55 full physical joints. Root LICENCE.txt is MIT, Isaac Lab copyright; underlying assets and sub packages retain their own notices.
-
Manufacturer download centre and documentation scope ↗
ROBOTERA · Accessed Nov 2, 2026
Current UI says first download redirects to a contact form. Public brochure assets referenced by the client were read directly without submitting lead details or a form. Body product manuals show placeholder size/date; do not assert a complete public L7 / Q5 / M7 safety manual. Document centre currently lists XHAND and XHAND PRO guides, not whole-humanoid manuals. Public text allows downloading resources for product promotion; exact licence for each picture remains unspecified.
-
Official dated product and funding announcement catalogue ↗
ROBOTERA · Accessed Nov 2, 2026
Public GET catalogue read after browser initially showed placeholders. Original dated entries: L7 launch July 22, 2025; Q5 debut June 19, 2025; A-round announcement July 7, 2025; A+ near CNY 1 billion announcement November 20, 2025; SF-led above USD 200 million announcement April 27, 2026. Entries link maker We Chat articles; catalogue dates are source publication evidence, not guaranteed first customer delivery. November 2, 2026 DHL / CIIE entry is event cooperation/preview, not independent installed-fleet evidence.
-
Original STAR1 manufacturer datasheet ↗
ROBOTERA · Accessed Nov 2, 2026
Two-page original English PDF read visually. STAR1 171 cm/63 kg/55 full joints, 31 body plus 24 hands; Orin 275 TOPS, IMU /vision, tactile, microphones and teleoperation. Outdoor tested up-to 3.6 m/s, 400 Nm maximum joint torque and 25 rad/s. Arms load OVER 20 kg has no clear per-arm/dual definition; 160 kg total structural load andover 25 kg HAND grip are not arm payload. Current L7 is separate.
-
Public app privacy policy with limited scope ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
Public policy says an unnamed App processes motion/controller data locally and does not collect personal data. It does not name every robot, ERA42, cloud inference or remote support product. Do not general is e this app statement into a complete robot data-residency or no-telemetry guarantee. No version/effective date shown.
-
Public ROS2 Python control API and exact model list ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
Root README and full file index inspected. Python ROS2 Humble/ CycloneDDS inside supplied developer environment, using teleop_client message definitions. Explicit Q5, L3, L7 model selector; initial is at ion, trajectory, MPC / ServoPose, hand and base interfaces. No root licence file exists in inspected tree; public visibility does not grant unrestricted reuse. Internal L3 identifier has no inspected retail hardware mapping; not invented as a new SKU.
-
RBTX/igus public RobotEra partner catalogue ↗
RBTX by igus · Accessed Nov 2, 2026
Official RBTX partner catalogue lists L7 and Q5. Inspected regional page is India, not an exact EU stock/price commitment. Separate imprint identifies operator igus SE&Co.KG in Cologne, Germany; operator address is not proof of RobotEra humanoid repair authorisation or local spare inventory.
-
RBTX legal operator and Cologne address ↗
RBTX / igus SE & Co. KG · Accessed Nov 2, 2026
RBTX imprint identifies igus SE & Co. KG, Spicher Str. 1a, 51147 Cologne. This identifies the marketplace operator, not a RobotEra manufacturer office or a model-specific repair centre. No contact message was sent.
-
STAR1 public ROS2 example/control packages ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
Dev-branch STAR1 example packages, trajectory action server, xbot interfaces and TorchScript RL controller, with developer mode/ready/activate services. README claims BSD3 but its linked root LICENSE returns 404; actual per-file/package grant still requires review. Service names are not tested emergency-stop safety validation.
-
STAR1 URDF and inspected BSD-3-Clause licence ↗
RobotEra official roboterax GitHub account · Accessed Nov 2, 2026
Root README gives STAR1 joint breakdown: legs 12, arms 14, hands 24, waist 3, head 2, total 55. Actual root BSD3 licence read, copyright RobotEra 2024. This grants repository rights, not all robot firmware, policies, commercial software or photographs.
-
IPO report includes company denial ↗
International Finance News / Eastmoney · Published Aug 18, 2026 · Accessed Nov 2, 2026
International Finance News reporter Wu Di reports August 17 HK IPO rumour and quotes company representative saying it is untrue. Rumoured USD 800 million–1 billion financing target is not an accepted filing, listing, stock ticker or money raised. No formal audited company financials identified in reviewed sources.
-
Reported CNY 1 billion Chengtong-led financing ↗
STAR Market Daily / Cailian Press; Eastmoney reprint · Published Jul 7, 2026 · Accessed Nov 2, 2026
STAR Market Daily reporter Li Mingming reports recently completed CNY 1 billion round led by Chengtong, with Jiangxi state capital, Yufu/Hangzhou and financial investors. University shareholding via Huakong Technology Transfer. Maker official closing instrument and exact round day unverified; article is dated July 7. Company-attributed 85%-human efficiency and 24 h site operations are not independent audited tests.
-
Reporter visit distinguishes observation and fleet claims ↗
Beijing Daily client · Published Jun 11, 2026 · Accessed Nov 2, 2026
Beijing Daily June 10 company visit observed parcel picking. Interviewee says flat coat-hanger-like objects remain difficult. More-than 10 cities andup-to 1200 items/h are reported/attributed company figures, not independent longitudinal uptime or SKU-unit audit. Source documents targeted data collection/training for sorting.
-
Named M7 China Post Guangzhou application ↗
Xinhua Net · Published May 20, 2026 · Accessed Nov 2, 2026
Xinhua-hosted account explicitly names M7 at China Post Guangzhou postal centre, with XHAND1 and ERA42, parcel picking/turning/induction coordinated with existing automation. Reports up-to 1200 items/h and above 85%of human efficiency; measurement protocol, independent uptime, intervention and acceptance documents not provided. No automatic transfer of M7 application to L7 / Q5.
-
English release of same above USD 200 million financing ↗
ROBOTERA / PRNewswire · Published May 8, 2026 · Accessed Nov 2, 2026
English maker release May 8 describes the same SF-led above USD 200 million round already announced April 27–28. Do not double count. Reports deployments across 10-plus logistics centres and initiated thousand-unit delivery in Q2; does not provide audited shipped/accepted per-model counts. Named global hardware customers may buy hands/components, not necessarily humanoids.
-
Government account of completed SF-led financing ↗
Zhongguancun Science City / International Science and Technology Innovation Center Beijing · Published Apr 28, 2026 · Accessed Nov 2, 2026
Government-hosted Zhongguancun Science City account confirms above USD 200 million round led by SF, with HSG, IDG, CICC and other investors, following March CNY 1 billion. Published April 28; maker catalogue dates April 27 and English press release May 8. These are different announcement dates, not three rounds. Thousand-unit Q2 delivery and 10-plus logistics centres are attributed aggregate claims, not exact L7 / Q5 / M7 allocations.
-
Maker March 2026 financing and commercial claims ↗
ROBOTERA / PRNewswire · Published Mar 23, 2026 · Accessed Nov 2, 2026
Maker supplied press release: closed CNY 1 billion strategic financing, valuation above CNY 10 billion. Names Gaocheng, Singtel Innov8, Woori, CICC Porsche and other funds plus unnamed Korean technology investor; do not replace unnamed party with Samsung as a verified round participant. Cumulative orders above CNY 500 million and hand shipments above 1000 in 2025 are company claims, not audited revenue or humanoid-unit deliveries.
-
L7 / Q5 demonstrations and scoped CES claims ↗
ROBOTERA / PRNewswire · Published Jan 8, 2026 · Accessed Nov 2, 2026
Maker CES release: L7 171 cm/70 kg without mass scope/55 full joints/20 kg dual-arm load, full-body teleoperation; Q5 44 joints, visitor interaction and squat object pickup. Current L7 brochure instead 65 kg EX hands; do not assume exactly 5 kg hand mass. Hexa-Core refers to six qualities, not six robot bodies. More-than 600 aggregate products delivered is not 600 L7s.
-
Founder first-hand historical platform account ↗
Lenovo Capital; interview with Chen Jianyu · Published Sep 5, 2024 · Accessed Nov 2, 2026
Investor-hosted direct founder interview: university project began 2022, company incubated 2023; Xiaoxing family had six engineering generations by August 2024. Iteration descriptions are not six separately marketed SKUs. Exact Xiaoxing generation-to- XBot / STAR1 mapping is not established; avoid copying specifications across names.
-
Original Humanoid-Gym paper and labelled hardware figure ↗
Xinyang G u, Yen-Jen Wang and Jianyu Chen / ar Xiv · Published May 18, 2024 · Accessed Nov 2, 2026
Original author paper first submitted April 8, 2024, revised May 18. Fig u re 5 on PDF page 5 visually read: XBot-S 1200 mm/38 kg/32 TOTAL DOF /26 actuated motors; XBot-L 1650 mm/57 kg/60 TOTAL DOF /54 actuated motors. Total kinematic count differs from actuator count. Real locomotion experiments are research evidence, not commercial deployment. ar Xiv source explicitly licences article CC BY 4.0; cropped original hardware illustration credited.