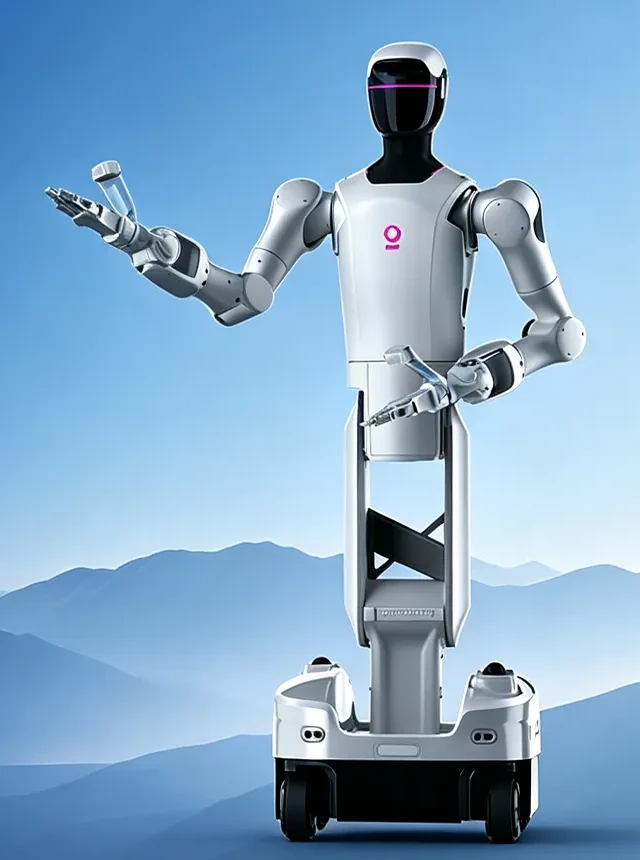
MagicLab
Commercially available
MagicBot D1 Base Compute Edition
Wheeled/lifting industrial humanoid; base-compute configuration
Explore model profile ⟶The machines / Robot index
From research platforms to industrial humanoids. Explore the models, inspect the specifications, and follow the evidence.
Wheeled/lifting industrial humanoid; base-compute configuration
Explore model profile ⟶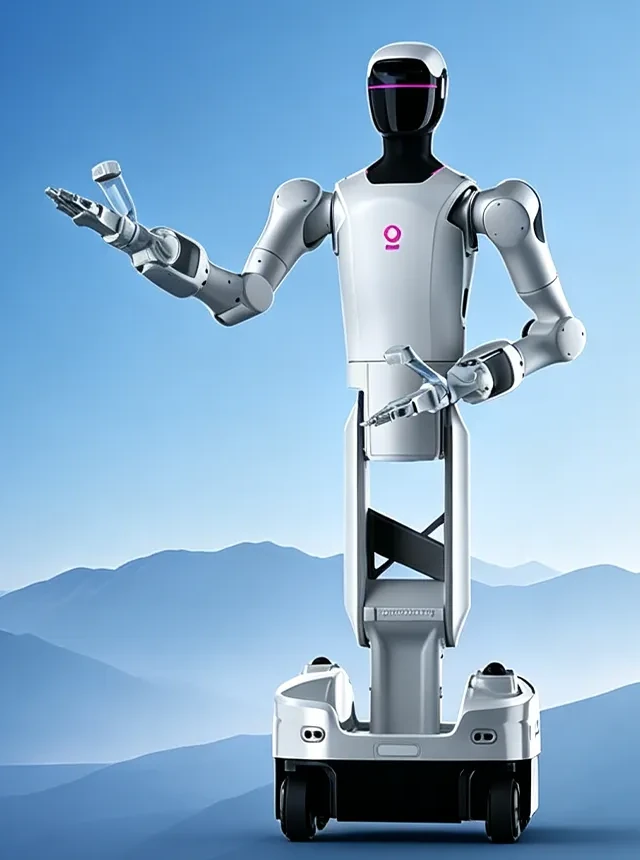
Wheeled/lifting industrial humanoid; high-compute configuration
Explore model profile ⟶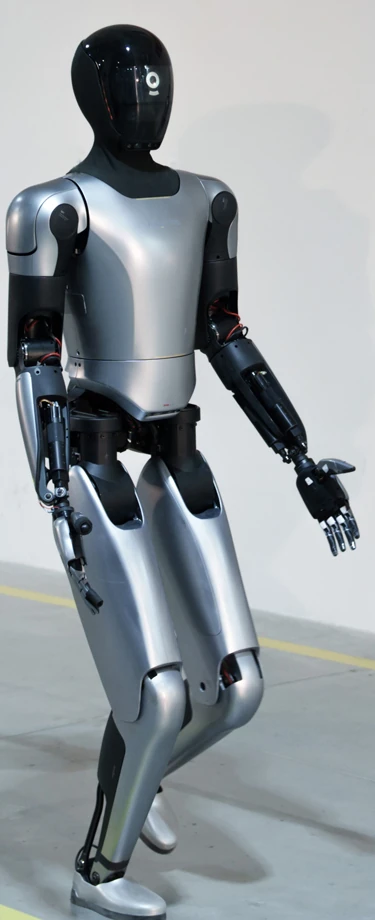
Full-size biped / Xiaomai; 42 active axes, 52 physical joints
Explore model profile ⟶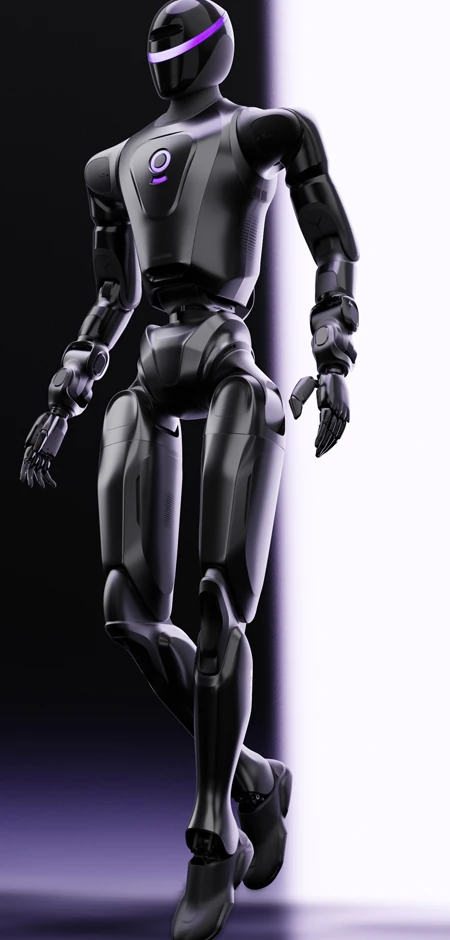
Full-size biped; commercial configuration without secondary development
Explore model profile ⟶
Full-size biped; developer/high-compute configuration
Explore model profile ⟶
Compact biped; optional wrists/hands and native SDK entitlement
Explore model profile ⟶
Compact biped; 24 base joints; no secondary development entitlement
Explore model profile ⟶