Commercial Context
Maker IFA report claims teams in Germany, Italy and Spain; exact addresses/repair capability unverified. Robot Distribution in France advertises purchase/rental/RaaS, parts and after-sales for Gen1/Z1/X1/D1. These are seller promises; exact OEM appointment, stock, signed declaration and local service SLA not inspected.
Product Focus
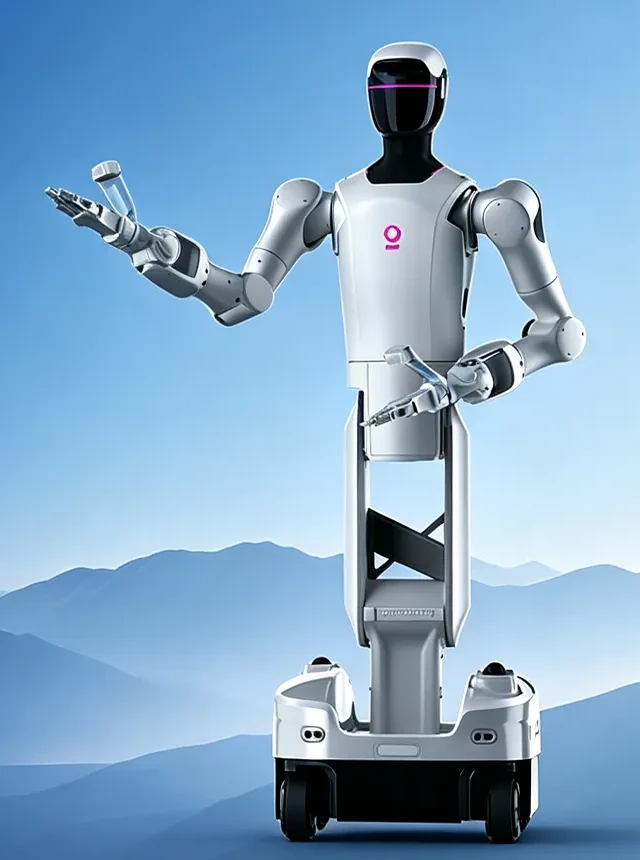
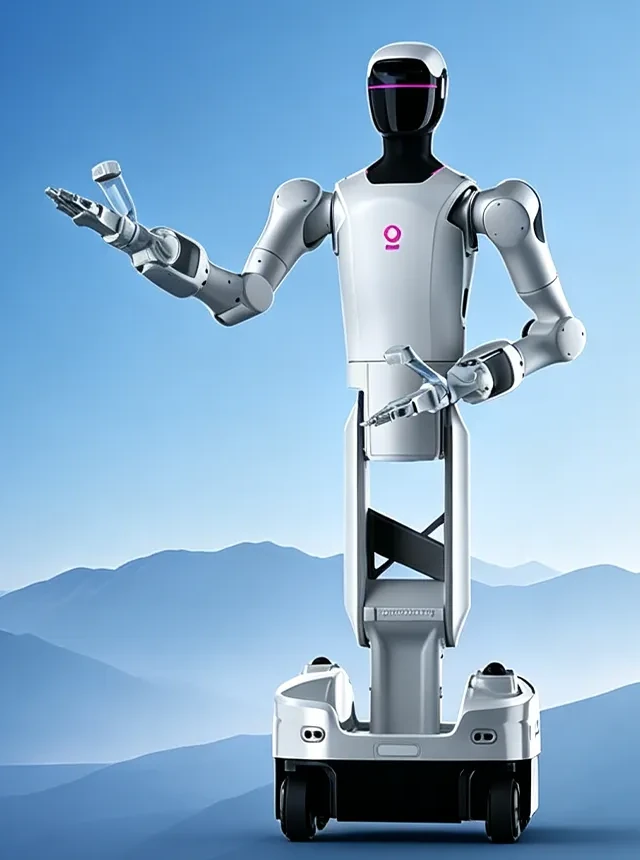
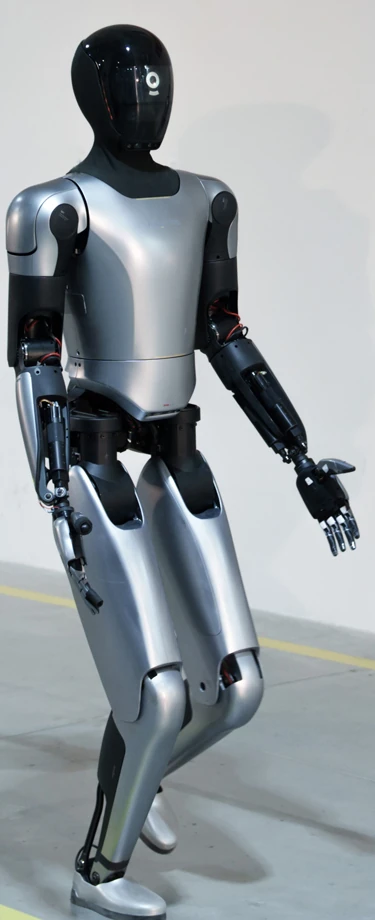
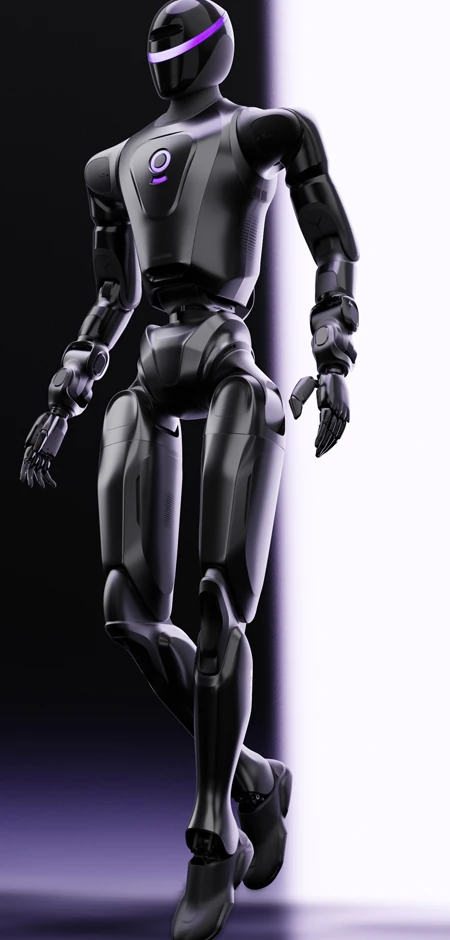
Gen1 full-size humanoid / Xiaomai, Z1 Standard and Developer configurations, X1 Standard and Ultra configurations, D1 wheeled industrial humanoid with Base/High Compute options, Magic-Mix world model; quadrupeds, MagicArm and hands are separate products
Export Markets
China: maker-attributed Dreame industrial and Shanghai museum applications, April 2026 maker claims 50-plus countries and 60% 2025 overseas sales; August Wuxi report says near30 and over30%, scope conflict unresolved, Europe: IFA demonstrations, manufacturer team claim and French reseller catalogue; exact accepted humanoid fleet unverified
EU Support and Service
| EU offices | Manufacturer claims support/sales teams in Germany, Italy and Spain; exact locations and legal/service entities unverified |
|---|---|
| Service regions | China and international manufacturer inquiry, European seller support claimed; exact model/country contract scope unverified |
| Distributors | Robot Distribution / Lammar Innovative, Tourcoing France: seller-claimed Gen1/Z1/X1/D1 purchase/rental/RaaS; OEM appointment unverified |
| Integrators | Manufacturer scenario integration and French seller services advertised; accepted site-specific scope unverified |
| Support languages | Chinese, English, French seller website; technician languages by contract |
| Spare parts | Manufacturer spare-parts terms; European seller stock/parts advertised without inspected physical inventory |
| Warranty | Published Standard Sales Terms define 12 months from delivery for attributable defects under proper use. Falls, crushing, immersion, unauthorised parts/modification and other misuse excluded; seller chooses remedy. Replacement transit costs borne by seller under clause 8.5. Clause 8.7 offers necessary parts for two years after warranty at preferential prevailing prices, six-month cessation notice and eight-week last-order window. Confirm exact model, battery/hand exceptions, territory and signed-contract overrides; no European response SLA verified. |
| Training | Available |
Official native C++/Python SDKs, public Gen1/Z1 manuals and English/Chinese product information. Manufacturer advertises training/remote assistance; course, commissioning, travelling technician and repair response details unverified. Contact contact@magiclab.top or contacts@magiclabglobal.com; no inquiry or form submitted.
Risk and Due Diligence
| Risk level | Unknown |
|---|---|
| Cybersecurity | Native SDK can control joints and high-level motion; match hardware/firmware and control-client authority. Gen1 FAQ requires wired development and one App/SDK controller. BSD SDK/description and Apache Z1 RL rights do not license firmware, all weights or datasets. Signing, patch lifetime, SBOM and supported hardening unverified. |
| Data hosting | Gen1 manual supports offline voice and local maps; complete speech/AI/OTA/telemetry offline scope unverified. D1 Dreame case says work data feeds development. Current global privacy page has no substantive product processing policy in retrieved content; residency, retention, consent and remote support require model-specific agreement. |
| Export controls | IFA CE-RED completion is a Q4 2026 target, not inspected certificate. Seller declaration promise does not supply exact signed delivered-configuration dossier. Exact classification and country import paperwork unverified. |
| Supply chain | Require dated body/hand/compute BOM: active versus passive joints, Gen1 rated versus maximum load, Z1 optional wrists/hands and D1 compute precision differ. Future Wuxi10,000-unit capacity is quadruped capacity, not humanoid shipments. |
Named sites are manufacturer accounts; no independent duty-cycle, intervention, accepted unit fleet or audited financials identified. Gu Shitao is called president in GEIS account; founder Wu is no longer current CEO. No numeric buyer readiness score assigned.
Funding and IPO Status
December 25, 2024: maker announced CNY 150 million angel round led by Zhuichuang with Yipu. May 26, 2025: several hundred million yuan strategic financing, exact amount undisclosed. Wuxi government confirms CNY 500 million completed in March 2026. Ecosystem fund/investment targets are separate from company financing; no exact cumulative proceeds, valuation, cap table or audited revenue/profit verified. Wu Changzheng is a former CEO: March 2026 company-confirmed departure. Current CEO not verified.
Sources and Further Reading
-
Current MagicLab identity and headquarters ↗
MagicLab · Accessed Nov 2, 2026
Current footer identifies Magiclab Robotics Technology (Wuxi) Co., Ltd.; company says founded January 2024. Current global contact is No.98 Jianghai West Road, Liangxi, Wuxi, replacing older Suzhou profile. Hardware self-development percentages and staffing are manufacturer claims. Original site explicitly links the new magiclabglobal.com domain.
-
D1 wheeled humanoid and two compute editions ↗
MagicLab · Accessed Nov 2, 2026
Height1190–1800 mm, width620/length670 mm, 150 kg unscoped mass; 5 kg PER ARM, 858 mm reach excludes end effector. Claims 25 active axes, but component sum is25–27 with4–6-axis chassis; exact delivered configuration unresolved. Base Compute: Huawei R1,500 TOPS INT8; High Compute: NVIDIA-Aurora1500S,2070 TOPS FP4, exactly as printed and not independently mapped to chips. Not directly comparable precisions. Two packs1652 Wh,4 h runtime/2 h charge,10 GbE/WiFi/BT/4G;54.75 V15 A is charger output. Whole IP42/arms IP50 are maker ratings, not inspected certificates.
-
Global privacy page content gap ↗
MagicLab · Accessed Nov 2, 2026
Opened page has privacy heading/navigation but no substantive product privacy statement in retrieved content. Does not establish robot telemetry, model-training consent, retention, remote diagnostics, EU residency or complete offline operation. Original-site Policies and Terms page also inspected; no product-specific processing architecture established.
-
MagicBot Gen1 current global catalogue ↗
MagicLab · Accessed Nov 2, 2026
Global catalogue gives ≥2 m/s, dual-arm maximum 15 kg and 7.5 kg per-arm marketing claim, 42 active axes, 62.25 V MAXIMUM voltage, 3–5 h endurance. This does not establish nominal battery voltage or continuous 15 kg handling. Compare detailed December 2025 manual for 5 kg rated versus 7.5 kg maximum per arm.
-
MagicBot Gen1 current original-site specifications ↗
MagicLab · Accessed Nov 2, 2026
1740×580×280 mm, approximately 70 kg, 42 ACTIVE axes including 12 active hand axes; 25 Ah/1.35 kWh, 3–5 h endurance and 3 h charge. Speed ≥4 km/h is a lower bound, not maximum 1.11 m/s. Legacy 100 TOPS lacks chip/precision identification. Exact physical robot and contract take precedence.
-
MagicLab Standard Sales Terms: warranty and parts ↗
MagicLab · Accessed Nov 2, 2026
Terms define12-month warranty from delivery for attributable defects under proper use; clause8 excludes falls/crushing/immersion, unauthorised parts/modification and specified misuse. Seller selects repair/replacement/refund remedy;8.5 seller bears replacement transit costs.8.7 offers necessary parts for2 years after warranty at preferential prevailing prices,6-month cessation notice and8-week last-order window. Exact product,battery,territory and signed-contract overrides need confirmation. Not a guaranteed European repair SLA.
-
Magic-Mix and X1 GEIS hardware announcement ↗
MagicLab · Accessed Nov 2, 2026
Migrated site dated July 16, 2026, body describes April 28 PST event. X1 180 cm/70 kg/31 active axes, 450 Nm peak and Standard versus Research editions; current site uses Ultra, exact Research/Ultra package equivalence not proven. H01 is separate hand component. Magic-Mix world model and long-term 2036 USD14b revenue/5-year ecosystem investment are targets, not actual revenue or finance raised.
-
Maker D1 Dreame smart-factory case ↗
MagicLab · Accessed Nov 2, 2026
Company says D1 actively handles material transport and line-side loading/unloading at Dreame, integrates warehouse/production systems and feeds work data into development. No independently audited unit count, paid acceptance, compute edition, intervention or uptime supplied. No-line-modification and24/7 wording is marketing, not universal site guarantee.
-
Maker Gen1 Modern Art Museum Shanghai case ↗
MagicLab · Accessed Nov 2, 2026
Maker dates guided-tour launch September2025 at Modern Art Museum Shanghai, synchronising voice, gestures and exhibit screens; claims160-plus voices/multilingual switching. Worlds-first claim not independently established; no accepted unit count, operating uptime or contract inspected.
-
Manufacturer global support services ↗
MagicLab · Accessed Nov 2, 2026
Manufacturer advertises training, remote assistance, parts and maintenance. Exact local stock, service addresses, response guarantees, technicians and each model coverage not verified; broader promise is not a named repair SLA.
-
Official GEN1 native control SDK and actual BSD licence ↗
MagicLab · Accessed Nov 2, 2026
Root README and BSD-3-Clause LICENSE read. C++20 with Python3.10 bindings, Ubuntu22.04 or later suggested, GCC11.4/CMake3.16/Eigen; Z1 adds OpenCV4.5. Native robot control and sensor/service APIs; public quadruped ROS2 package does not apply to humanoids. Firmware/version and developer entitlement matter. Repository licence is separate from proprietary robot firmware/data.
-
Official GEN1 URDF/MJCF description ↗
MagicLab · Accessed Nov 2, 2026
README and actual BSD-3-Clause LICENSE read. 30 body joints; excludes hand mechanisms from52 physical full-body count. RViz/MuJoCo examples and ROS description tooling are not blanket ROS2 robot-control compatibility.
-
Official Z1 native control SDK and actual BSD licence ↗
MagicLab · Accessed Nov 2, 2026
Root README and BSD-3-Clause LICENSE read. C++20 with Python3.10 bindings, Ubuntu22.04 or later suggested, GCC11.4/CMake3.16/Eigen; Z1 adds OpenCV4.5. Native robot control and sensor/service APIs; public quadruped ROS2 package does not apply to humanoids. Firmware/version and developer entitlement matter. Repository licence is separate from proprietary robot firmware/data.
-
Official Z1 URDF/MJCF description ↗
MagicLab · Accessed Nov 2, 2026
README and actual BSD-3-Clause LICENSE read. 23 actuated joints in description, versus24 base robot joints including head; simulator/control subset does not prove a different retail generation. RViz/MuJoCo examples and ROS description tooling are not blanket ROS2 robot-control compatibility.
-
X1 current global catalogue and Standard scope ↗
MagicLab · Accessed Nov 2, 2026
Current global page publishes Standard table; this does not remove explicit Ultra option on original maker site. Family images do not identify installed compute or software entitlement. Do not assume new H01 hand is included in the 31 body-axis count or default package.
-
X1 Standard and Ultra current configuration table ↗
MagicLab · Accessed Nov 2, 2026
Both 1800×554×280 mm, 70 kg without mass scope, 31 active body axes (head2, arms14, waist3, legs12), 1580 mm armspan. Standard Orin NX/stereo and no secondary development. Ultra adds unlocked developer computer, up-to AGX Thor 2070 TOPS (precision unspecified), head/waist RGB-D and optional LiDAR. Dual-pack 18 Ah system with hot-swap claim; no verified single-pack endurance, payload or maximum speed. Peak ≥350 and maximum ≥400 Nm marketing labels differ from launch 450 Nm; not arm loads.
-
Z1 12-axis IsaacLab locomotion research ↗
MagicLab · Accessed Nov 2, 2026
README and actual root LICENCE read: Apache2.0. IsaacSim5.1/IsaacLab2.3, Z1-12dof velocity training, MuJoCo sim2sim then real deployment.12 axes is locomotion/control subset, not a new12-joint retail body. README clone URL has extra robotics suffix; review actual checked repository. No standard-edition developer entitlement granted.
-
Z1 English product manual V2.0 ↗
MagicLab · Accessed Nov 2, 2026
Linked from /en/app/z1, catalogue January 7, 2026 while filename says 260116; revision/date mismatch retained. PDF matrix visually checked: Standard 24 joints/40 kg with battery/2 kg maximum arm load; Developer 24–50 options/40 kg+/3 kg. Optional two extra wrist axes per arm and 11-joint hands; maximum 50 is not all active axes. Remove battery for charging; no direct wired charging on body. Manual requires visibility, clearance, support rack/rope and warns simultaneous high-level API and remote commands can destabilise robot. Exact per-arm load scope remains unqualified.
-
Z1 MuJoCo sim-to-sim example ↗
MagicLab · Accessed Nov 2, 2026
README describes z1_12dof MuJoCo runner. Public root file listing inspected; no root licence found. Do not infer Apache rights from separate IsaacLab repository or call every code/weight open-licensed.
-
Z1 Standard and Developer Edition matrix ↗
MagicLab · Accessed Nov 2, 2026
Two maker columns: Standard approximately 40 kg WITH battery, 24 joints, 100 Nm maximum knee torque, maximum arm load 2 kg, no secondary development. Developer approximately 40 kg+, 24–50 optional joints, 130 Nm, maximum arm load 3 kg, SDK entitlement. Both 1369×422×200 mm; 730×422×395 mm folded, quick-release 10 Ah/15-cell battery and approximately 2 h laboratory endurance. 62 V 5 A is CHARGER output, not confirmed nominal battery voltage. Arm-load per-arm/combined basis is not explicit.
-
Robot Distribution MagicLab European sales catalogue ↗
Robot Distribution · Published Oct 29, 2026 · Accessed Nov 2, 2026
Updated October29,2026: France-based seller lists Gen1,D1,Z1,X1 plus non-humanoid products, purchase/rental/RaaS, parts/support and EU declaration promise. Brand page prices are quotation only. OEM authorisation, physical stock, exact configurations, signed declarations and response SLAs not independently inspected. Seller general conformity promise does not prove manufacturer CE-RED target already completed.
-
IFA European demonstration, support and certification targets ↗
MagicLab · Published Sep 9, 2026 · Accessed Nov 2, 2026
Posted September9, body dateline September8 and event September4–8. Company claims local sales/support teams in Germany,Italy,Spain and TÜV SÜD/TÜV Rheinland partnerships. CE-RED completion is explicitly TARGETED Q4 2026, not achieved certification. Industrial handling/sorting exhibit and proposed regional scale-up are not independently accepted European production lines.
-
Wuxi headquarters construction and dated financing report ↗
CPPCC Wuxi municipal committee · Published Aug 2, 2026 · Accessed Nov 2, 2026
August1 HQ construction started; future planned4 joint-module/2 whole-machine lines and10,000 annual capacity is explicitly9000 SMALL QUADRUPEDS plus1000 LARGE QUADRUPEDS, not humanoids or shipped units. Confirms March2026 completed CNY500m financing. CNY150m healthcare order is not revenue or accepted model fleet; near30 markets/over30% overseas revenue differs from April maker numbers.
-
Contemporaneous April X1 and global strategy release ↗
MagicLab / PRNewswire · Published Apr 29, 2026 · Accessed Nov 2, 2026
April 29 release confirms X1/Magic-Mix/H01 showcase; local event April 28 per maker account. Claims 2025 overseas sales share 60% and 50-plus countries. August Wuxi report instead near30/over30%; different dates/coverage and unresolved conflict, not reconciled into a single audited number. Ecosystem USD1b plan and 2036 revenue target are not current capital or sales.
-
Company confirms former CEO Wu Changzheng departure ↗
National Business Daily / Red Star Capital Bureau · Published Mar 5, 2026 · Accessed Nov 2, 2026
Company confirmed founder/former CEO Wu Changzheng left; source close to company attributes R&D leadership to CTO Chen Chunyu. Do not list Wu as current CEO. Exact current CEO/cap table not verified.
-
MagicBot Gen1 English product manual V1.0 ↗
MagicLab · Published Dec 24, 2025 · Accessed Nov 2, 2026
Original PDF linked by /en/app/g1; version page dates December 24, 2025; download catalogue December 30. Printed page 16 / PDF page 19 visually checked: single-arm RATED 5 kg, MAXIMUM 7.5 kg; 800 mm shoulder-to-fingertip span, 785 mm working radius, claimed <1 mm repeatability under named 0.5/3/5/7.5 kg loads. 52 total joints include passive hand joints. Intro says up to 2 m/s versus current catalogue ≥2 m/s; do not assert an unqualified current maximum. Offline voice and local map management are explicitly supported, not a blanket offline/cloud guarantee. Electronic warranty card supplied at delivery.
-
Z1 public SLAM API and operating envelope ↗
MagicLab · Published Oct 16, 2025 · Accessed Nov 2, 2026
Rendered October 16, 2025 guide: mapping, localisation, map management and target navigation via RPC. Explicitly limited to feature-rich, static, flat indoor areas smaller than 100×100 m; intended for education/research, industrial applications should contact sales. Requires localisation and map configuration; not proof of unconstrained factory navigation.
-
Gen1 SDK operating constraints and navigation prerequisites ↗
MagicLab · Published Sep 15, 2025 · Accessed Nov 2, 2026
Guide updated September 15, 2025: wired development only, recommended 500 Hz low-level commands/state, firmware-matched SDK tags; one App or SDK controller at a time. Local logs and SLAM localisation prerequisites documented. An internal ROS2-service error message is not proof of a supported external ROS2 humanoid SDK.
-
Z1 developer hardware overview ↗
MagicLab · Published Jul 9, 2025 · Accessed Nov 2, 2026
Public guide updated July 9, 2025 describes developer configuration and locked motion versus developer compute. Orin NX 16 GB/512 GB does not establish equal compute or SDK access on Standard. 24–50 scope includes optional wrists and physical hand joints.
-
Original Z1 launch announcement ↗
MagicLab · Published Jul 8, 2025 · Accessed Nov 2, 2026
Original July 8, 2025 publication establishes Z1 launch. New global site migrates older announcements under July 2026 dates; do not turn these into a new generation. Standard/Developer are explicit hardware/control configurations; reseller V1–V6 labels have no inspected OEM revision mapping.
-
MagicBot Gen1 public developer overview ↗
MagicLab · Published Jun 30, 2025 · Accessed Nov 2, 2026
Rendered public Chinese guide, updated June 30, 2025: 52 total joints = head2, arms14, hands22, waist2, legs12. Each hand has six active plus five passive joints. Developer unit Jetson Orin NX 16 GB/512 GB alongside locked motion unit; Livox MID360, two RealSense D435 and three fisheye cameras. External 54 V rail is not proof of battery nominal voltage.
-
Completed strategic financing in hundreds of millions of yuan ↗
MagicLab · Published May 26, 2025 · Accessed Nov 2, 2026
Maker May26,2025: completed several hundred million yuan strategic round; named investors 禾创致远、芯联资本、华映资本、晓池资本、元禾厚望, plus existing 追创创投/翼朴基金. Exact amount not disclosed; do not force an A-round classification from aggregators. January2024 founding and company-attributed hardware self-development.
-
CNY150 million angel financing announcement ↗
MagicLab · Published Dec 25, 2024 · Accessed Nov 2, 2026
Maker December25,2024:completed CNY150m angel led by Zhuichuang Venture Capital with Yipu Fund. Hundreds of2025/thousands of2026 delivery wording is a target, not actual humanoid shipments.