Industrial Applications
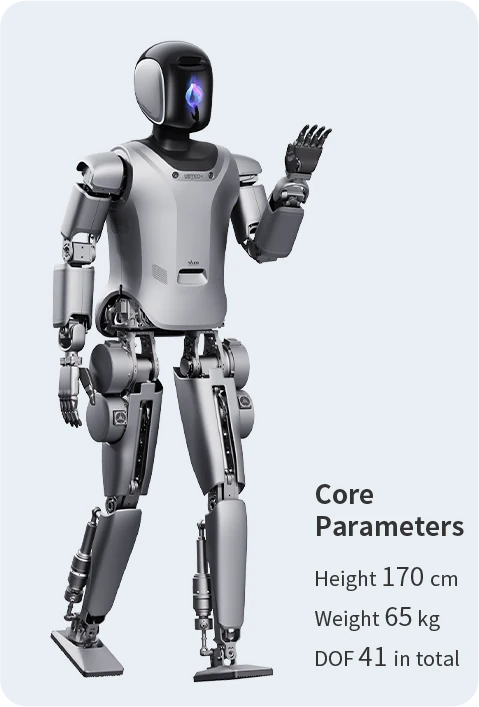
Walker S is an earlier industrial research and training generation. Its own labelled graphic specifies 65 kg; the previous 76 kg figure belonged to a different generation.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
The comparison gives 600 mm arm reach; no model-specific rated load was verified. Peak actuator torque does not establish end-effector payload.
Comparison depicts an AMOLED face display, microphone array and stereo perception. Exact sensor revisions and industrial task package require confirmation.
SDK and Integration
Walker S family page names ROSA 2.0 and manufacturing-system integration. Exact interfaces, language bindings and simulator access for this configuration were not verified.
| API type | Model-specific access requires confirmation |
|---|---|
| Languages | Needs verification |
| ROS support | ROSA 2.0 named on family page; ROS/ROS2 package and version not established for this exact configuration. |
| Simulation | No exact-model public simulator package verified. |
| Offline operation | Exact local/cloud task boundaries not established. |
| Teleoperation | No exact-model public teleoperation package verified. |
| Software updates | Firmware availability and support period not established. |
| Documentation | Open documentation |
| Integration constraints | Confirm shipped hardware, SDK access, licence, controller version and model-specific examples. |
Safety Notes
Public motion, collision-avoidance or force-control claims do not establish certified collaborative operation. Assess fall or mobile-base risk and the intended task with the supplied safety documentation.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No exact-model certificate, test report or declaration verified in this review; this row is not evidence of conformity. |
| ISO 10218-1:2025 / ISO 10218-2:2025 | Unknown | International | No exact-model certificate, test report or declaration verified in this review; this row is not evidence of conformity. |
Commercial Readiness
| Pricing | No exact-model, dated public price verified; obtain a configuration-specific quotation. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China; international fulfilment requires quotation |
| Spare parts | Battery, actuator and end-effector revision compatibility, stock and repair turnaround require confirmation. |
| Warranty | Exact-model contractual cover not verified. Published S2/TienKung warranties do not automatically apply. |
| Configuration and pricing basis | Quotation required; no exact-configuration public price verified. |
| Distributors and service | Terra has an announced DACH distribution agreement; confirm that this model and configuration are included. |
No independently verified production lead time or general availability guarantee.
Specifications
| Height | 1700 mm |
|---|---|
| Weight | 65.00 kg |
| Payload | Unknown |
| Runtime | 150 min |
| Battery and runtime conditions | Official labelled comparison graphic claims 2.5 hours with a detachable battery; task mix and pack capacity are not specified. |
| Degrees of freedom | 41 |
| Max speed | Unknown |
| Locomotion | Bipedal humanoid Source ↗ |
| Model-specific comparison | 1700 mm, 65 kg, 41 total DOF; manufacturer graphic. Do not substitute specifications from another Walker generation. Source ↗ |
| Manufacturing-system connection | Supplier states Walker S can connect to manufacturing management systems for real-time production-status data exchange Source ↗ |
| Object detection and grasping | 3D point cloud processing and 6D pose recognition for object grasping Source ↗ |
| 3D semantic navigation | RGBD visual sensors, 3D semantic mapping, route planning and obstacle avoidance Source ↗ |
| Perception system | Visual, audio, distance and force-feedback perception with multimodal sensor fusion Source ↗ |
| Robot operating system | ROSA 2.0 Source ↗ |
Sources and Further Reading
-
ISO 10218-1:2025 Robotics — Safety requirements ↗
ISO · Accessed Jun 20, 2026
Primary standards source. ISO 10218-1 covers robot safety requirements; ISO 10218-2 covers industrial robot applications and integration.
-
Legacy Walker simulation platform ↗
UBTECH Robotics · Accessed Nov 1, 2026
Legacy Walker/2020 simulation challenge describes C/C++/Python/Matlab/ROS interfaces. Does not establish these languages, simulator access or licences for all current Walker S, C or wheeled models.
-
Machinery - European Commission ↗
European Commission · Accessed Jun 20, 2026
Official EU source. Machinery placed on the EU market before 20 January 2027 must comply with Machinery Directive 2006/42/EC.
-
Regulation 2023/1230/EU - machinery ↗
EU-OSHA · Accessed Jun 20, 2026
Official EU agency source describing health and safety requirements for machinery placed on the European market.
-
UBTECH Walker application scenarios ↗
UBTECH Robotics · Accessed Jun 20, 2026
Official page describing SDK, application scenarios, industrial manufacturing, warehousing/logistics and research use.
-
UBTECH Walker S and Walker S Lite official product page ↗
UBTECH Robotics · Accessed Nov 1, 2026
Separate labelled graphics inspected: Walker S 170 cm/65 kg/41 DOF/2.5 h; S Lite 130 cm/63 kg/41 DOF/2 h. Family software statements do not establish identical industrial software licences.
-
UBTECH 2026 interim report ↗
UBTECH Robotics · Published Sep 24, 2026 · Accessed Nov 1, 2026
HKEX filing: legal identity, public company financing and new products. Pages 35–36 report net placing proceeds; pages 7 and 15 distinguish group revenue and product development. Revenue is not robot shipment count.