Industrial Applications
G1 is a wheeled mobile manipulator with a 1730 mm maximum height, 92.5 kg body mass and 5 kg-per-wrist rating. The current eight-hour figure is a laboratory test at 60% average speed. Retail operation and software workflow entitlements should be scoped separately.
This editorial assessment concerns industrial buyer readiness. It is not an independent performance test.
| EU regulatory fit | Unknown |
|---|---|
| Cybersecurity fit | Unknown |
| Serviceability fit | Unknown |
| Supply chain fit | Unknown |
Manipulation and Perception
5 kg per arm and 10 kg total at wrist centre.21 DOF excludes chassis and tools:2 neck, 14 arms, 3 waist, 2 leg/lift.710 mm shoulder-to-wrist; wrist workspace 0–2100 mm vertical/1900 mm horizontal; lift range 650 mm. Gripper, suction and dexterous tools differ.
Head stereo, torso 4 RGB cameras, 2 wrist depth cameras and 2 six-axis wrist force sensors; 3 Dlidar, 8 ultrasonic sensors, IMUs. Product says 1 torso IMU while manual says 2; confirm hardware. AGX Orin 64 GB 275 TOPS; dual 4-mic arrays, 5.5 in screen.
SDK and Integration
Python/C++ SDK with exact model/firmware/ABI matching; business modules need separate licensing.
| API type | Galbot SDK1.10.0 control,perception,planning and navigation APIs |
|---|---|
| Languages | Python, C++ |
| ROS support | Official G1 description is a ROS2 package; production SDK distribution/ROS integration must be confirmed separately. |
| Simulation | G1 URDF/MJCF/USD descriptions; model assets alone do not establish simulator/controller compatibility. |
| Offline operation | On-robot execution and local SDK packages exist; proprietary model/cloud/business-service dependency scope requires confirmation. |
| Teleoperation | Remote controller and optional main/sub-arm accessory; capabilities depend on hardware/licence. |
| Software updates | SDK release must match robot environment;1.10.0 targets1.18. Orin/Thor and target ABI packages differ. |
| Documentation | Open documentation |
| Code examples | Open repository |
| Integration constraints | Commercial SPS sorting/tote modules require sales unlocking. Change factory credentials and match hardware,robot environment and package ABI. |
Safety Notes
G1 manual:indoor 0–40°C, avoid wet/uneven ground, keep personnel at least 1.5 m away; no operation with unstable Wi-Fi or electromagnetic interference. Current product claimsIP 54 without inspected test report; not a collaborative-safety certificate.
Compliance and Certificates
| Standard | Status | Jurisdiction | Evidence |
|---|---|---|---|
| CE marking | Unknown | European Union | No exact-model declaration,test report or signed certificate inspected. Distributor supplied-DoC promise is not independently verified conformity. |
| ISO 10218-1 | Unknown | International / European deployment relevance | No exact-model declaration,test report or signed certificate inspected. Distributor supplied-DoC promise is not independently verified conformity. |
| ISO 10218-2 | Unknown | International / European deployment relevance | No exact-model declaration,test report or signed certificate inspected. Distributor supplied-DoC promise is not independently verified conformity. |
| ISO/TS 15066 | Unknown | International | No exact-model declaration,test report or signed certificate inspected. Distributor supplied-DoC promise is not independently verified conformity. |
| Radio Equipment Directive | Unknown | European Union | No exact-model declaration,test report or signed certificate inspected. Distributor supplied-DoC promise is not independently verified conformity. |
Commercial Readiness
| Pricing | No current exact-configuration price verified; quotation required. |
|---|---|
| Price range | Quote-based or unverified |
| Lead time | Needs verification |
| Availability regions | China,subject to quotation, Europe:distributor-stated G1/S1/ET1 range; exact variant unverified |
| Spare parts | European batteries/common spares claimed by distributor; Galbot-specific quantities and repair time not independently verified. |
| Warranty | G1/S1 manuals state 12 months from sale for normal-use quality defects. User arranges protected return transport; unauthorised modifications/repairs, normal wear, battery ageing and non-original parts can be excluded. Local law/contract may differ; confirm ET1 and Premium terms separately. |
| Configuration and pricing basis | Exact configuration quote required |
| Distributors and service | Robot Distribution states Galbot sales/service in Europe; exact appointment and stock unverified. |
No shipping,stock or landed price inferred from a purchase button or partner announcement.
Specifications
| Height | 1730 mm |
|---|---|
| Weight | 92.50 kg |
| Payload | 5.00 kg |
| Runtime | 480 min |
| Battery and runtime conditions | 48 V 30 Ah; 54.6 V 10 A charger, 3.5 h adapter charging. Eight-hour lab endurance at 60% average speed is not a measured production shift. Charging dock/spare battery optional. |
| Degrees of freedom | 21 |
| Max speed | 1.50 m/s |
| Locomotion | Four-wheel omnidirectional base 600×600 mm, 625 mm projected circle; maximum 1.5 m/s. Source ↗ |
| Wireless connectivity | Wi-Fi 2.4/5 GHz, Bluetooth 5.2; SDK network and credentials need local configuration. Source ↗ |
| Payload | Wrist centre 5 kg per arm, 10 kg total; no extension-dependent curve inspected. Source ↗ |
| Horizontal reach | Wrist workspace horizontal 1900 mm, vertical 0–2100 mm; shoulder-to-wrist 710 mm. Source ↗ |
| DOF scope | 21 body DOF excludes mobile base and tools; 2 neck+14 arms+3 waist+2 leg/lift. Source ↗ |
| Runtime | 8 h laboratory comprehensive test at 60% average speed; workload differs from continuous production. Source ↗ |
| Ingress claim | Product claimsIP 54; no exact test report inspected. Source ↗ |
| Vision sensors | Stereo head camera, four torsoRGB, two wrist depth; exact cameras and calibration require revision confirmation. Source ↗ |
| Force sensing | Two wrist six-axis force sensors; not an inspected safety-rated force-limiting function. Source ↗ |
Sources and Further Reading
-
European Commission machinery legislation overview (context only) ↗
European Commission · Accessed Nov 2, 2026
Current Commission overview opened November 2, 2026: Machinery Directive and Regulation 2023/1230 transition; overview gives January 20, 2027 mandatory application of the Regulation. General context, not a model declaration or legal determination for a specific installation. EUR-Lex pages returned a verification challenge, so this readable primary Commission overview is cited instead.
-
European Commission machinery legislation overview (context only) ↗
European Commission · Accessed Nov 2, 2026
Current Commission overview opened November 2, 2026: Machinery Directive and Regulation 2023/1230 transition; overview gives January 20, 2027 mandatory application of the Regulation. General context, not a model declaration or legal determination for a specific installation. EUR-Lex pages returned a verification challenge, so this readable primary Commission overview is cited instead.
-
G1 quick-start and warranty manual v2.2.4 ↗
Galbot · Accessed Nov 2, 2026
Full manual inspected: mechanical/load/battery table, lab runtime at60% average speed, indoor0–40C, 1.5m personnel separation, maintenance and12month warranty from sale. TorsoIMU count differs from current product page. No certified collaborative envelope or declaration identified.
-
G1 ROS2 description and simulation assets ↗
Galbot · Accessed Nov 2, 2026
Official developer centre identifies this as G1 Description. README:ROS2 description package, URDF, MJCF, USD, optional fixed wheel joints; not evidence the production SDK requires ROS2 or that a model file is a maintained simulator controller.
-
Galbot G1 current specifications ↗
Galbot · Accessed Nov 2, 2026
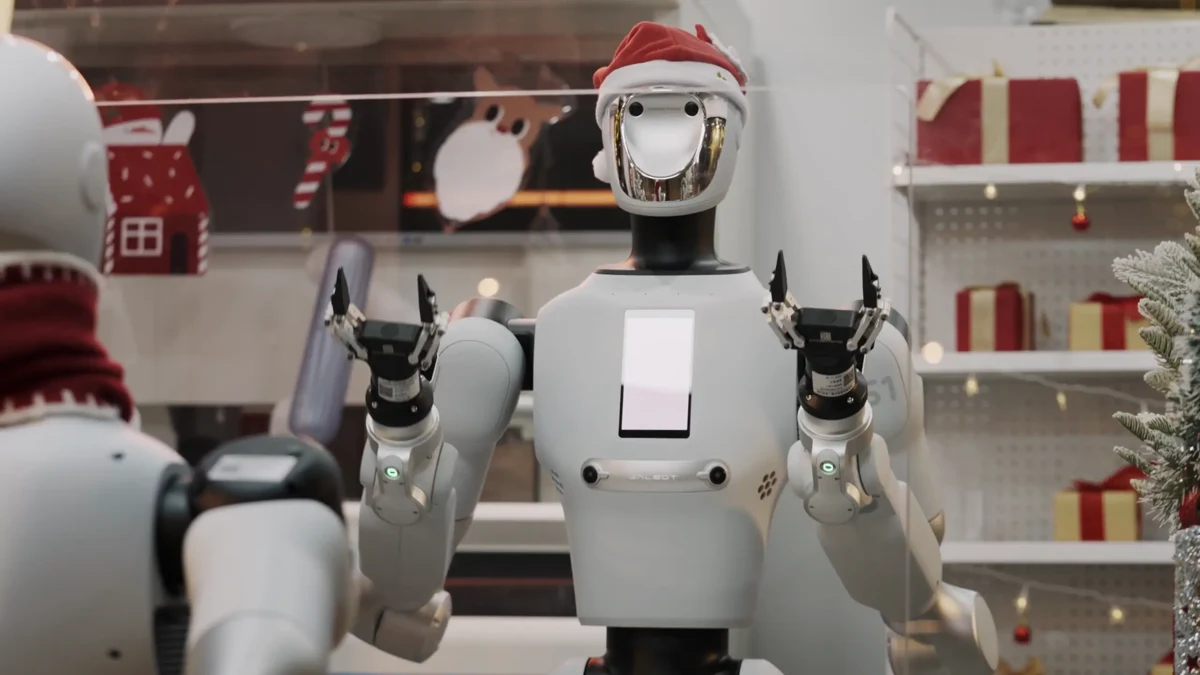
1730mm maximum height, 92.5kg, 5kg per wrist / 10kg total, 21DOF excluding chassis/tools, 48V30Ah, 8h, 1.5m/s, AGX Orin64GB275TOPS. Current specification illustration alt text explicitly says S1 placeholder awaiting G1 image; not used as G1 media. Hero is an identified G1 retail demonstration photograph. Linked official pharmacy demonstration video checked HTTP200 on2026-11-02; source association is manufacturer identification,not independent deployment proof.
-
GalbotSDK repository and compatibility ↗
Galbot · Accessed Nov 2, 2026
README states SDK1.10.0 released22September2026 for robot environment1.18. Repository contains examples, headers and prebuilt C++/Python libraries for target architectures/ABIs. Root Apache2.0 licence does not imply all robot firmware, model weights or commercial business modules are source available.
-
Galbot SDK v1.10.0 documentation ↗
Galbot · Accessed Nov 2, 2026
Current developer centre links this version. Python/C++control, perception, navigation, planning and sample APIs; business sorting/tote modules require commercial unlocking. Exact target model and firmware must match.
-
ISO 10218-2:2025 integration scope (context only) ↗
ISO · Accessed Nov 2, 2026
Current publisher abstract/catalogue opened November 2, 2026. Part 2 covers industrial robot applications and cells, with application exclusions. Full paid standard not acquired. Context only; does not certify this robot or prove that industrial-cell provisions alone cover public-service use and mobile hazards.
-
SDK capabilities and commercially licensed modules ↗
Galbot · Accessed Nov 2, 2026
Inspected control/sensor/planning/navigation layers. SPS sorting and tote-handling business functionality must be enabled through sales. Training and custom integration are offered, without a universal entitlement.
-
SDK deployment requirements ↗
Galbot · Accessed Nov 2, 2026
Installation selector inspected: on-robot, Ubuntu/WSL2/VMware PC and Docker routes. Separate robot and Docker chapters inspected: Orin GCC9.4 and Thor GCC13.3 ARM64 builds; network and robot firmware compatibility checks required.
-
SDK on-robot deployment ↗
Galbot · Accessed Nov 2, 2026
Inspected deployment guide: SSH/SCP, local execution on robot, matching Orin/Thor cross-compile toolchains, prebuilt libraries. Guide publishes factory credentials; change default credentials and segment deployment networks. No credential copied into this dataset.
-
Galbot range and European support offer ↗
Robot Distribution · Published Oct 22, 2026 · Accessed Nov 2, 2026
Distributor states G1/S1/ET1 supply, buy/rent/RaaS, European parts/repair/training and supplied DoC; listings/on-order status and exact configuration need quotation. Manufacturer authorisation, physical stock and signed exact-model declaration not independently inspected.